

常見Bug及解決
攝像頭獲取失敗
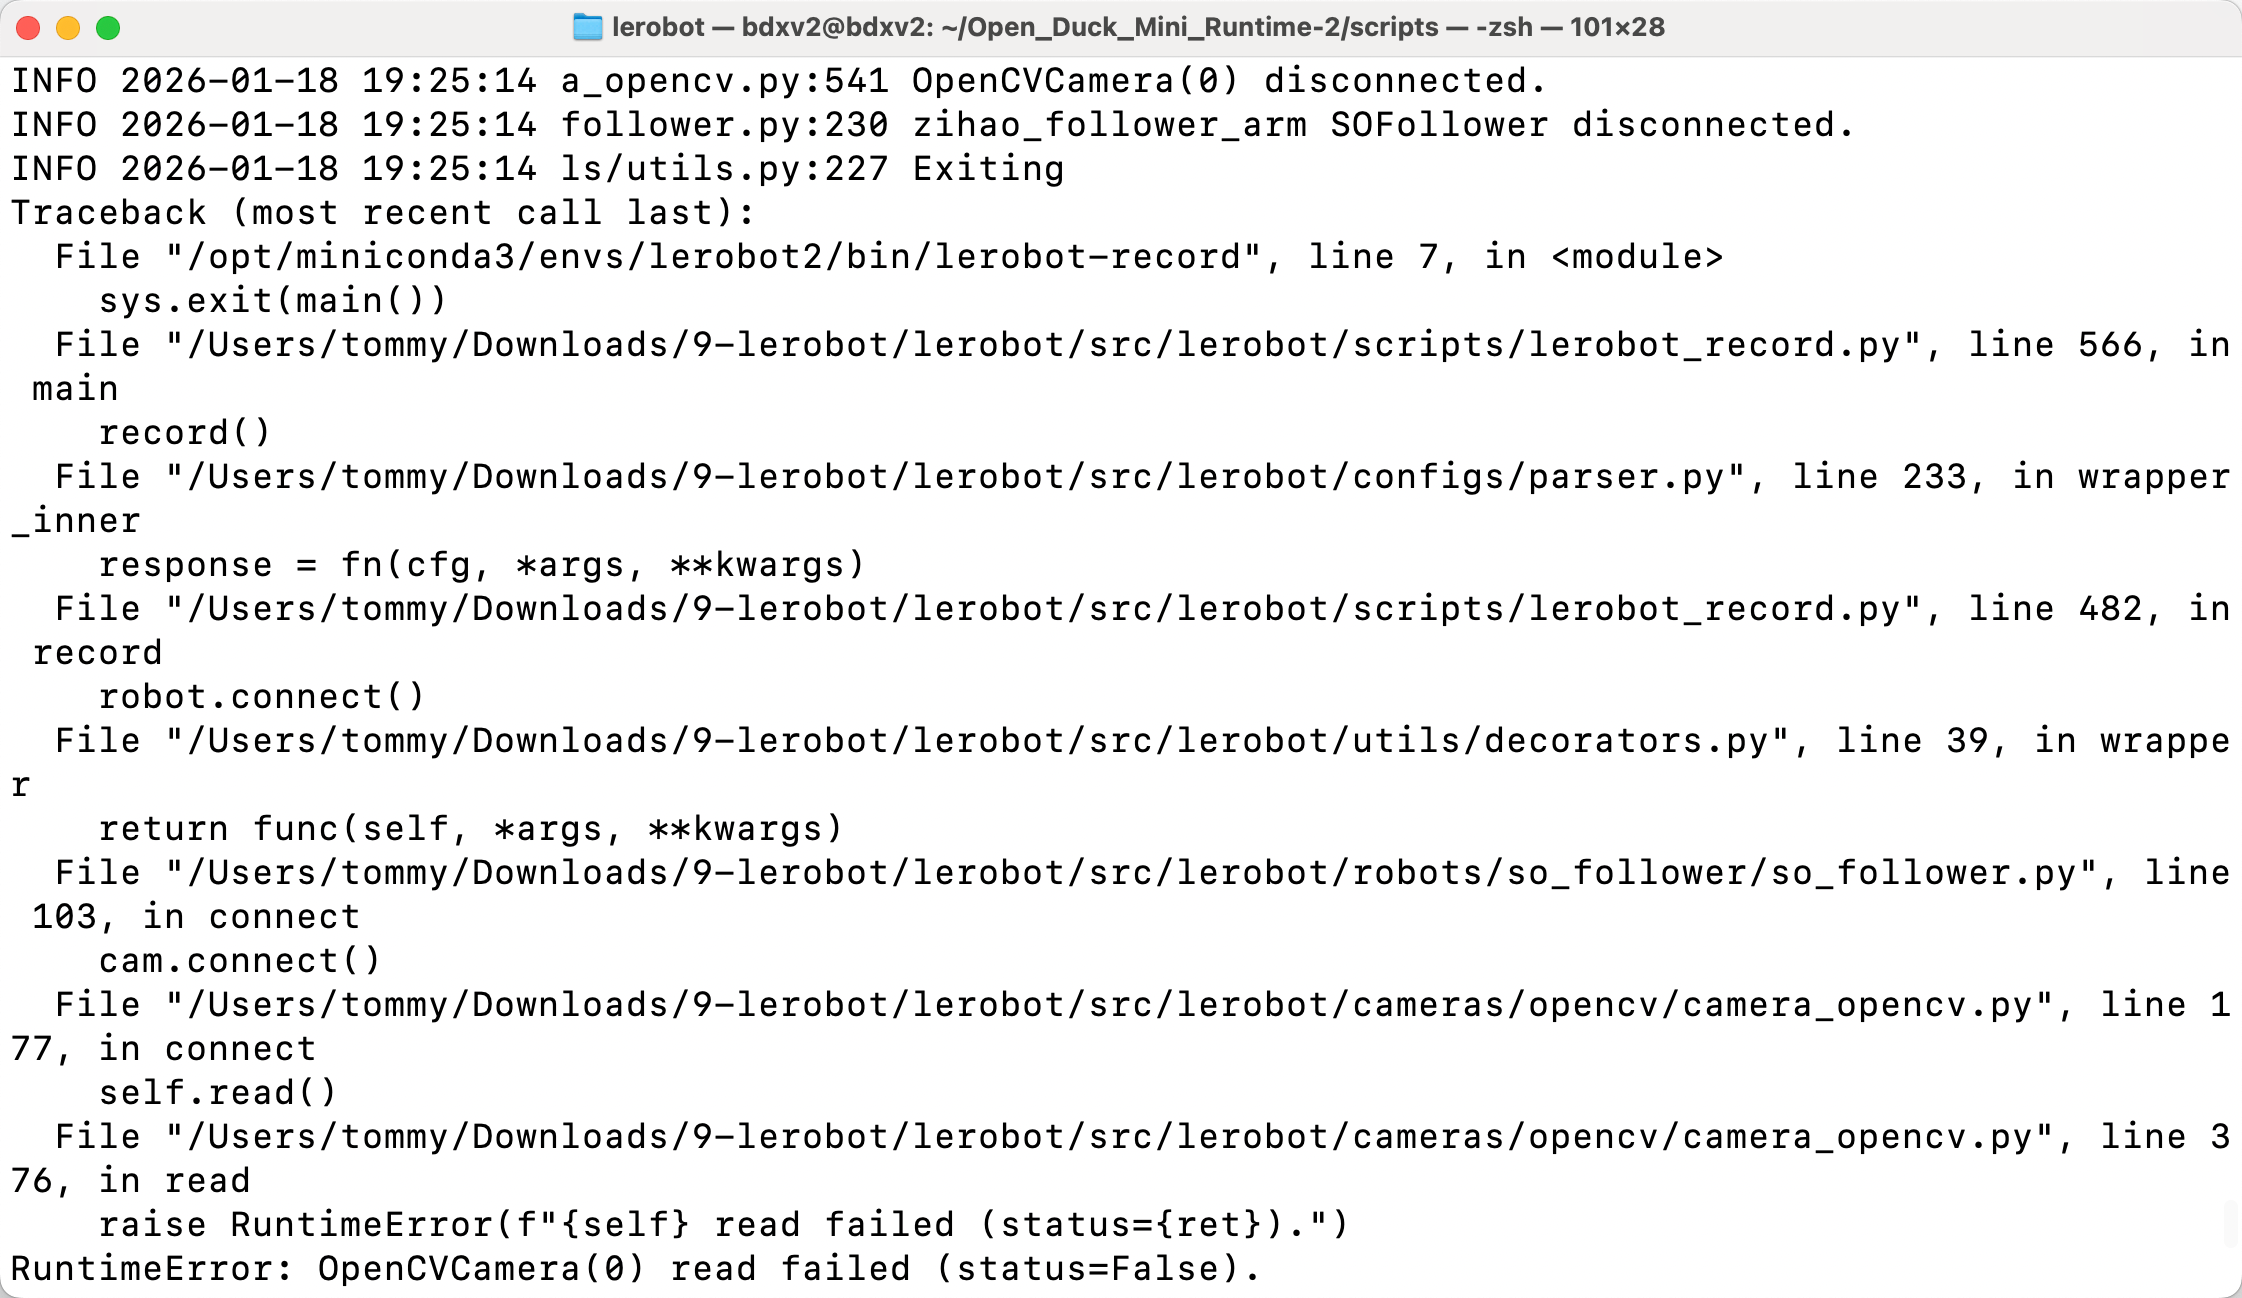
檢查一下腕部攝像頭的接線是否鬆動,特別是靠近攝像頭那端的接線,非常容易接觸不良
攝像頭斷連
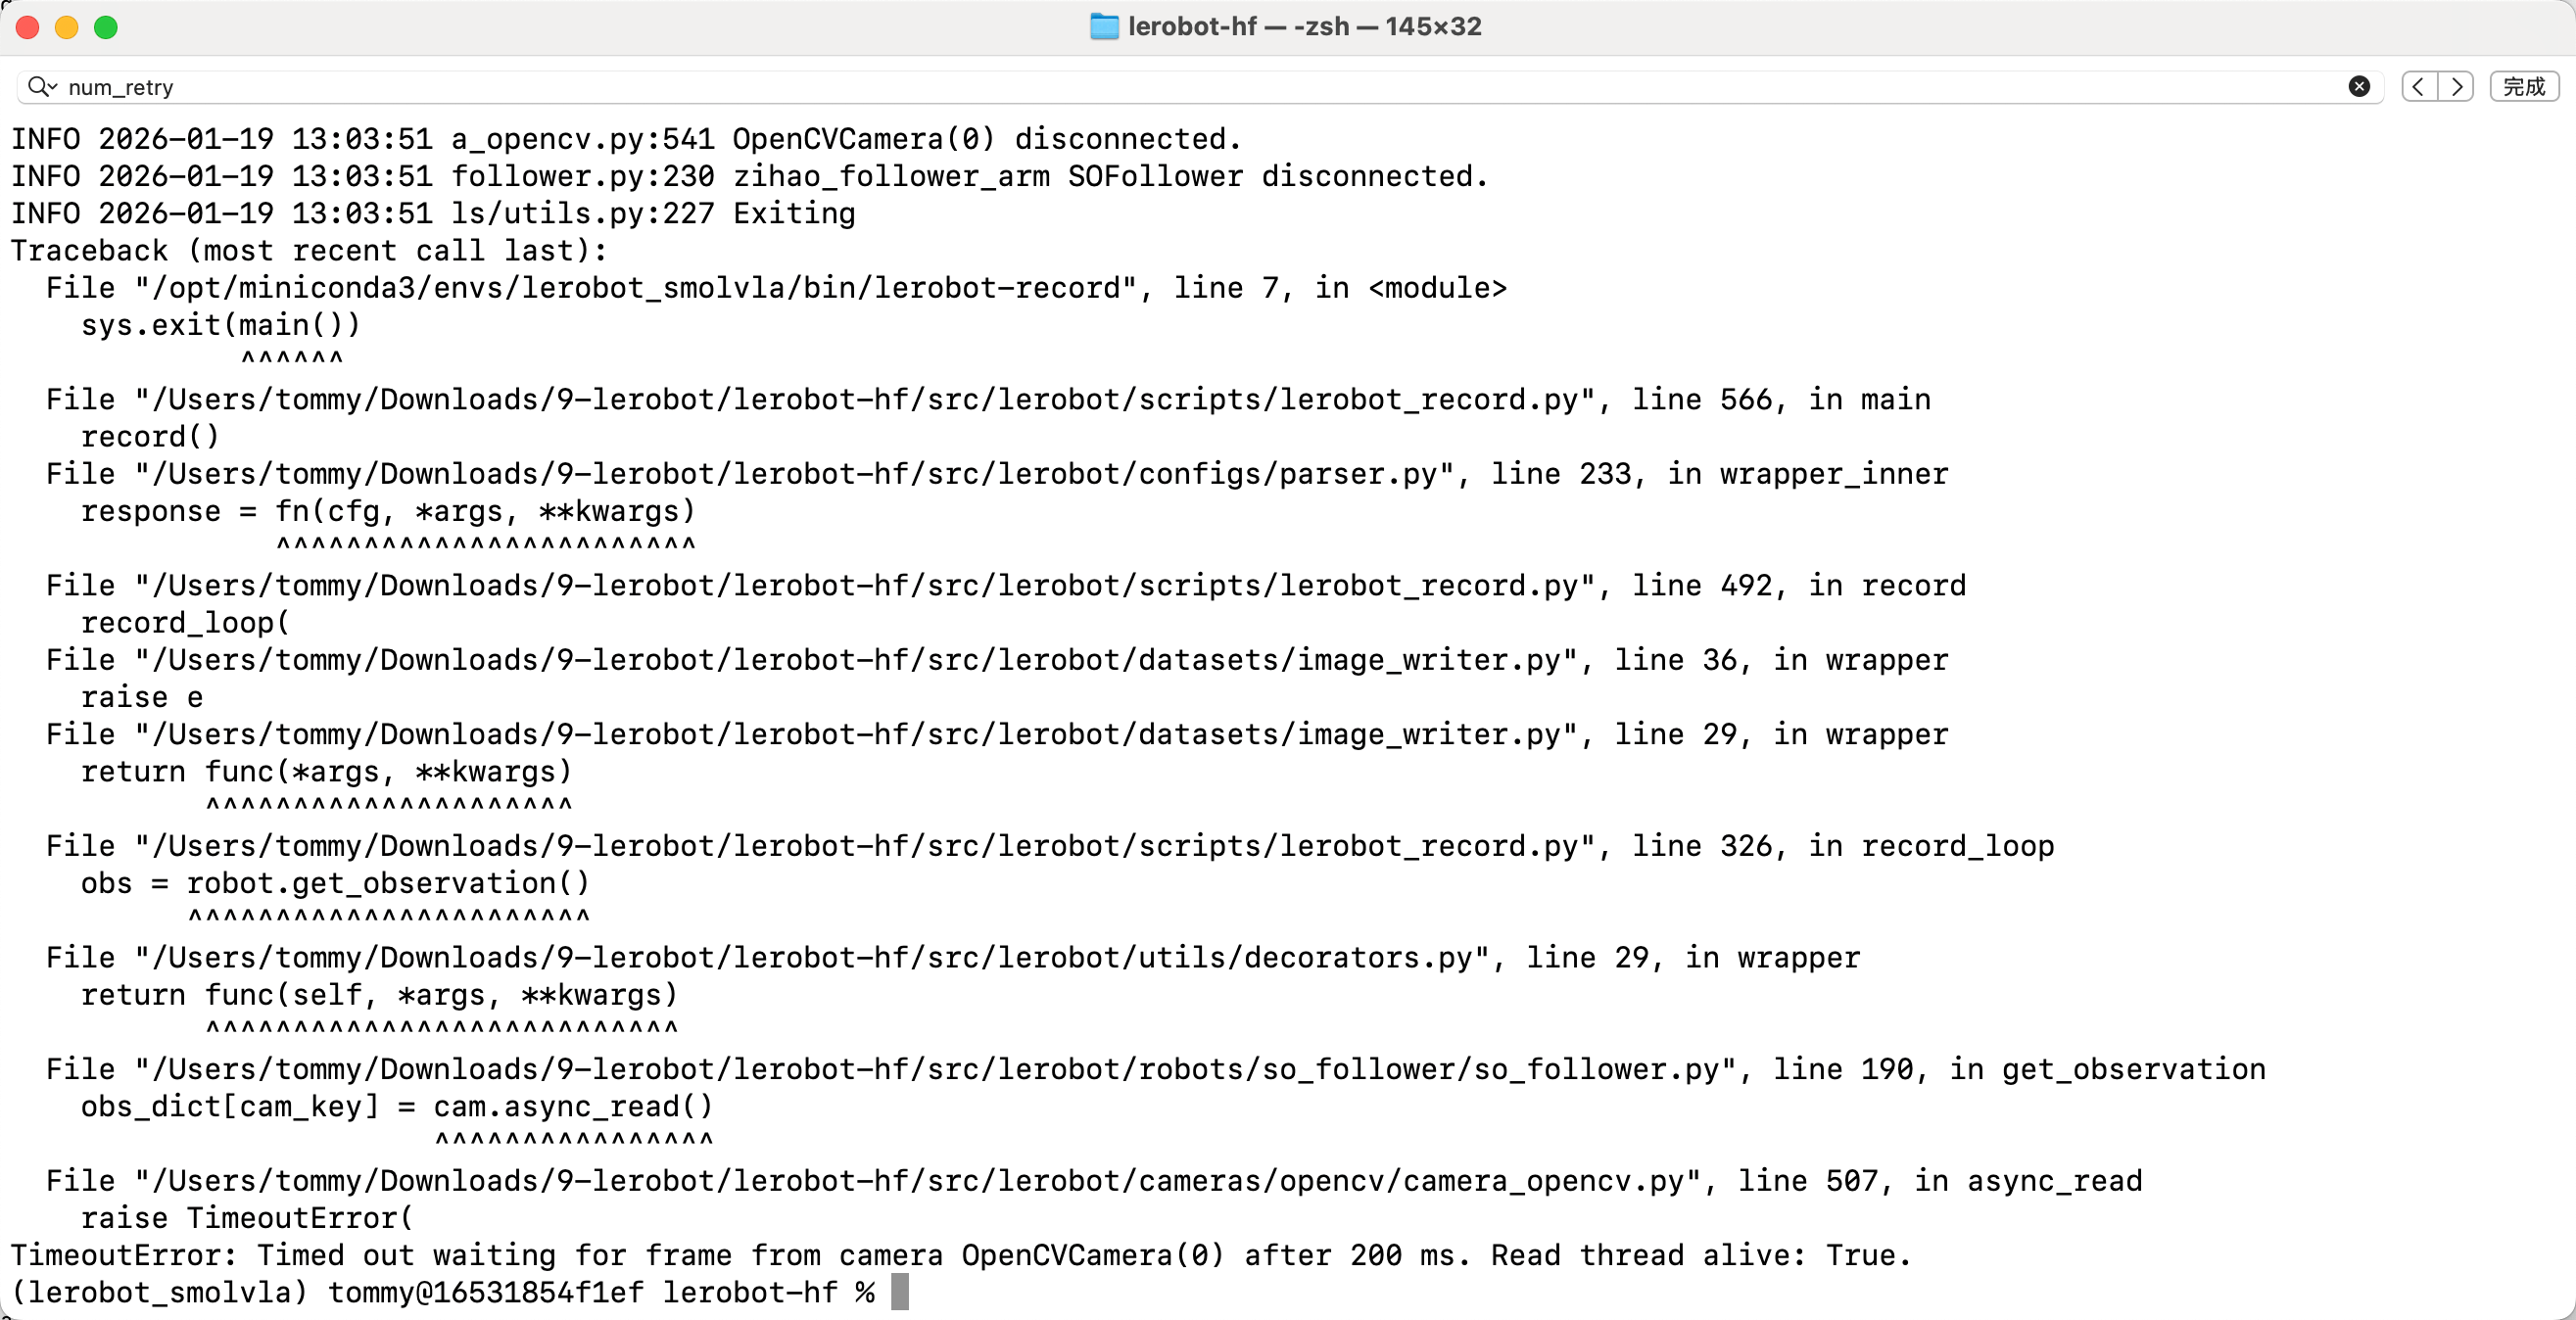
重新啟動一下命令行
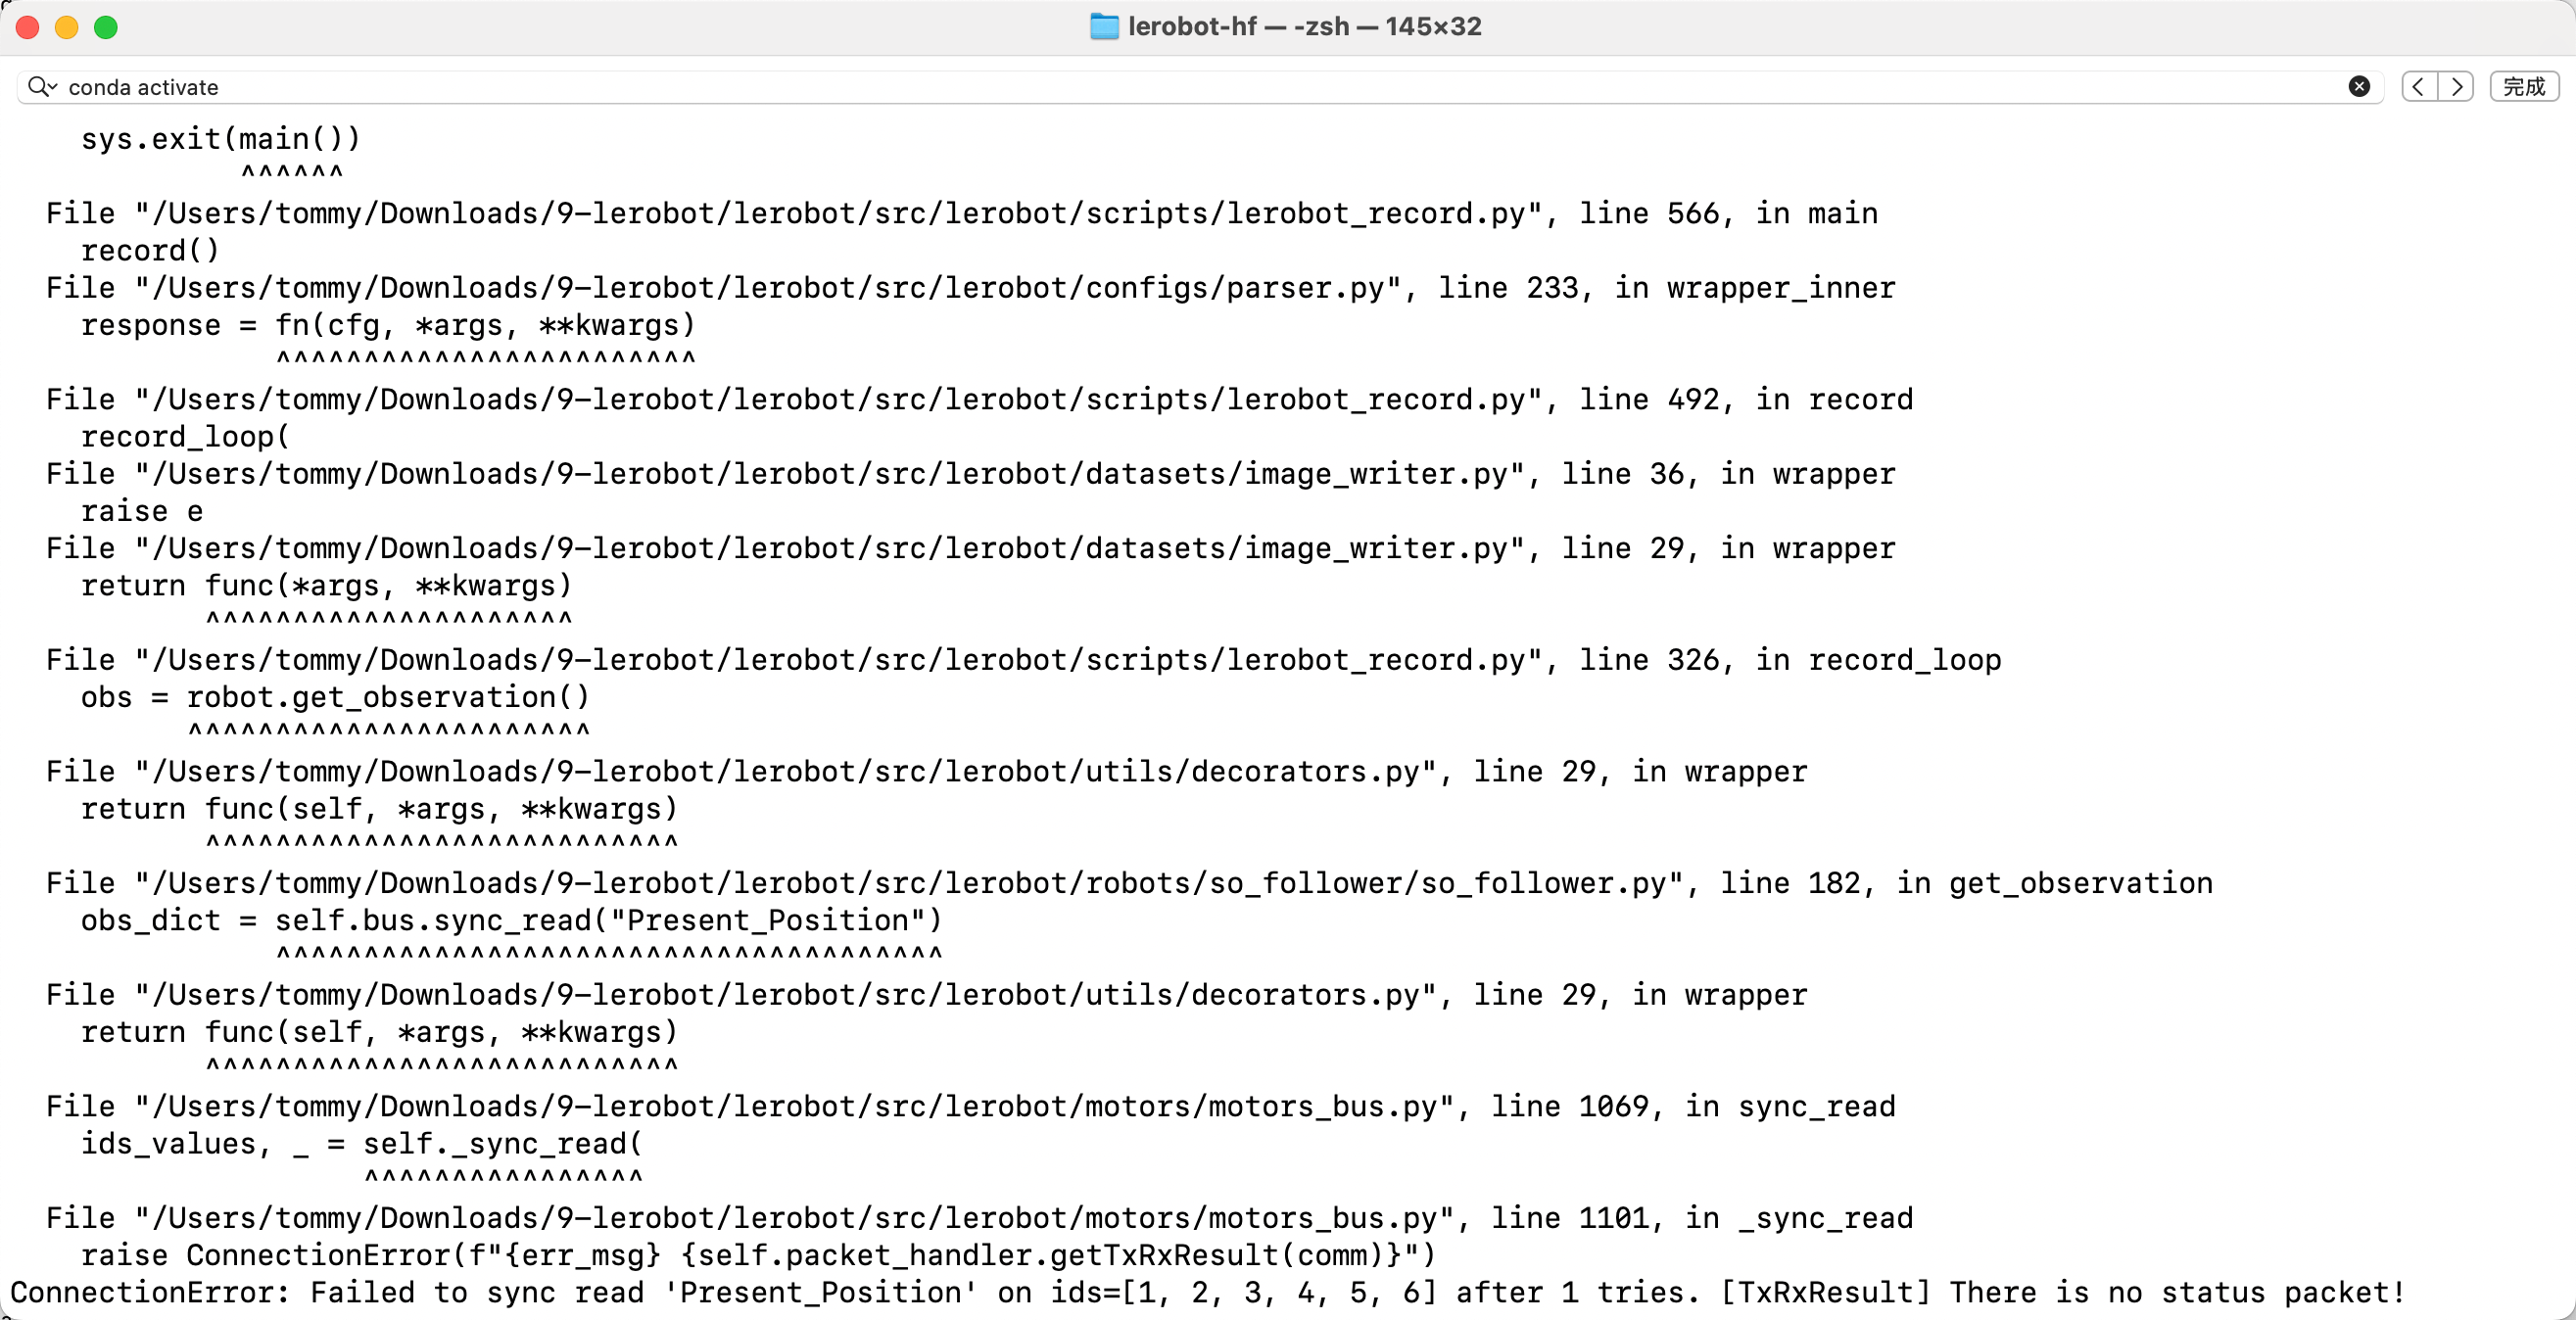
舵機通信問題1
ConnectionError: Failed to sync read 'Present_Position' on ids=[1, 2, 3, 4, 5, 6] after 1 tries. [TxRxResult] There is no status packet!
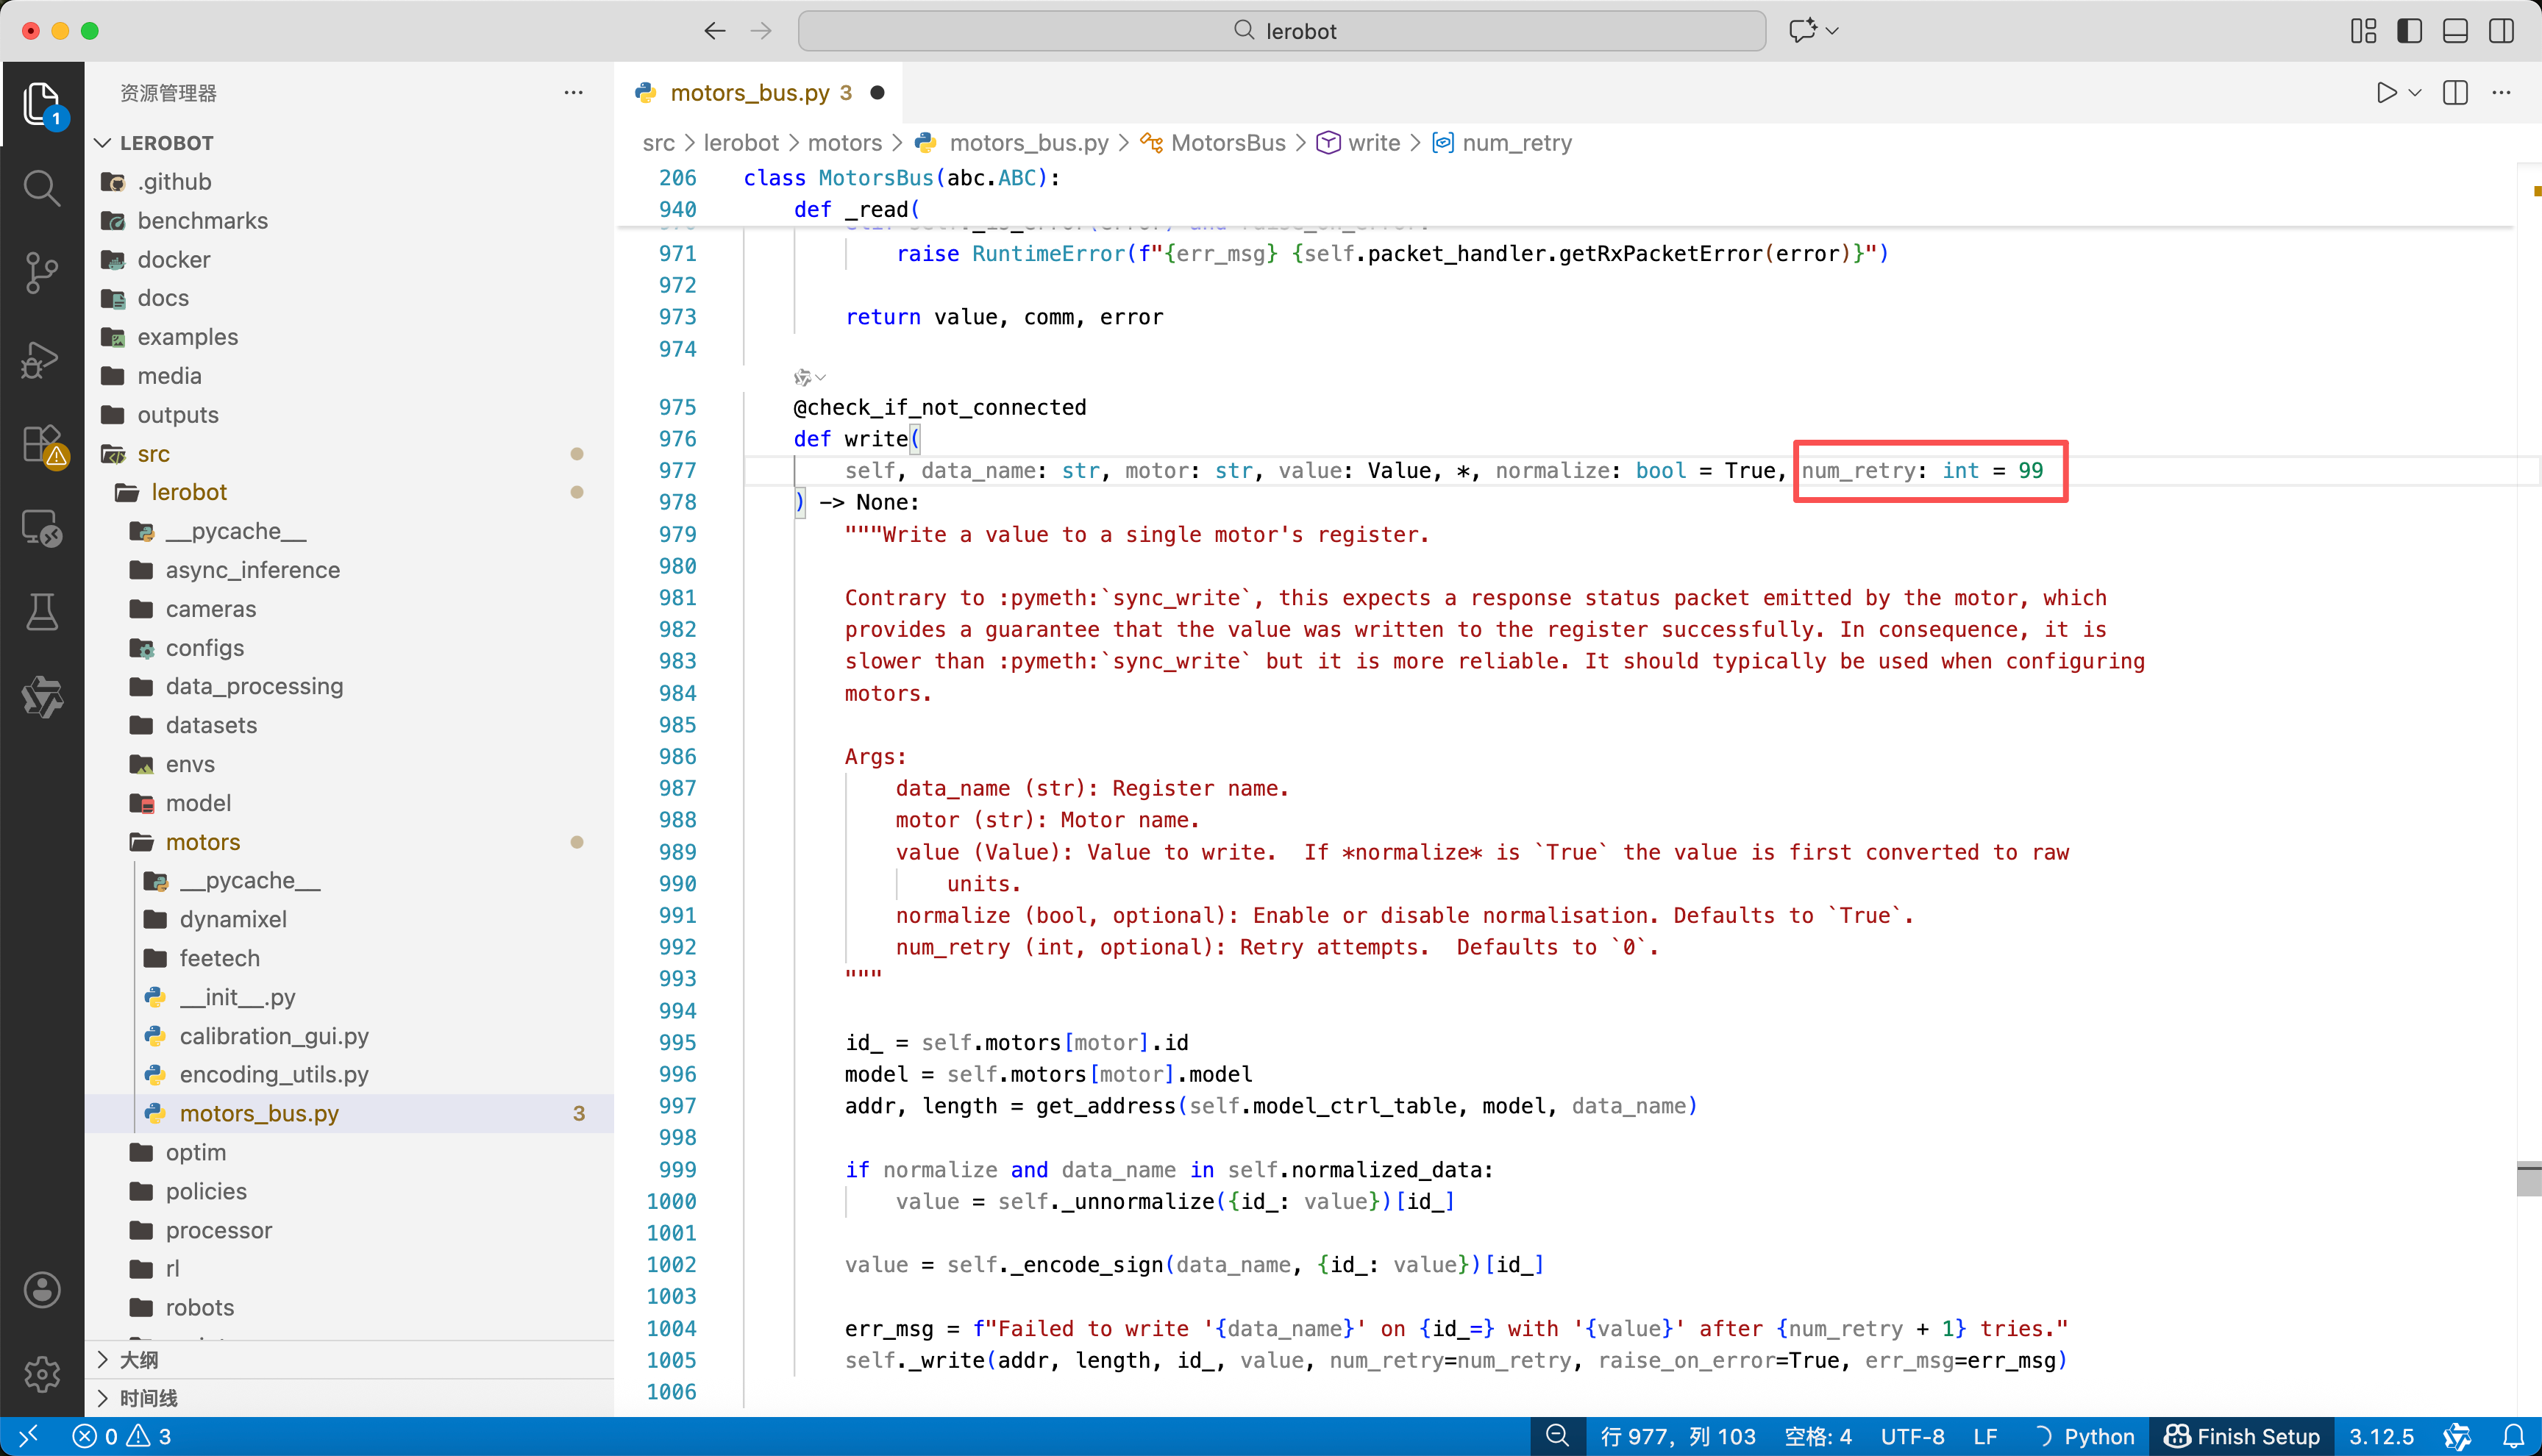
解決方案,把lerobot/src/lerobot/motors/motors_bus.py代碼中所有num_retry都改成99,特別是報錯行對應的
舵機通信問題2
ConnectionError: Failed to write 'Torque_Enable' on id_=1 with '0' after 6 tries. [TxRxResult] There is no status packet!
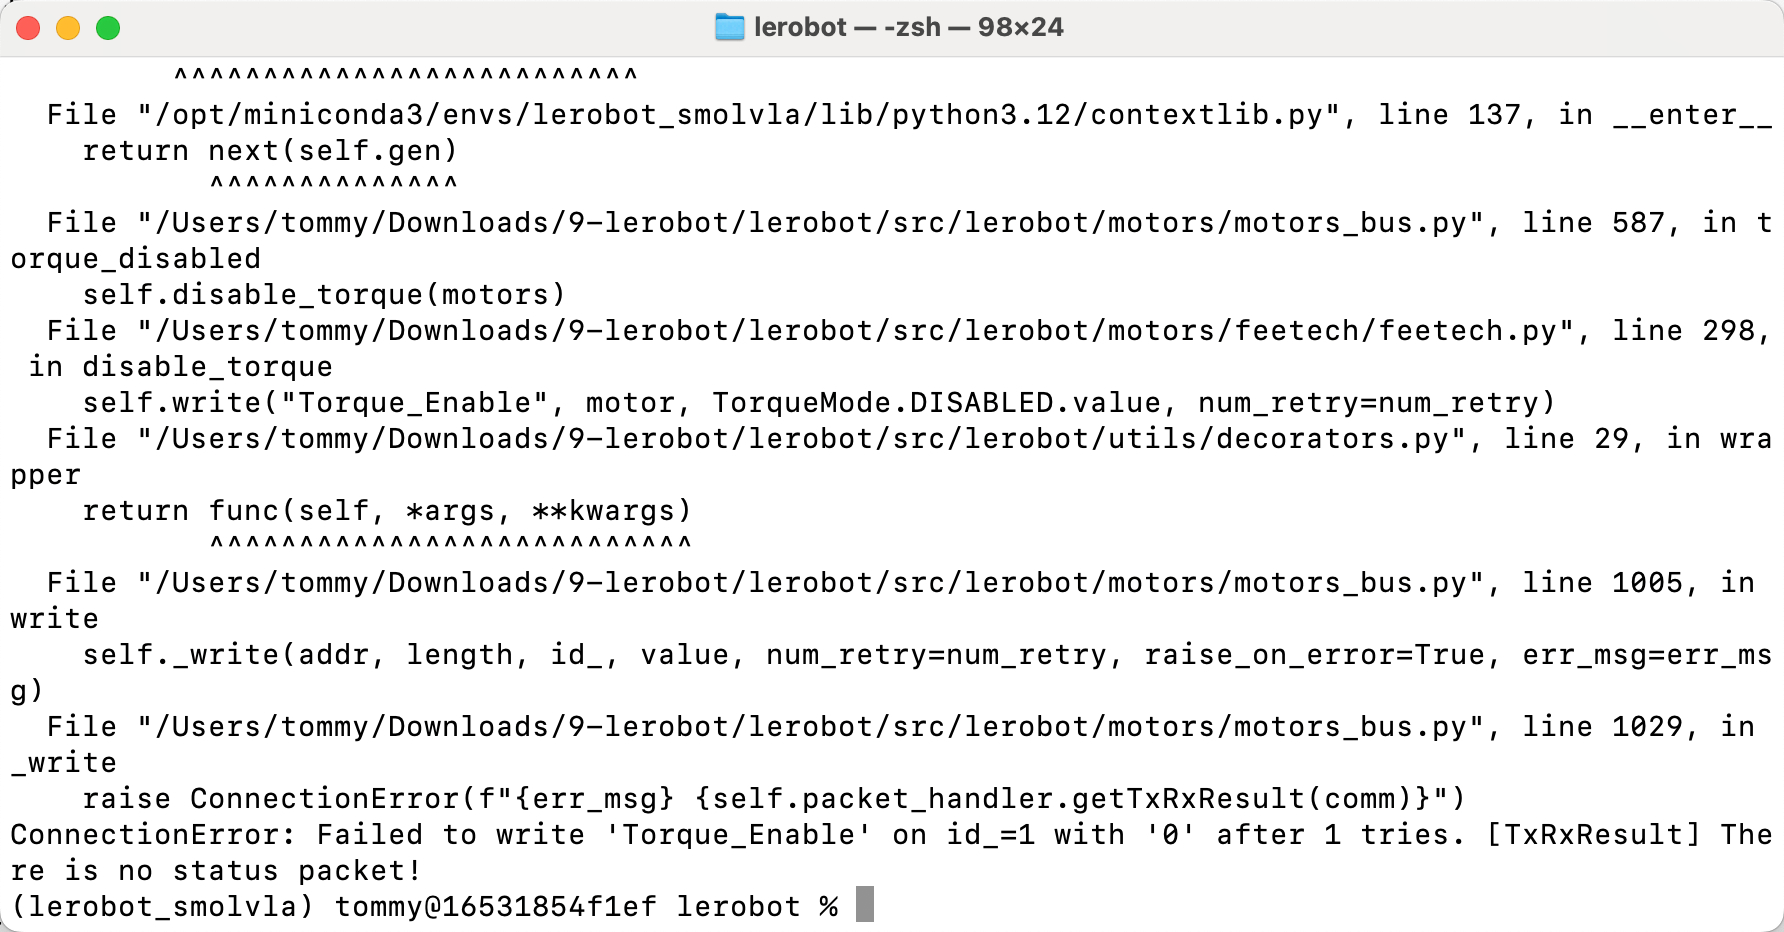
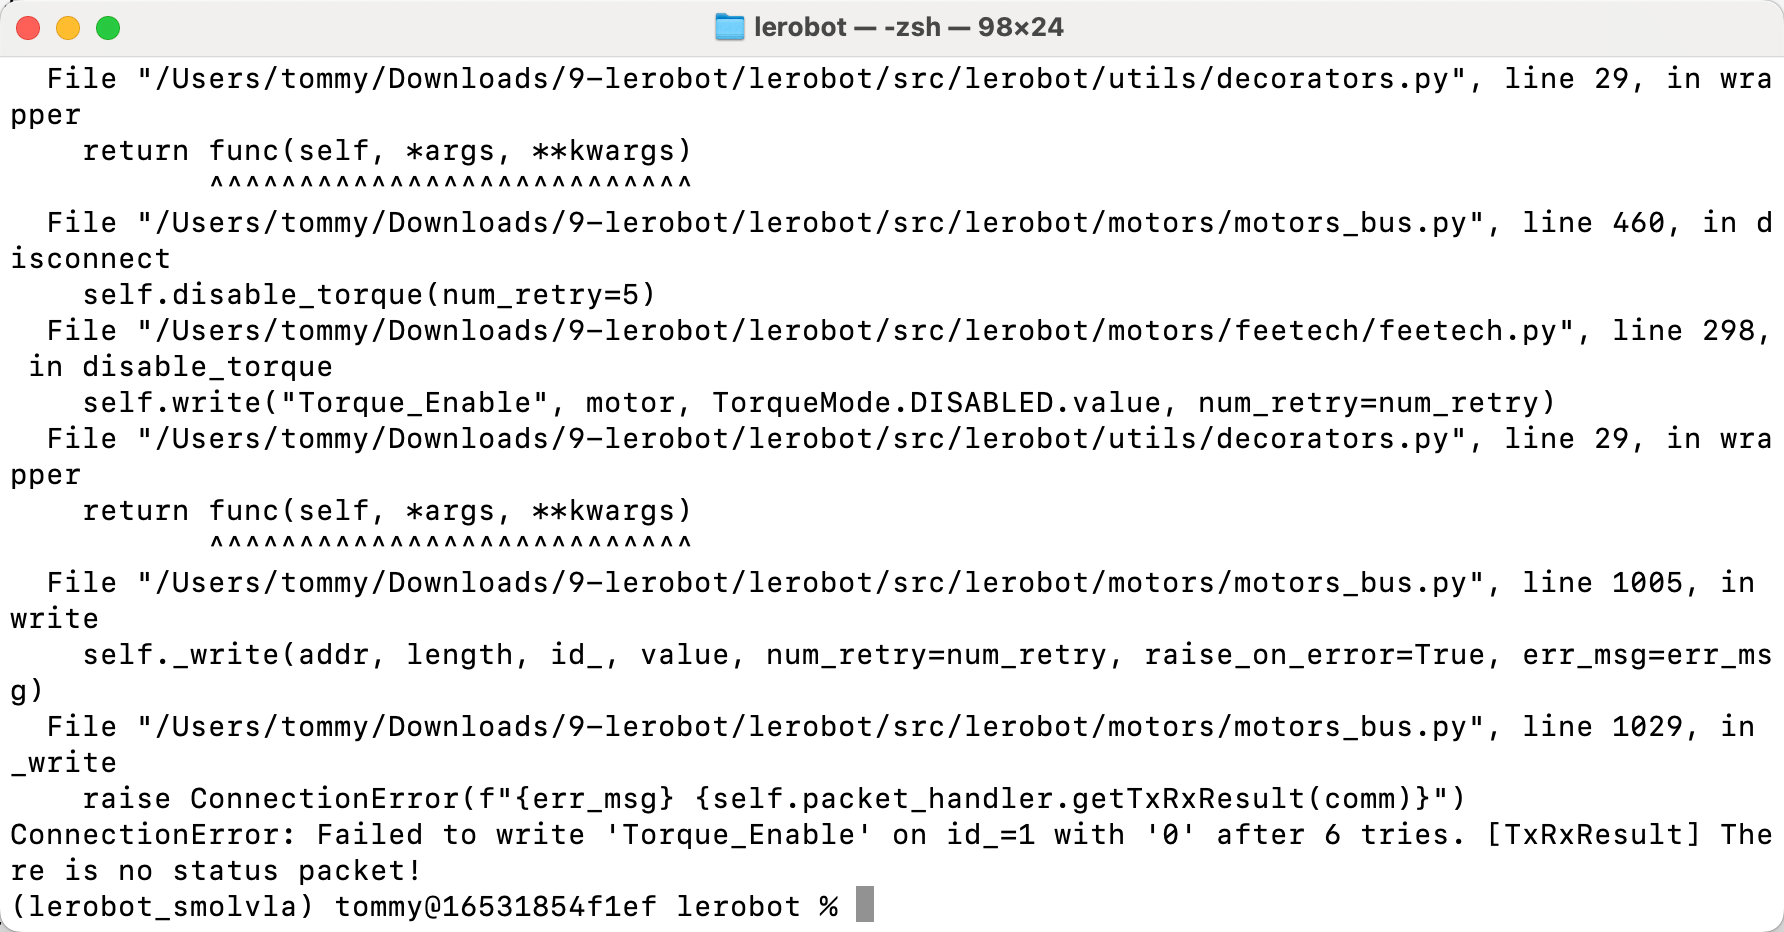
解決方法:重新校準機械臂