

よくあるBugと解決方法
カメラの取得に失敗する
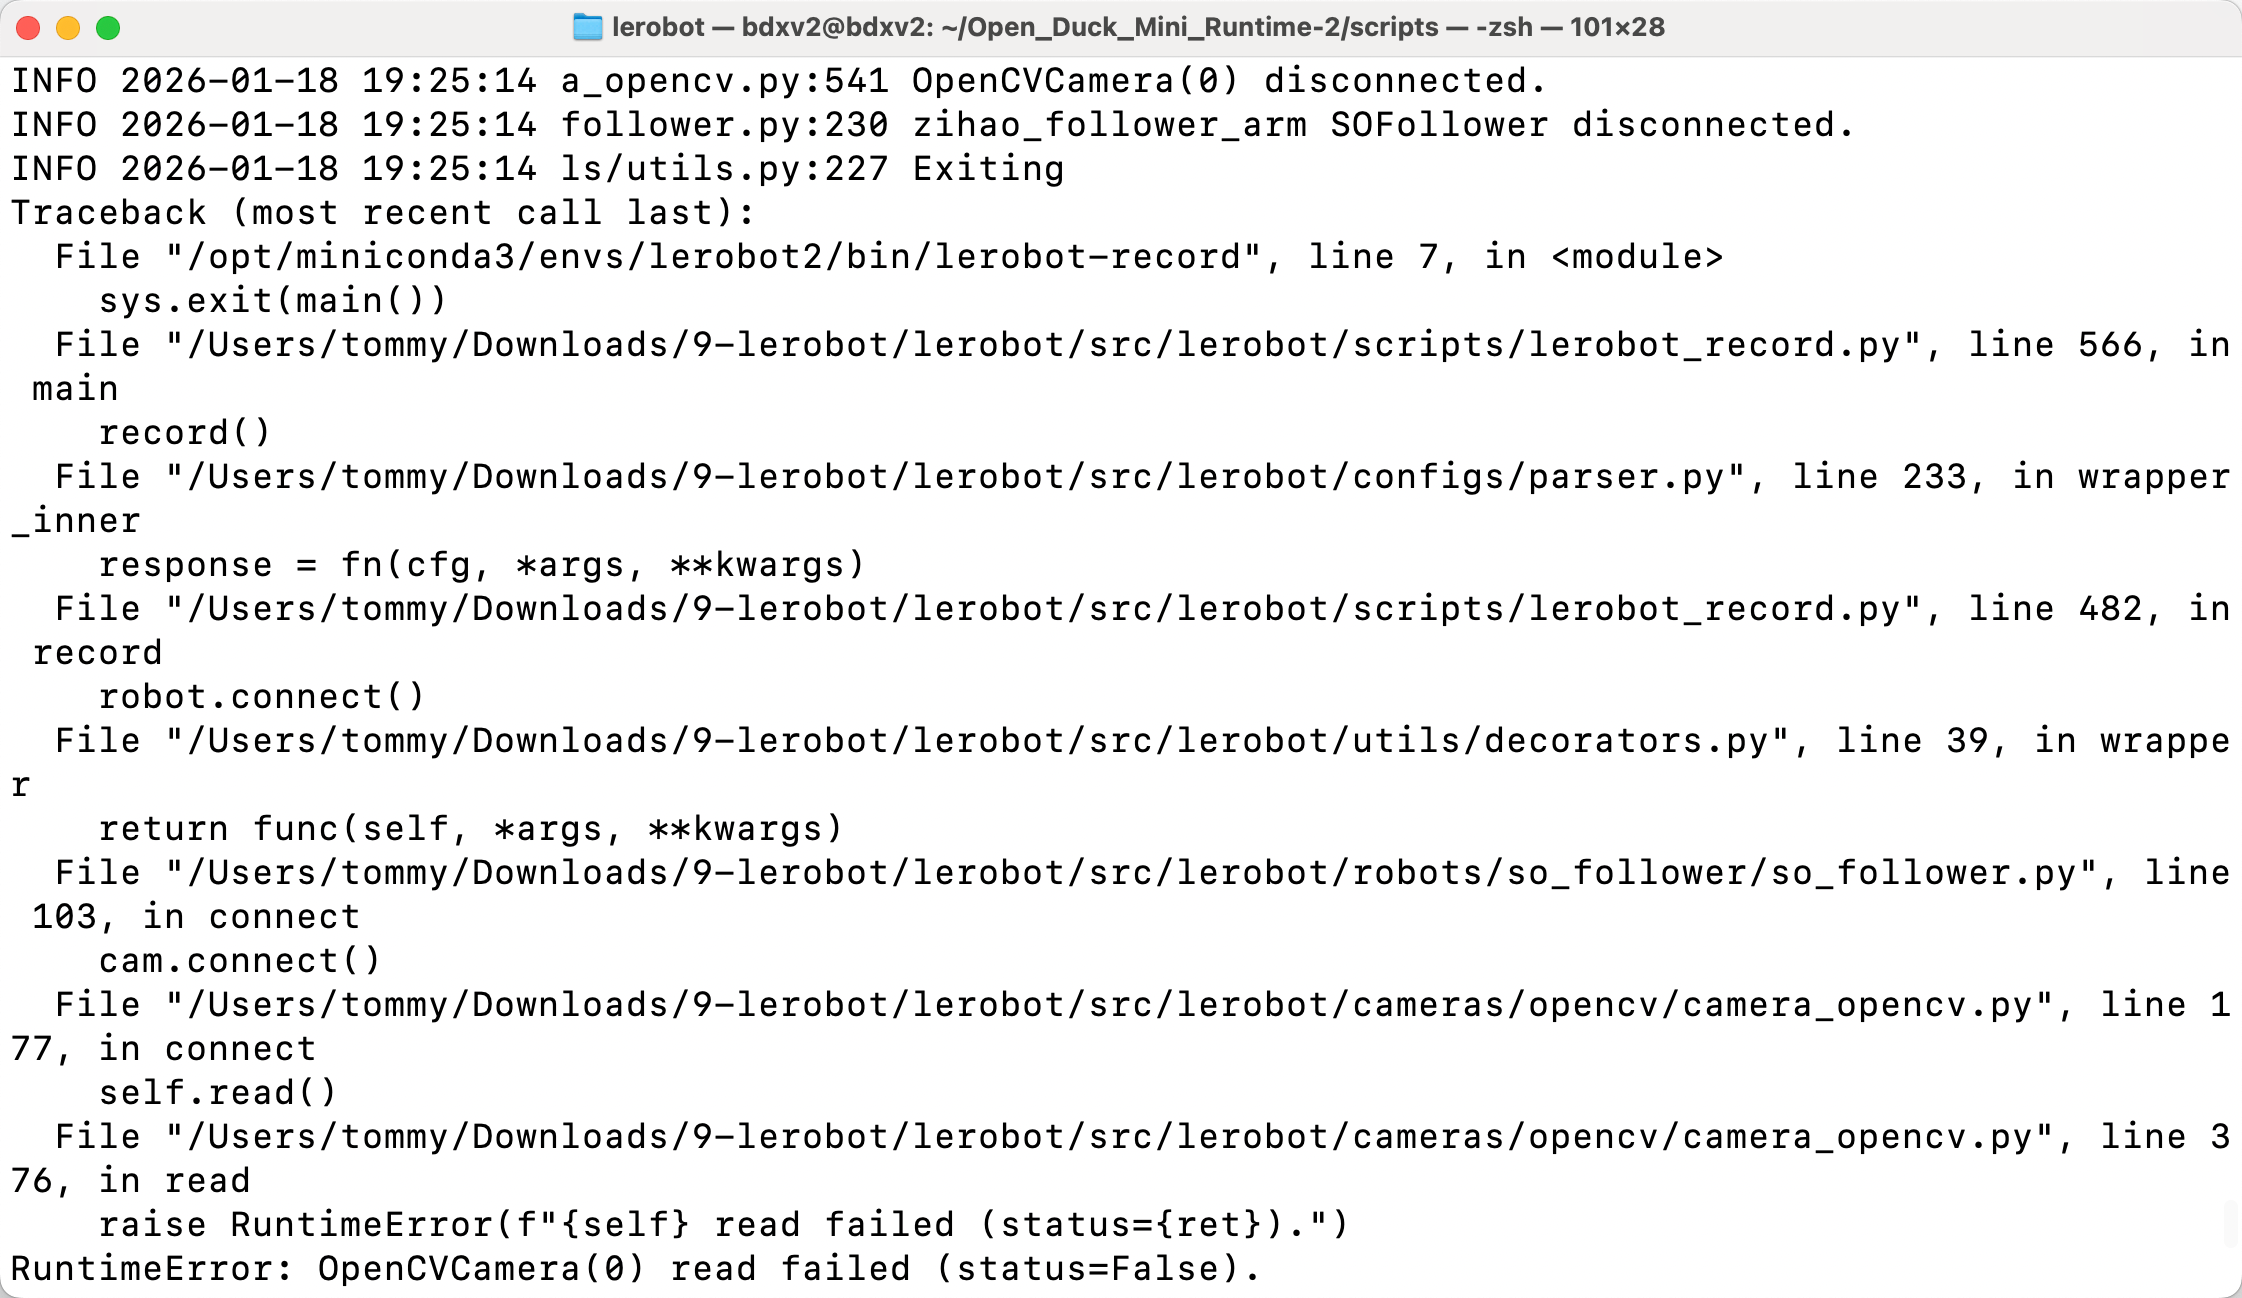
手首カメラの配線が緩んでいないか確認してください。特にカメラに近い側の配線は非常に接触不良を起こしやすいです
カメラが切断される
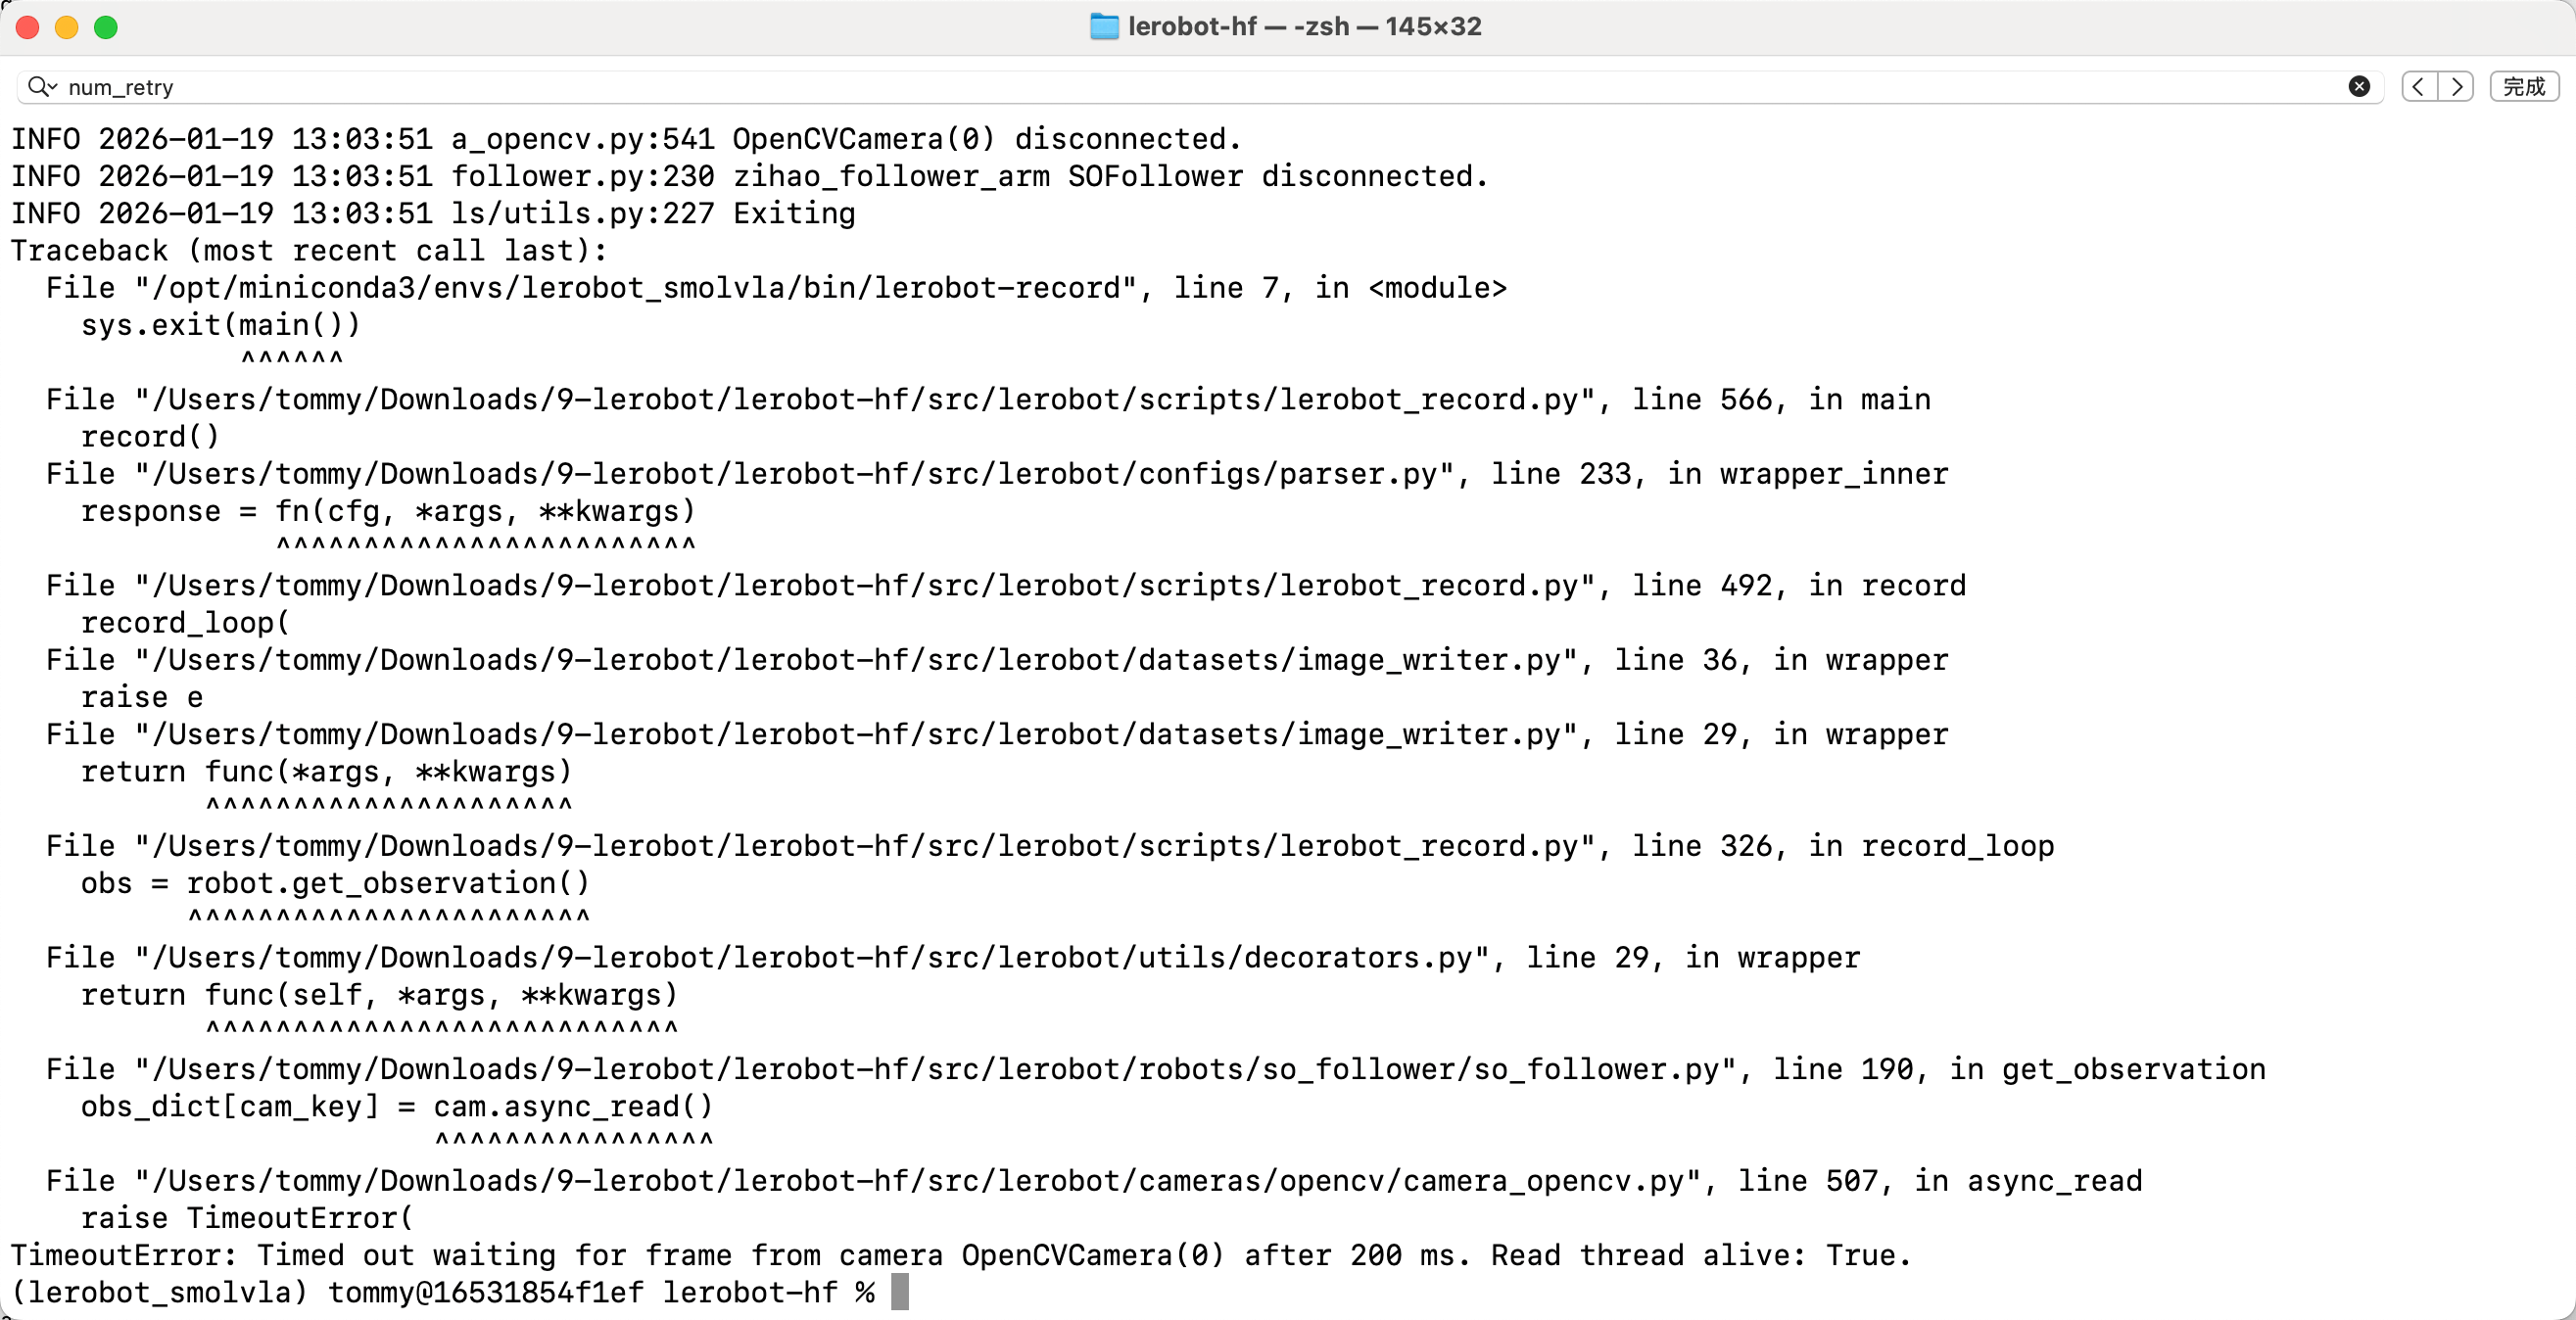
コマンドラインを再起動してください
サーボ通信の問題1
ConnectionError: Failed to sync read 'Present_Position' on ids=[1, 2, 3, 4, 5, 6] after 1 tries. [TxRxResult] There is no status packet!
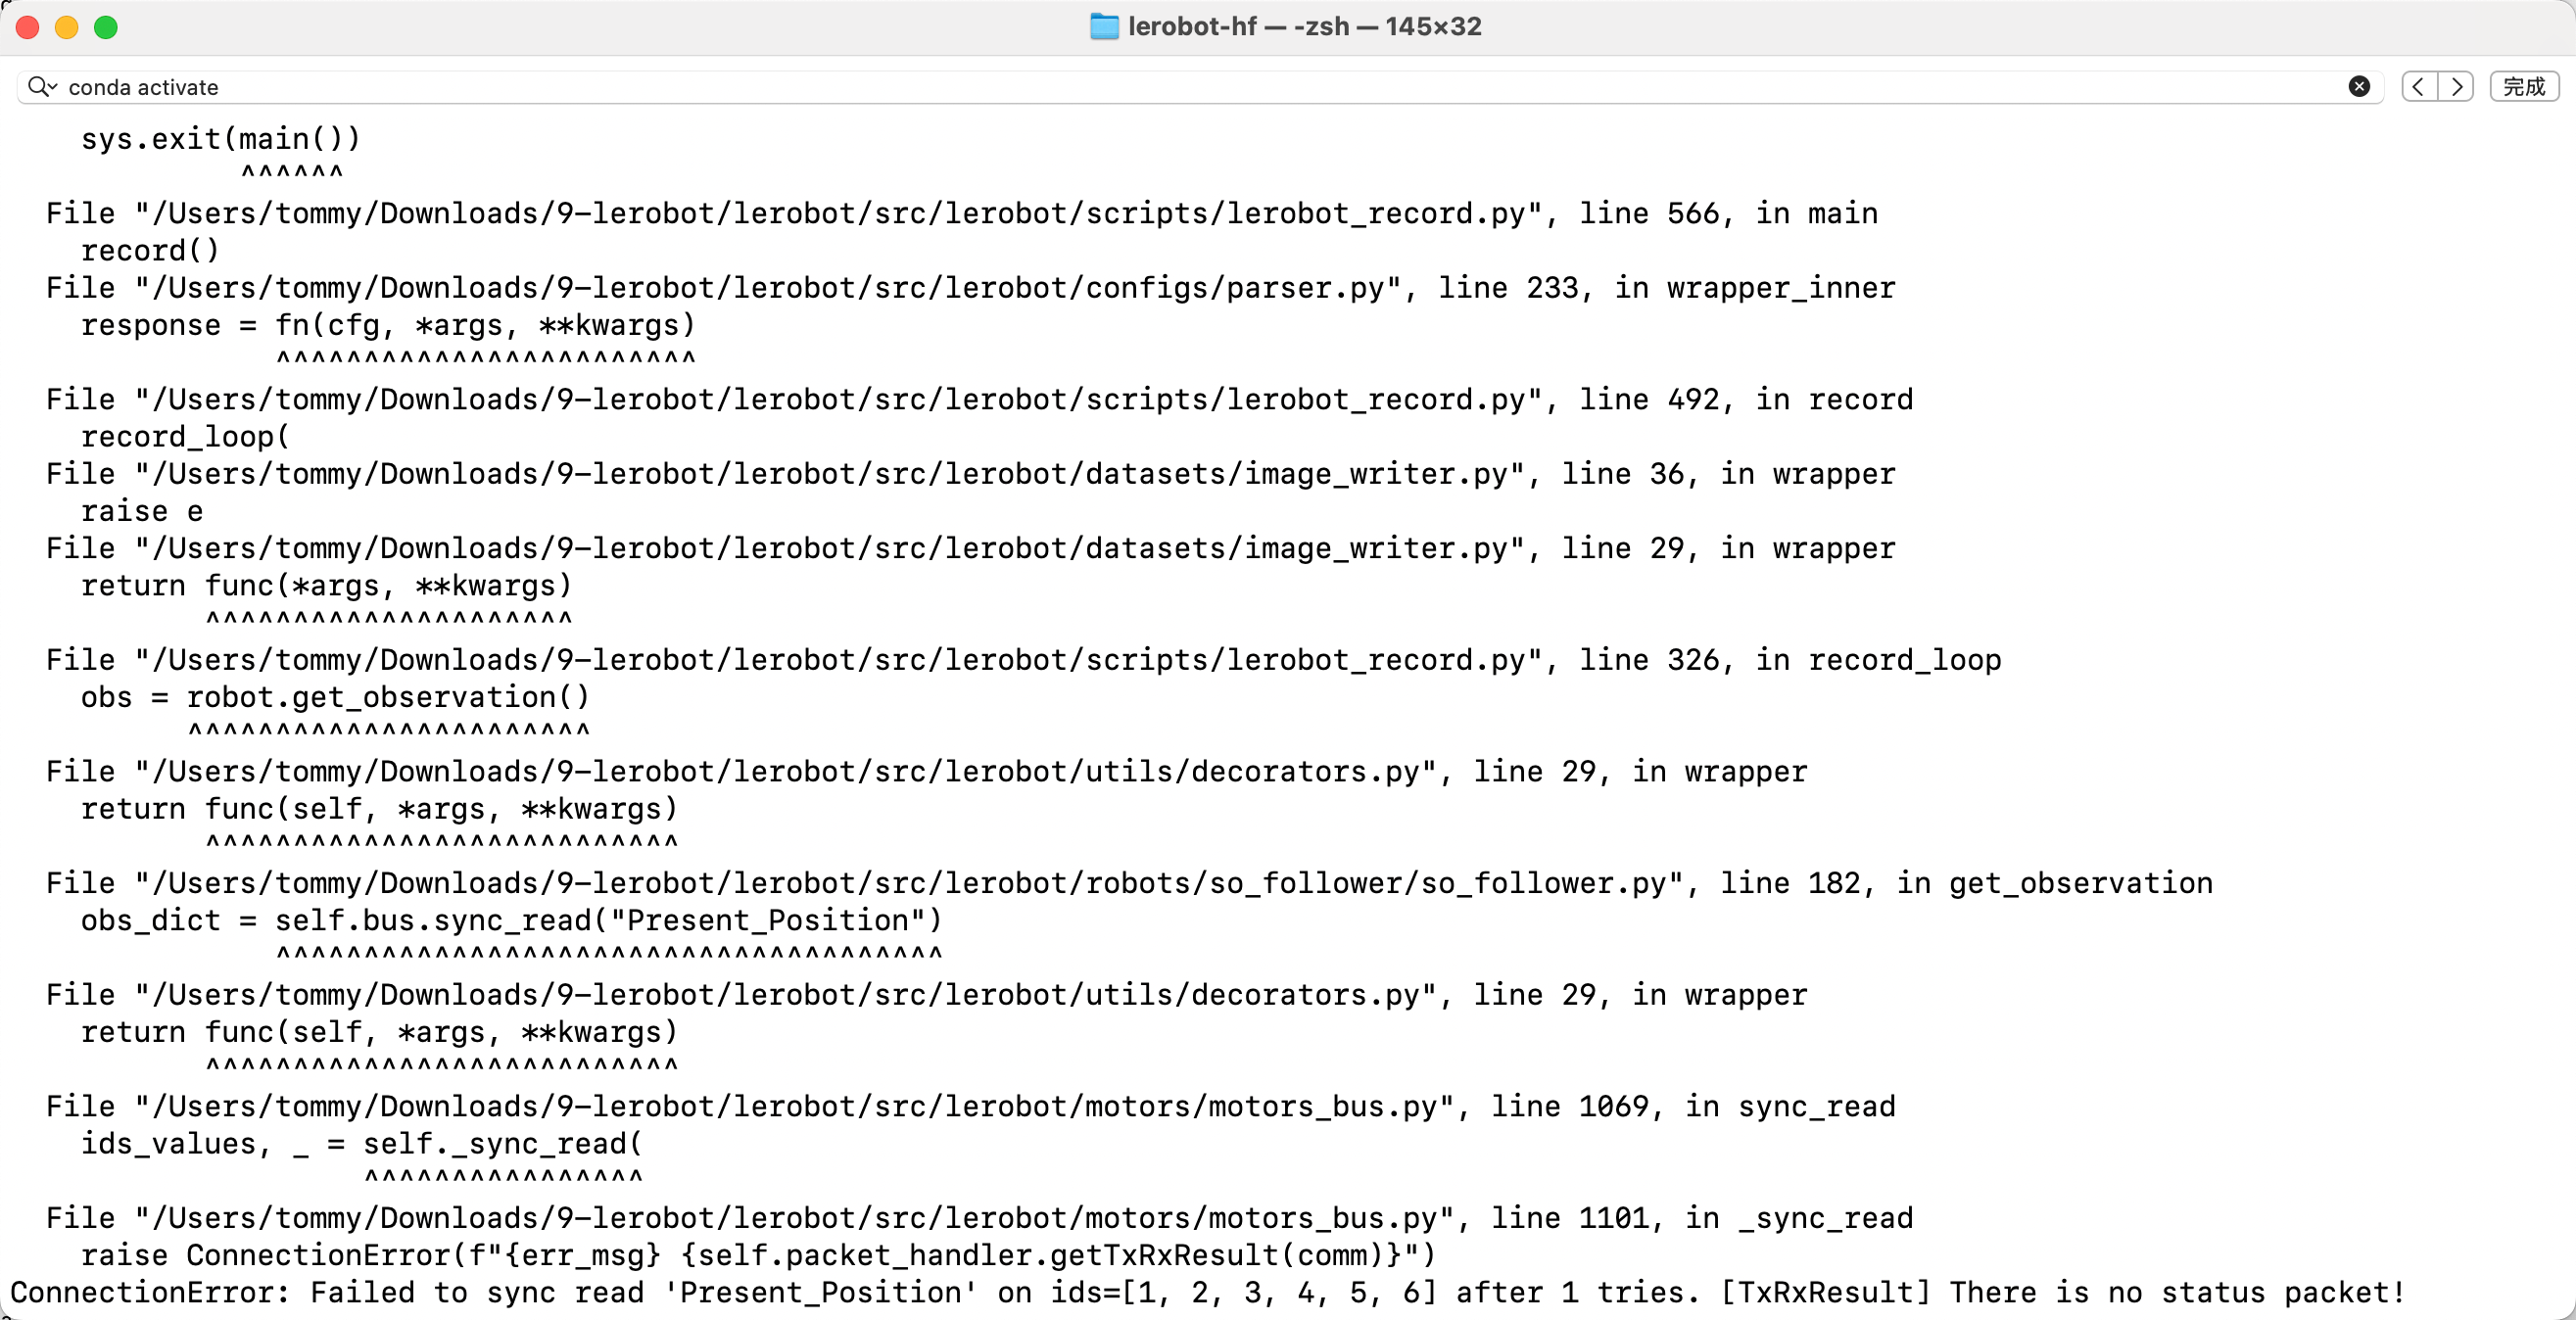
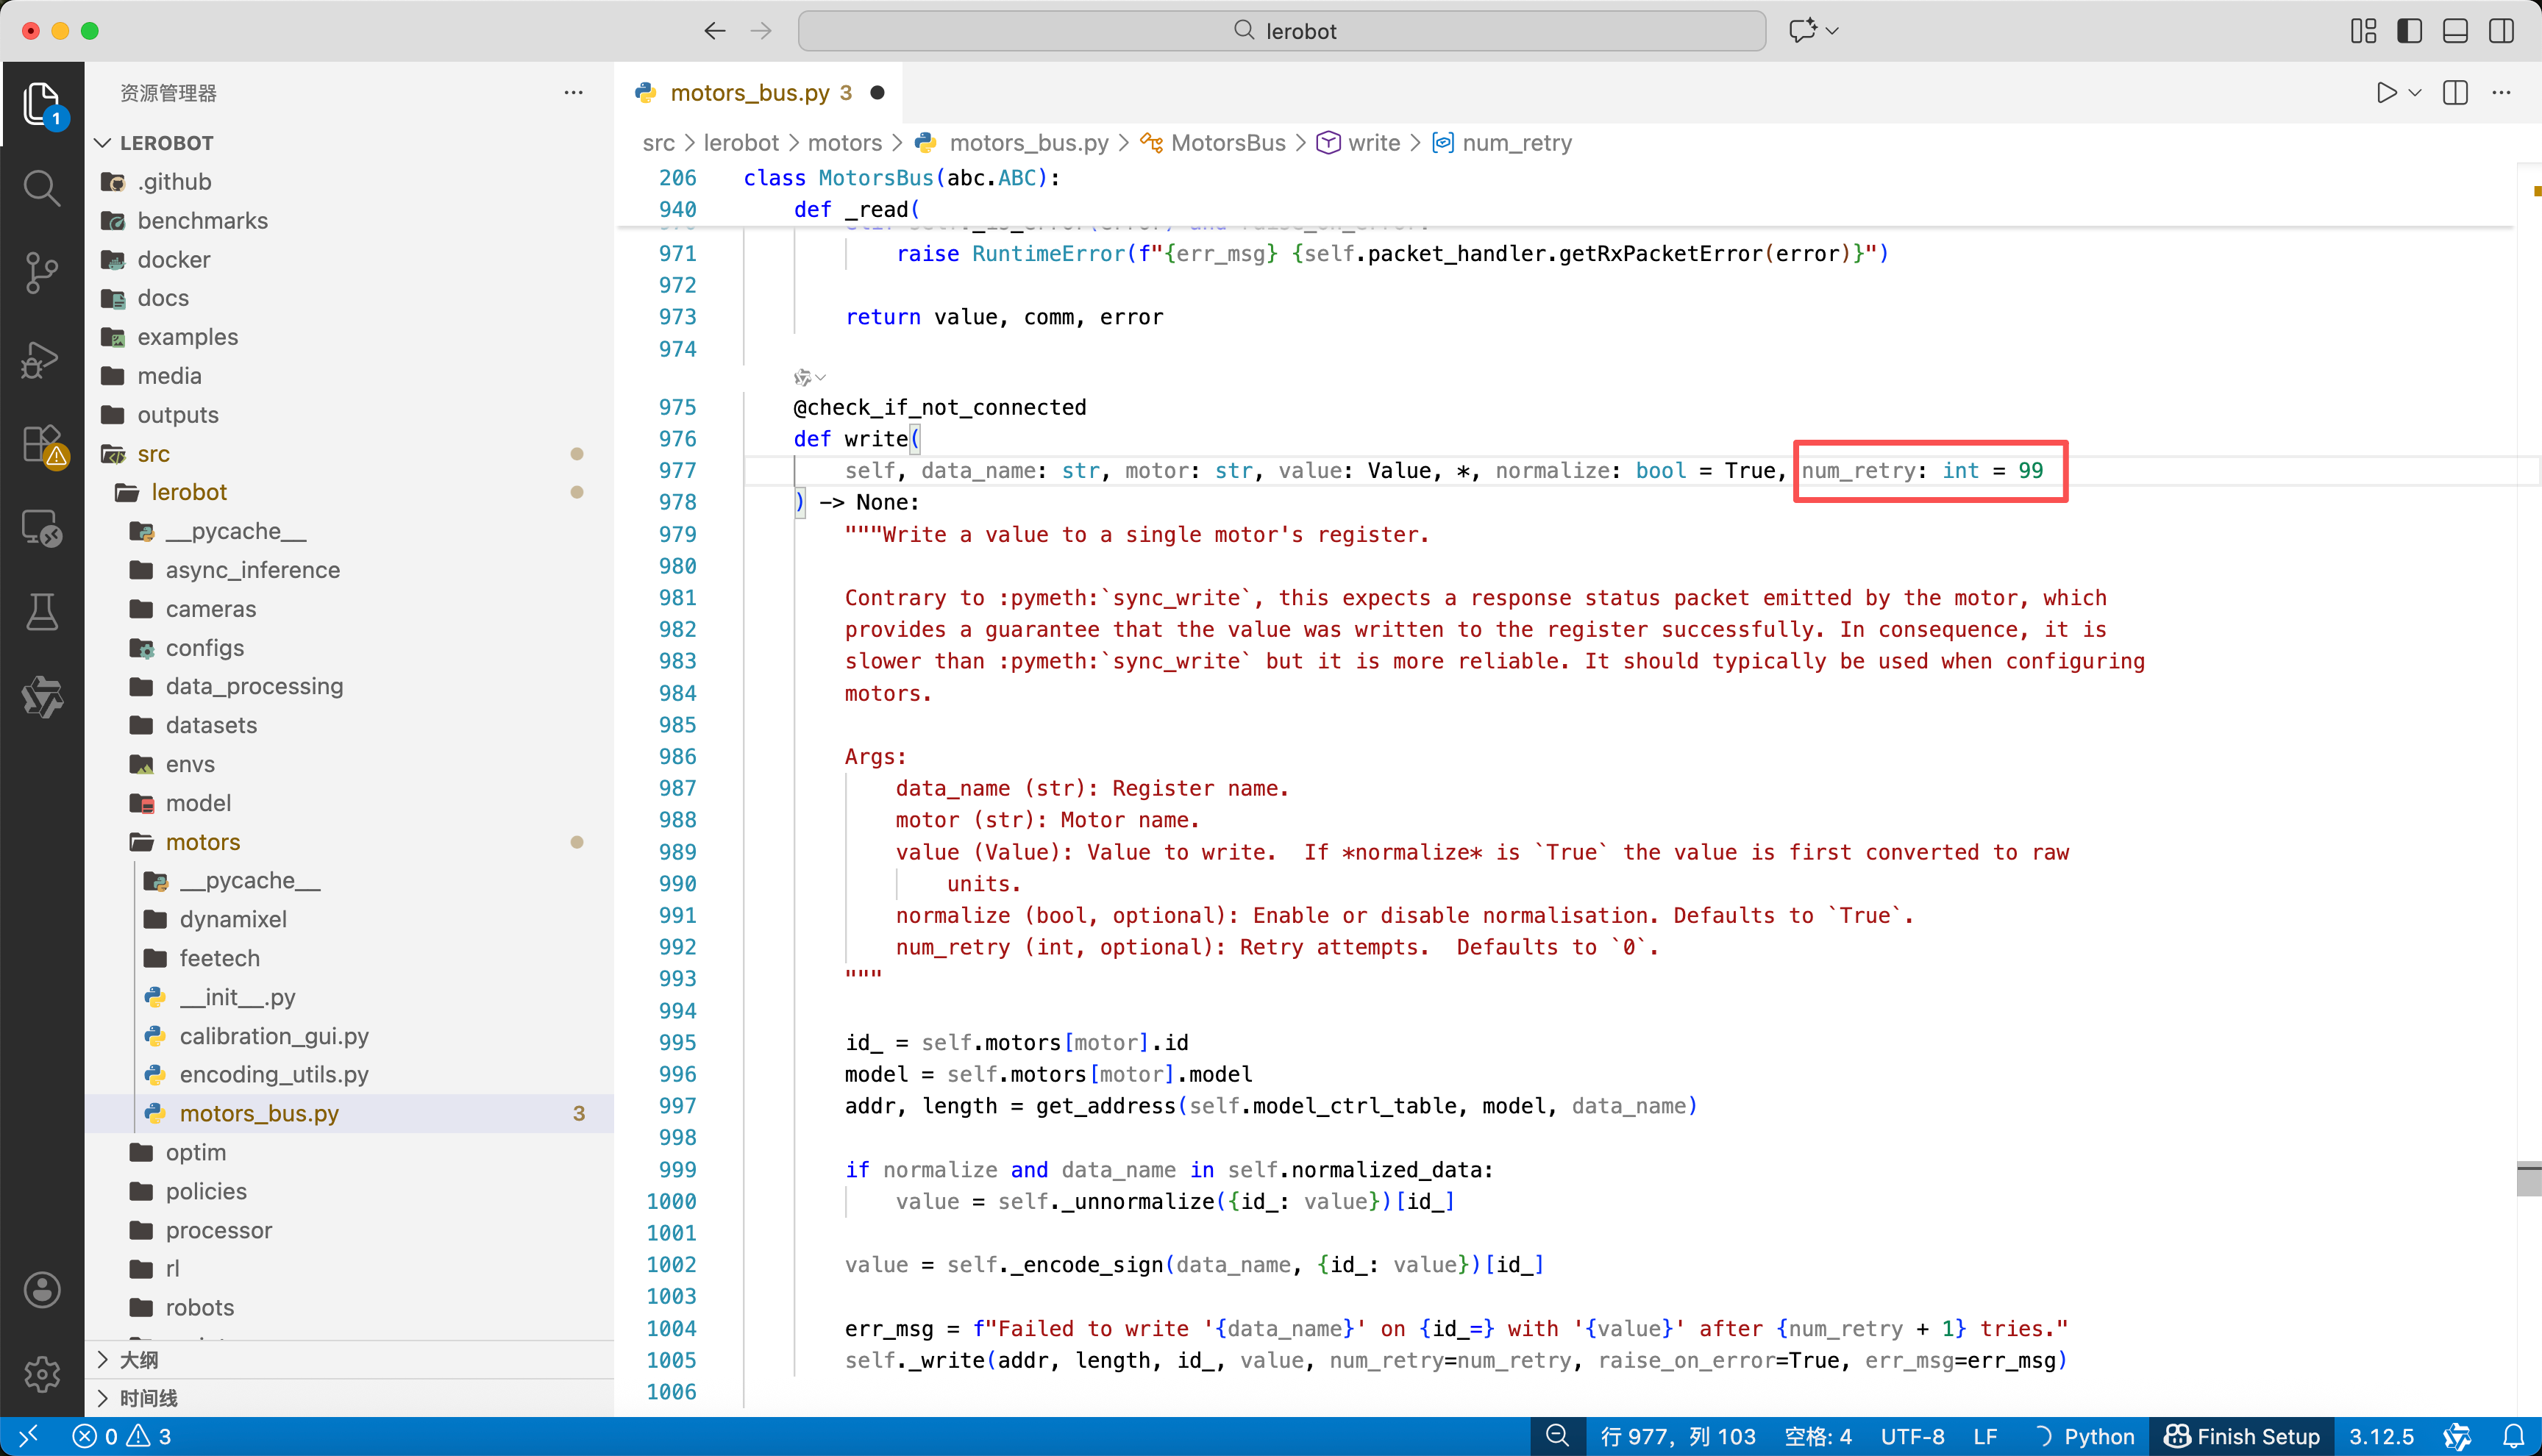
解決方法:lerobot/src/lerobot/motors/motors_bus.pyコード内のすべてのnum_retryを99に変更します。特にエラー行に対応するものです
サーボ通信の問題2
ConnectionError: Failed to write 'Torque_Enable' on id_=1 with '0' after 6 tries. [TxRxResult] There is no status packet!
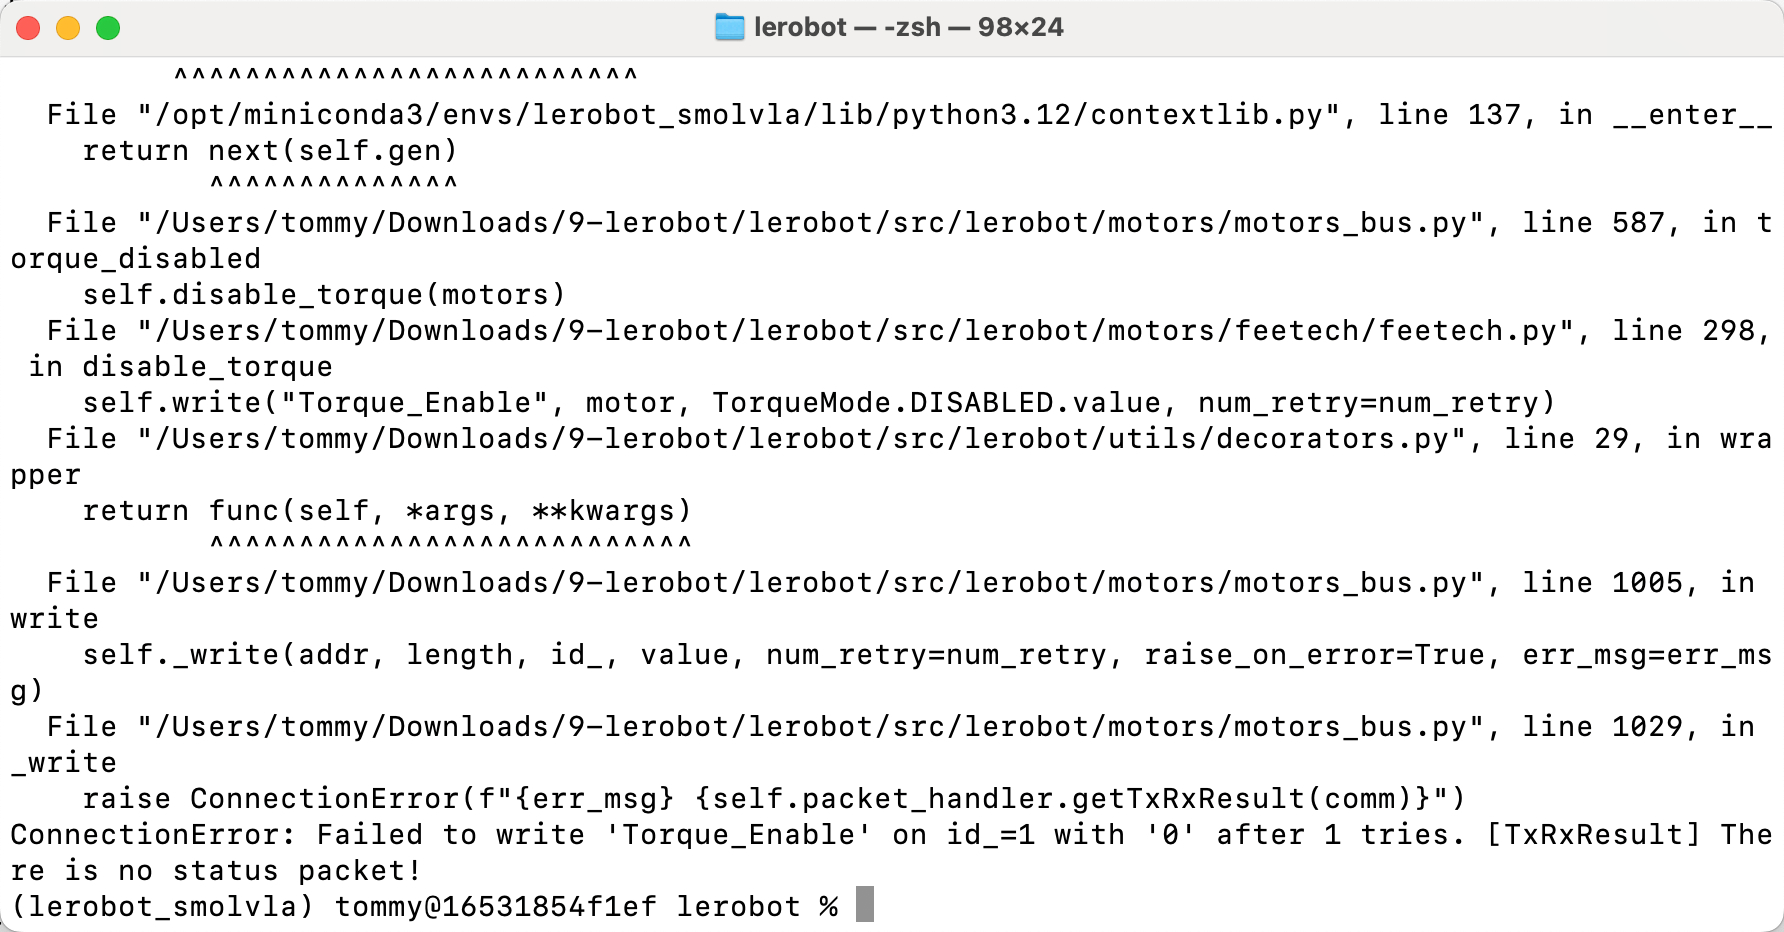
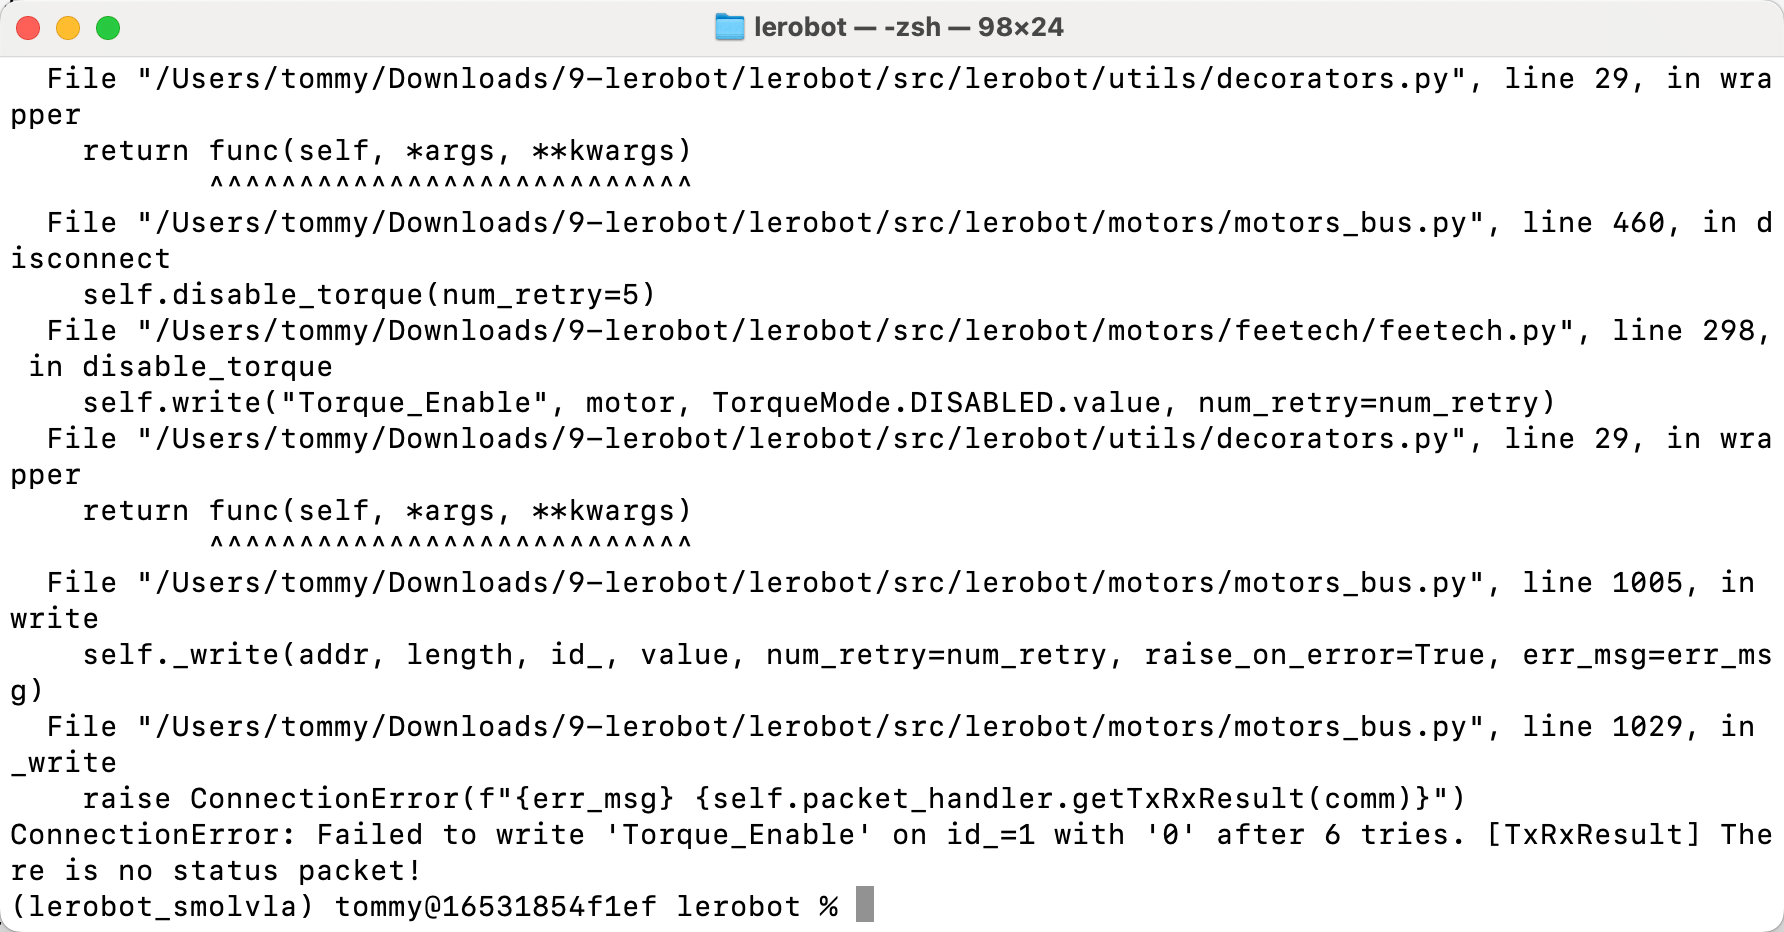
解決方法:ロボットアームを再キャリブレーションする