

Common Bugs and Fixes
Camera acquisition failure
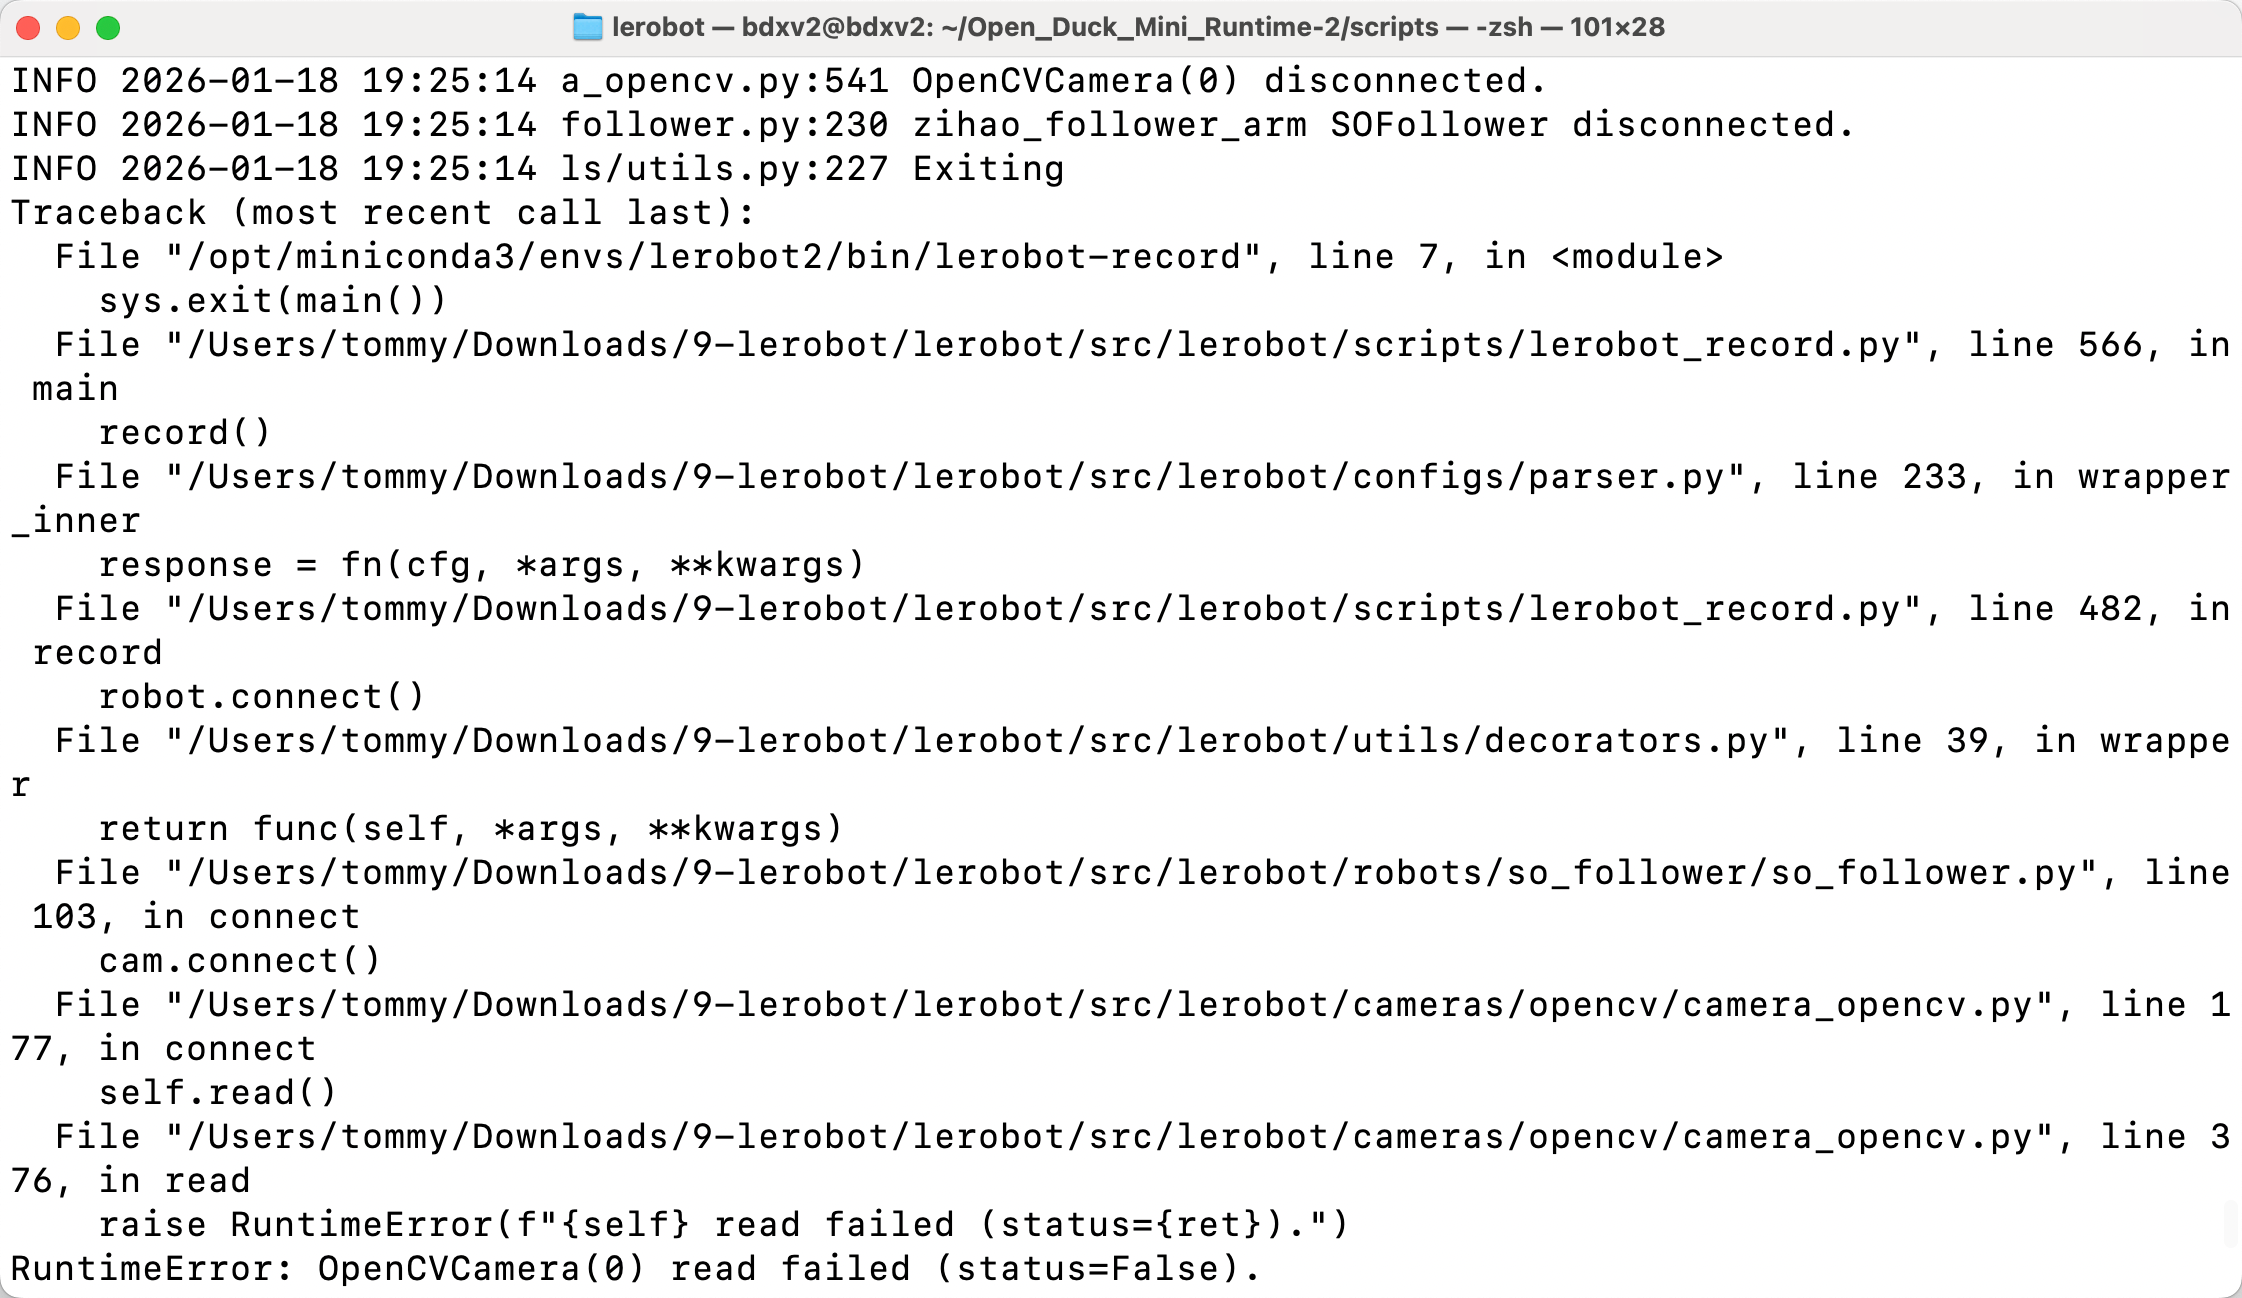
Check whether the wiring of the wrist camera is loose, especially the wiring near the camera end, which is very prone to poor contact
Camera disconnection
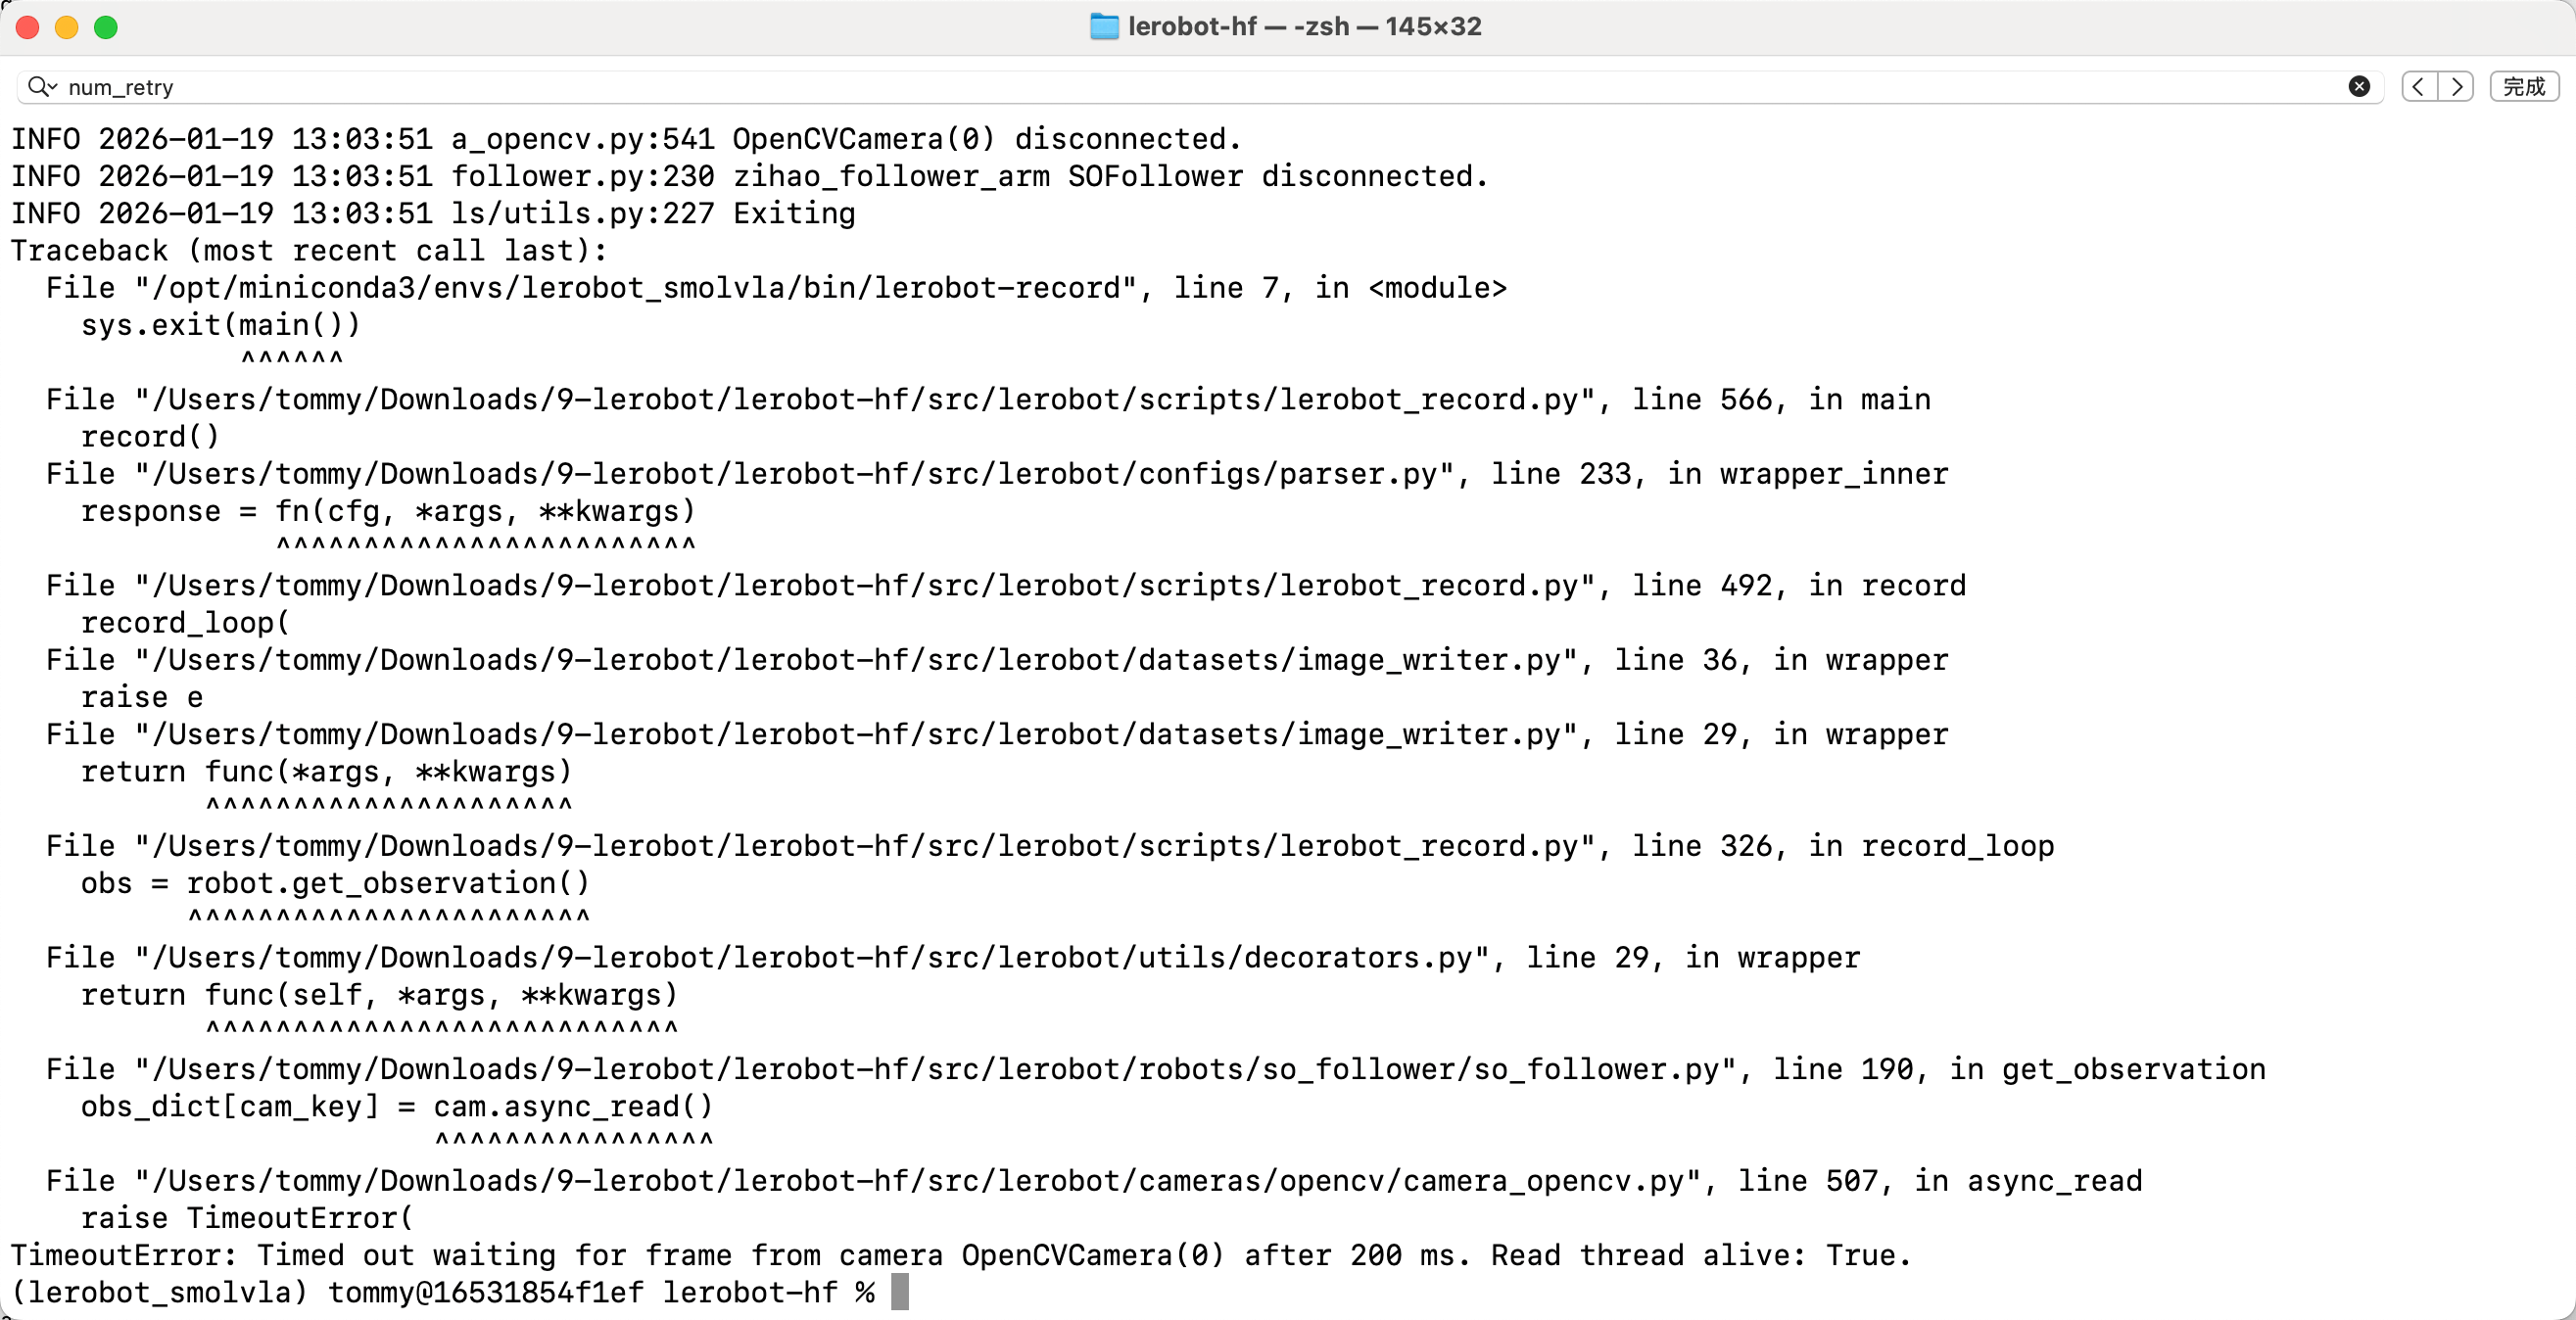
Restart the command line
Servo communication problem 1
ConnectionError: Failed to sync read 'Present_Position' on ids=[1, 2, 3, 4, 5, 6] after 1 tries. [TxRxResult] There is no status packet!
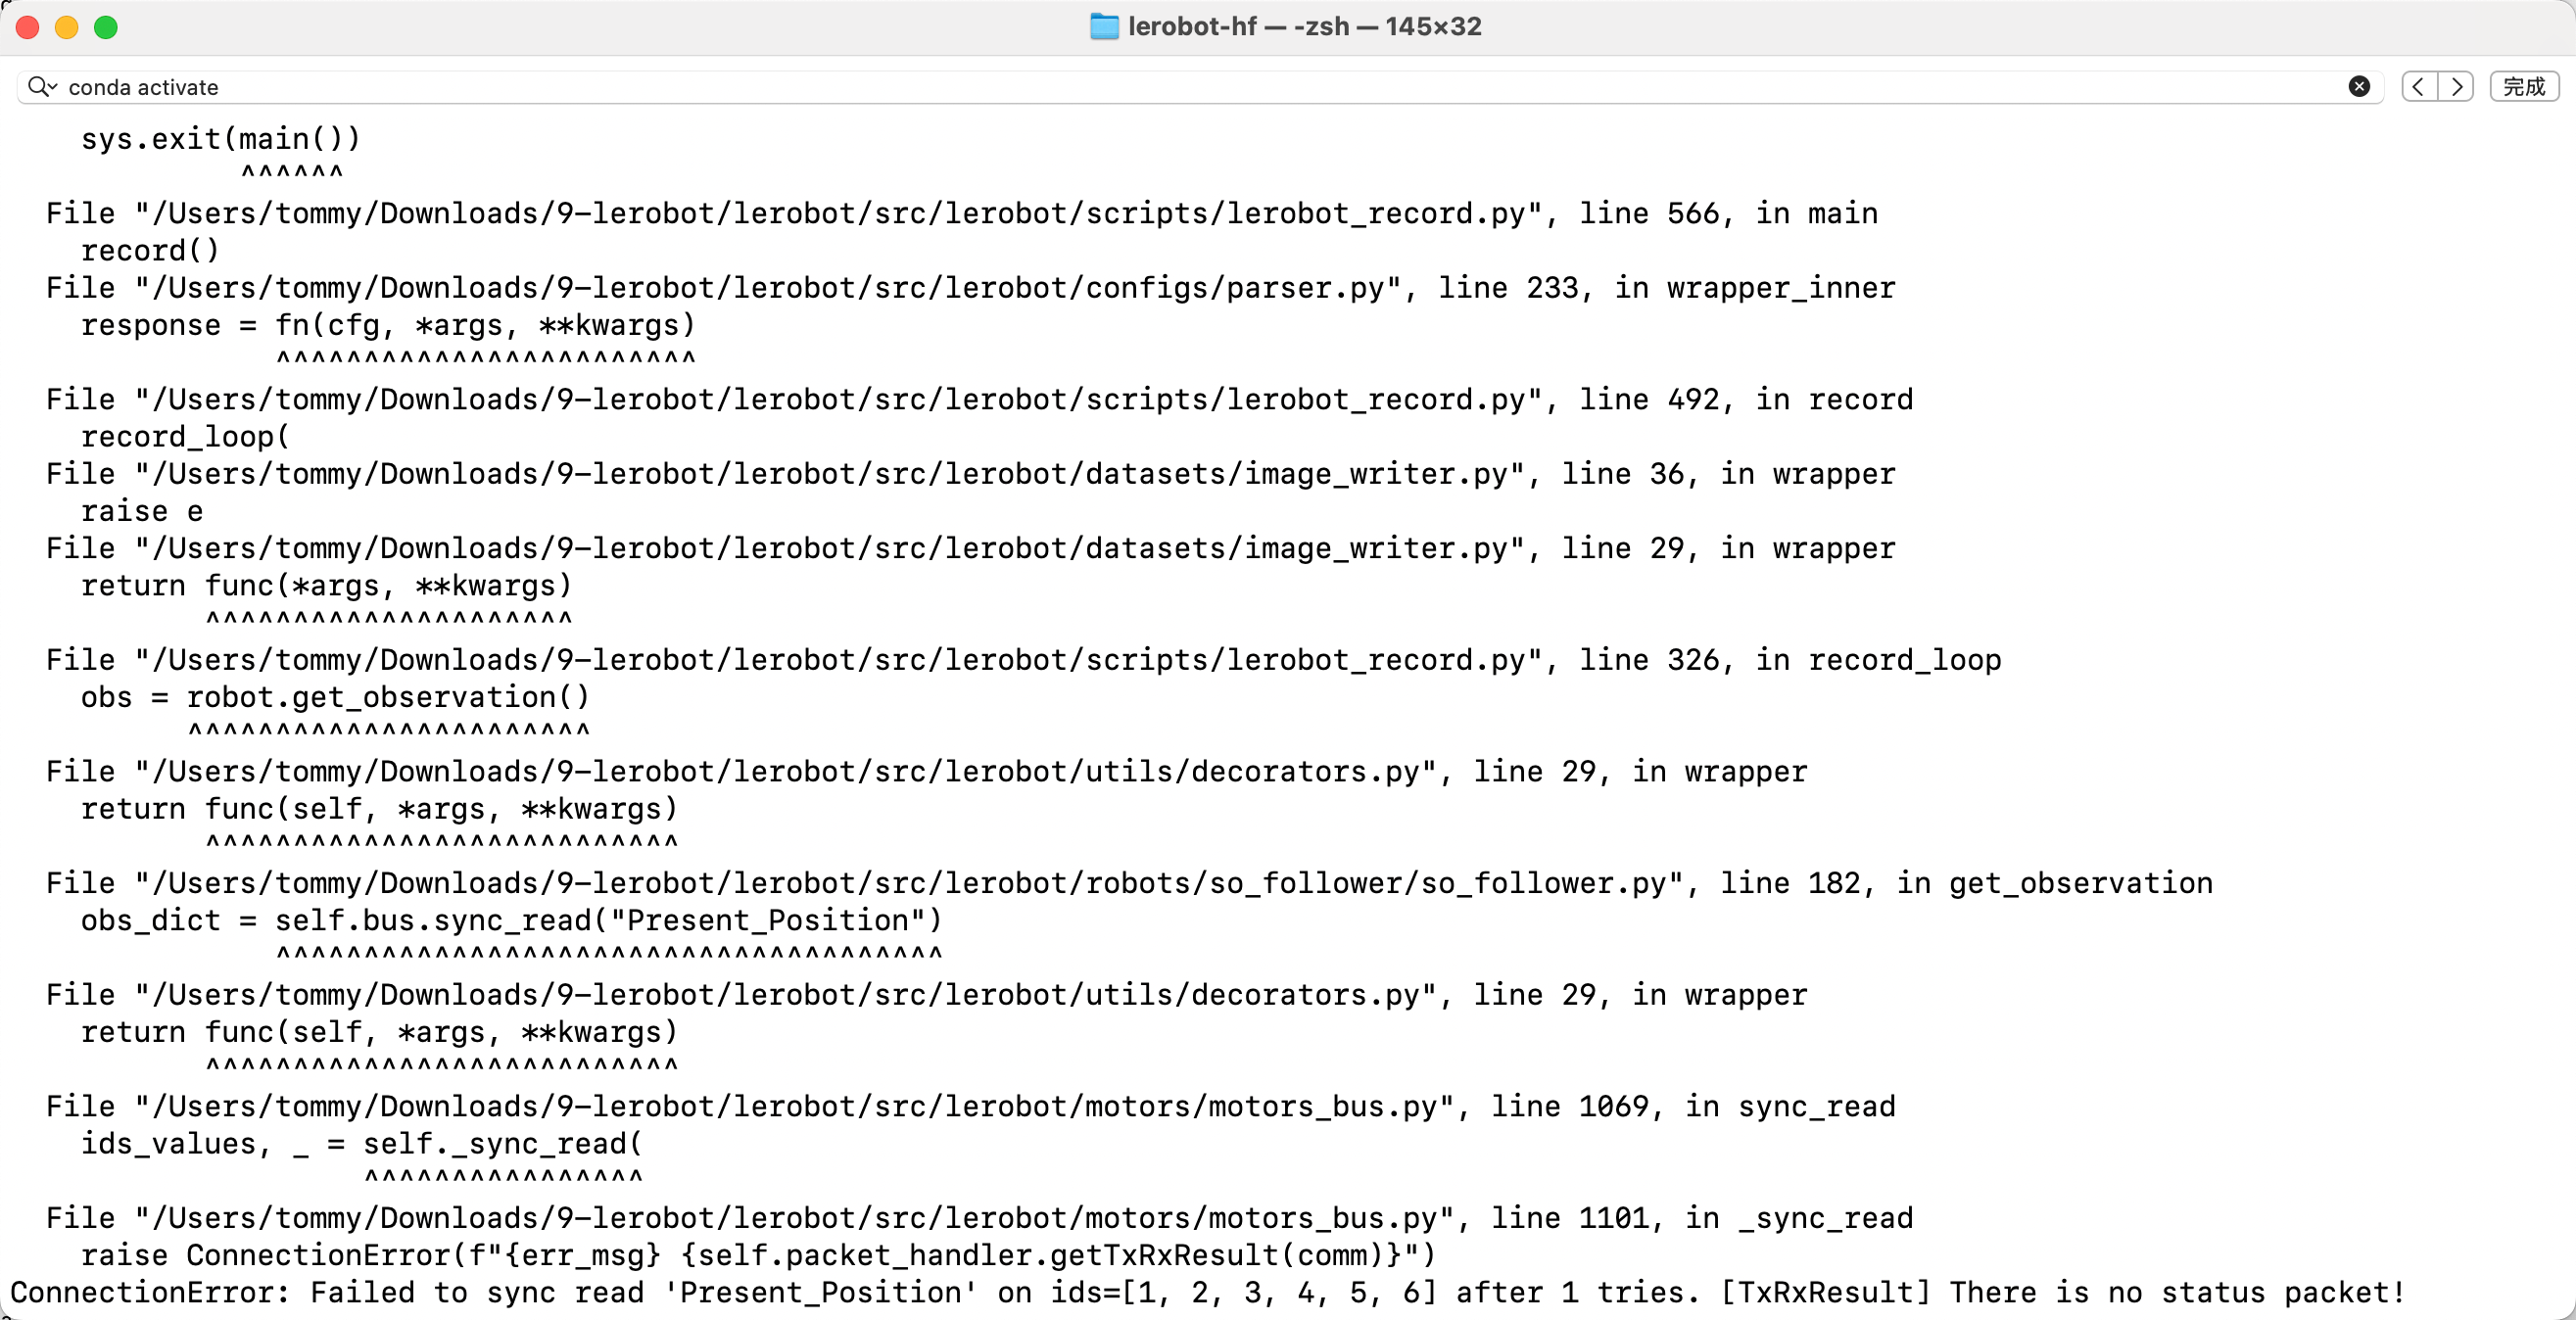
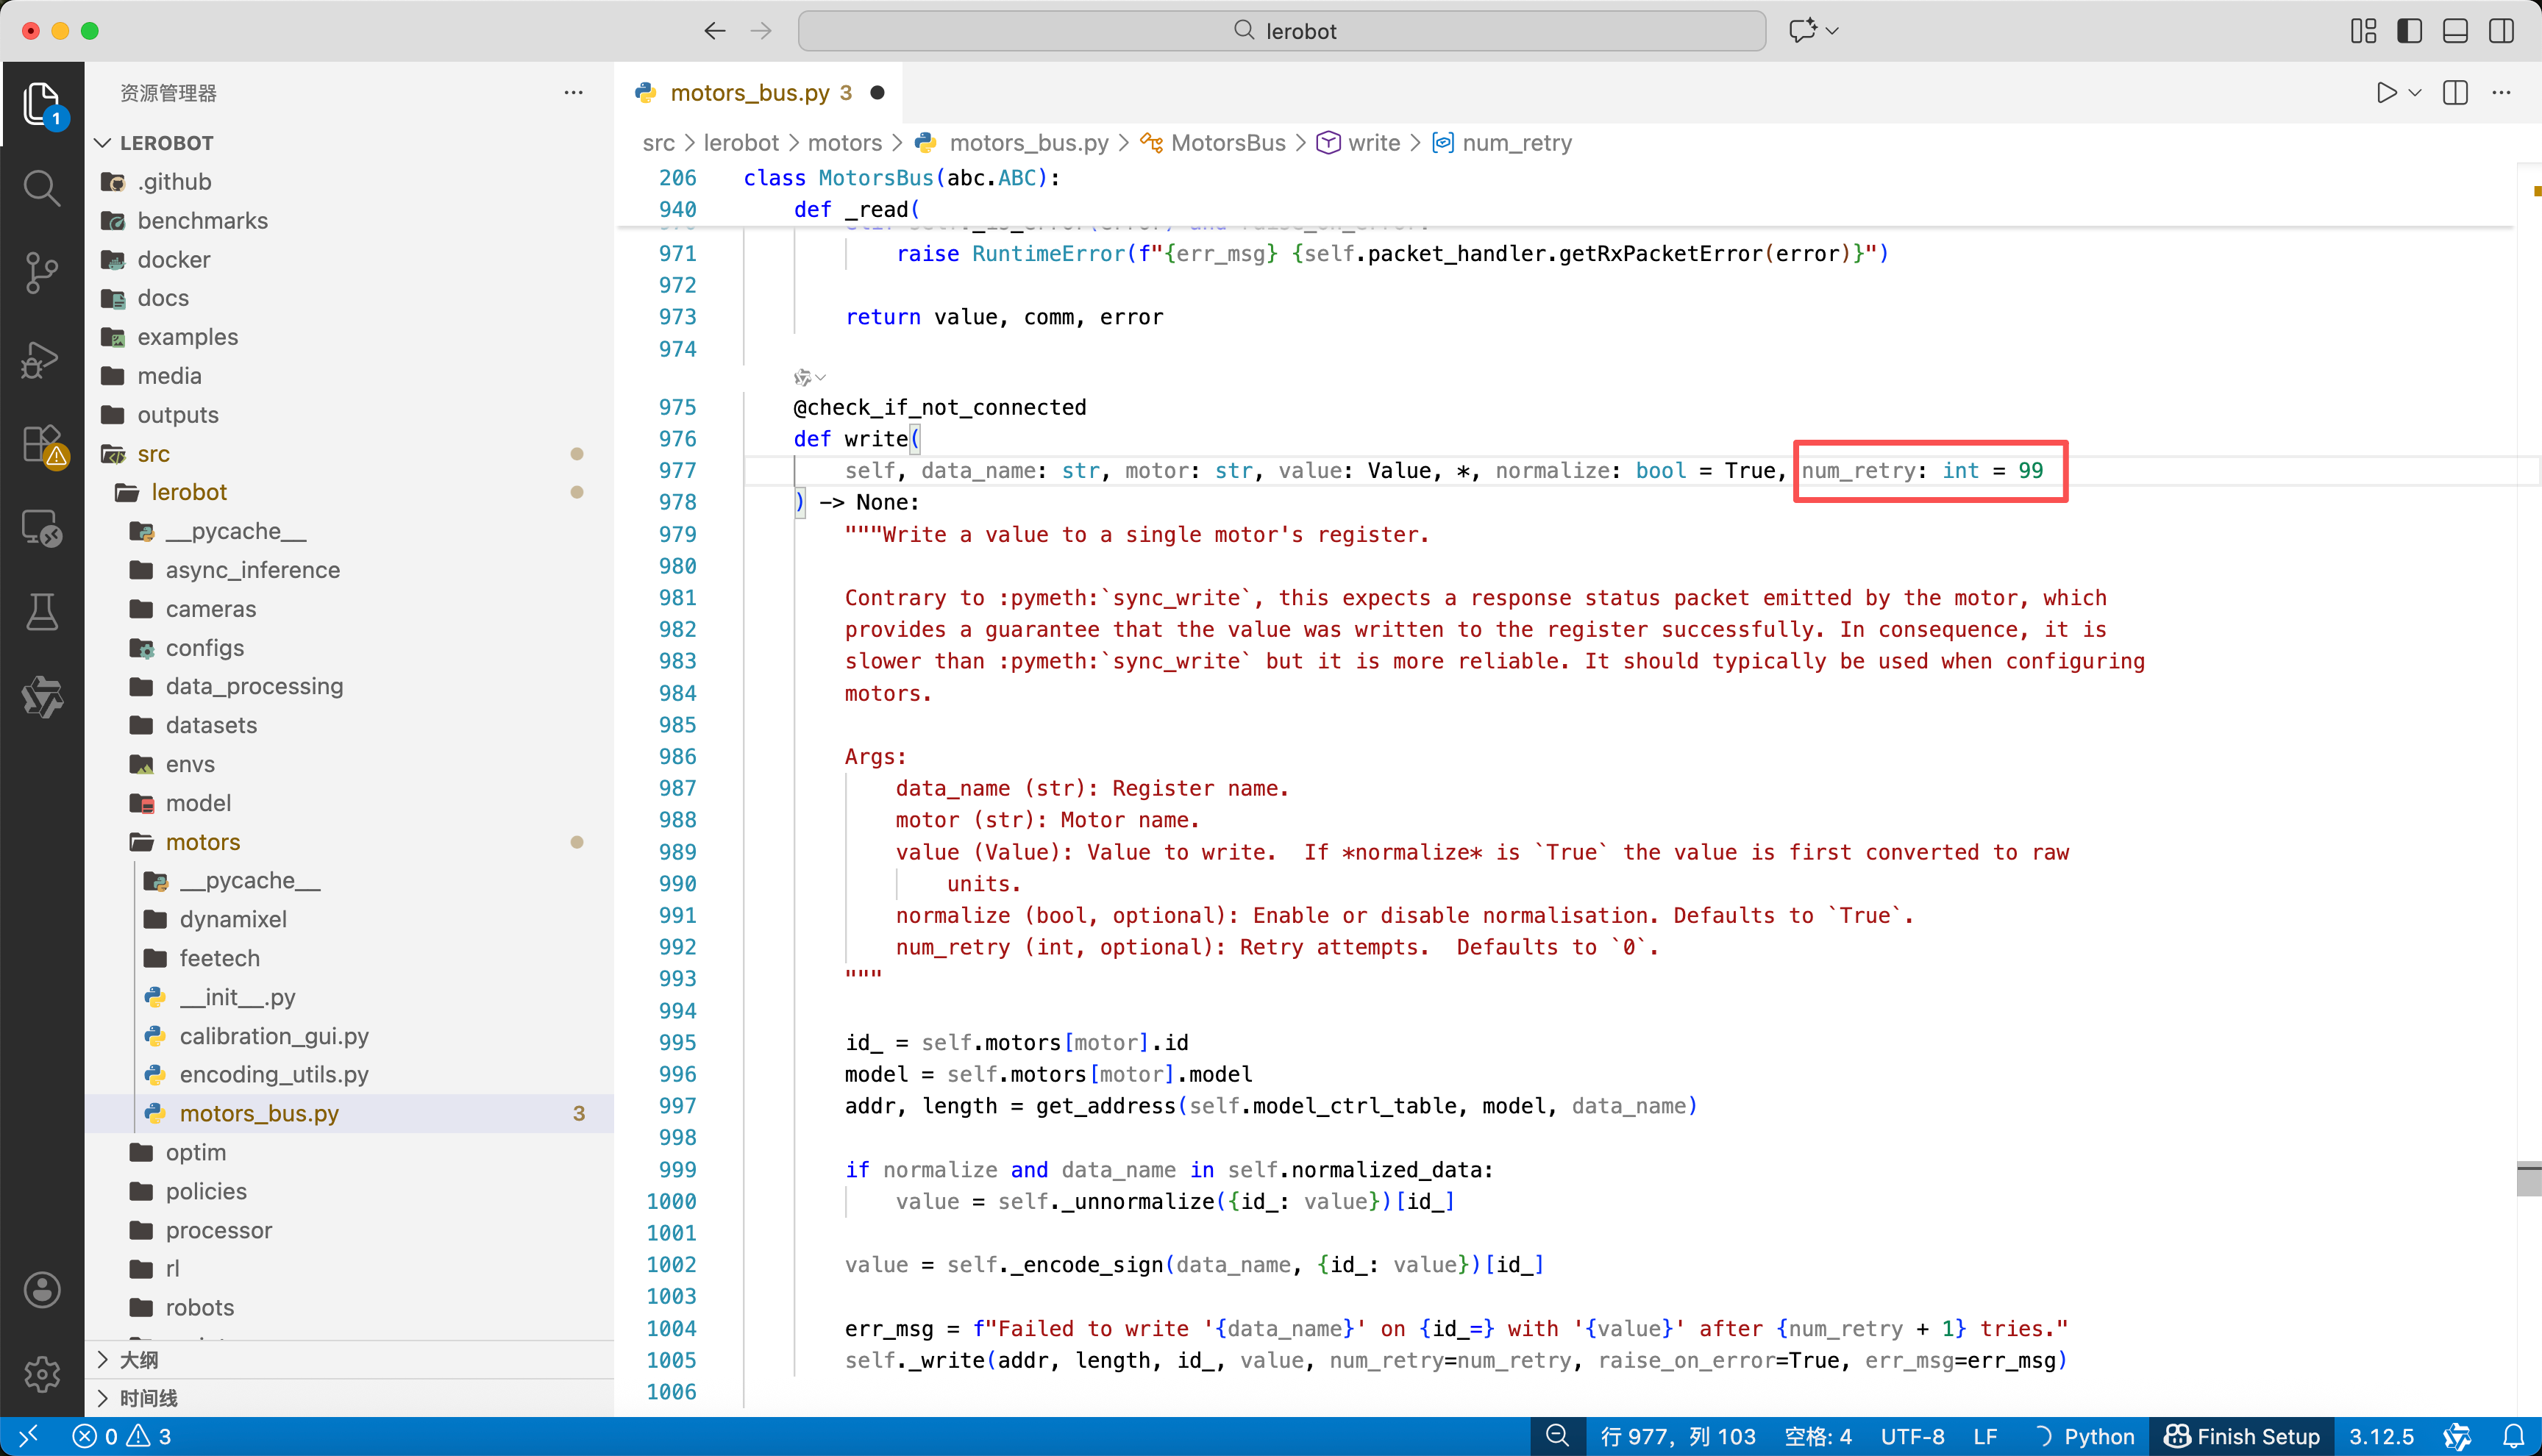
Solution: in the lerobot/src/lerobot/motors/motors_bus.py code, change all num_retry to 99, especially the one corresponding to the error line
Servo communication problem 2
ConnectionError: Failed to write 'Torque_Enable' on id_=1 with '0' after 6 tries. [TxRxResult] There is no status packet!
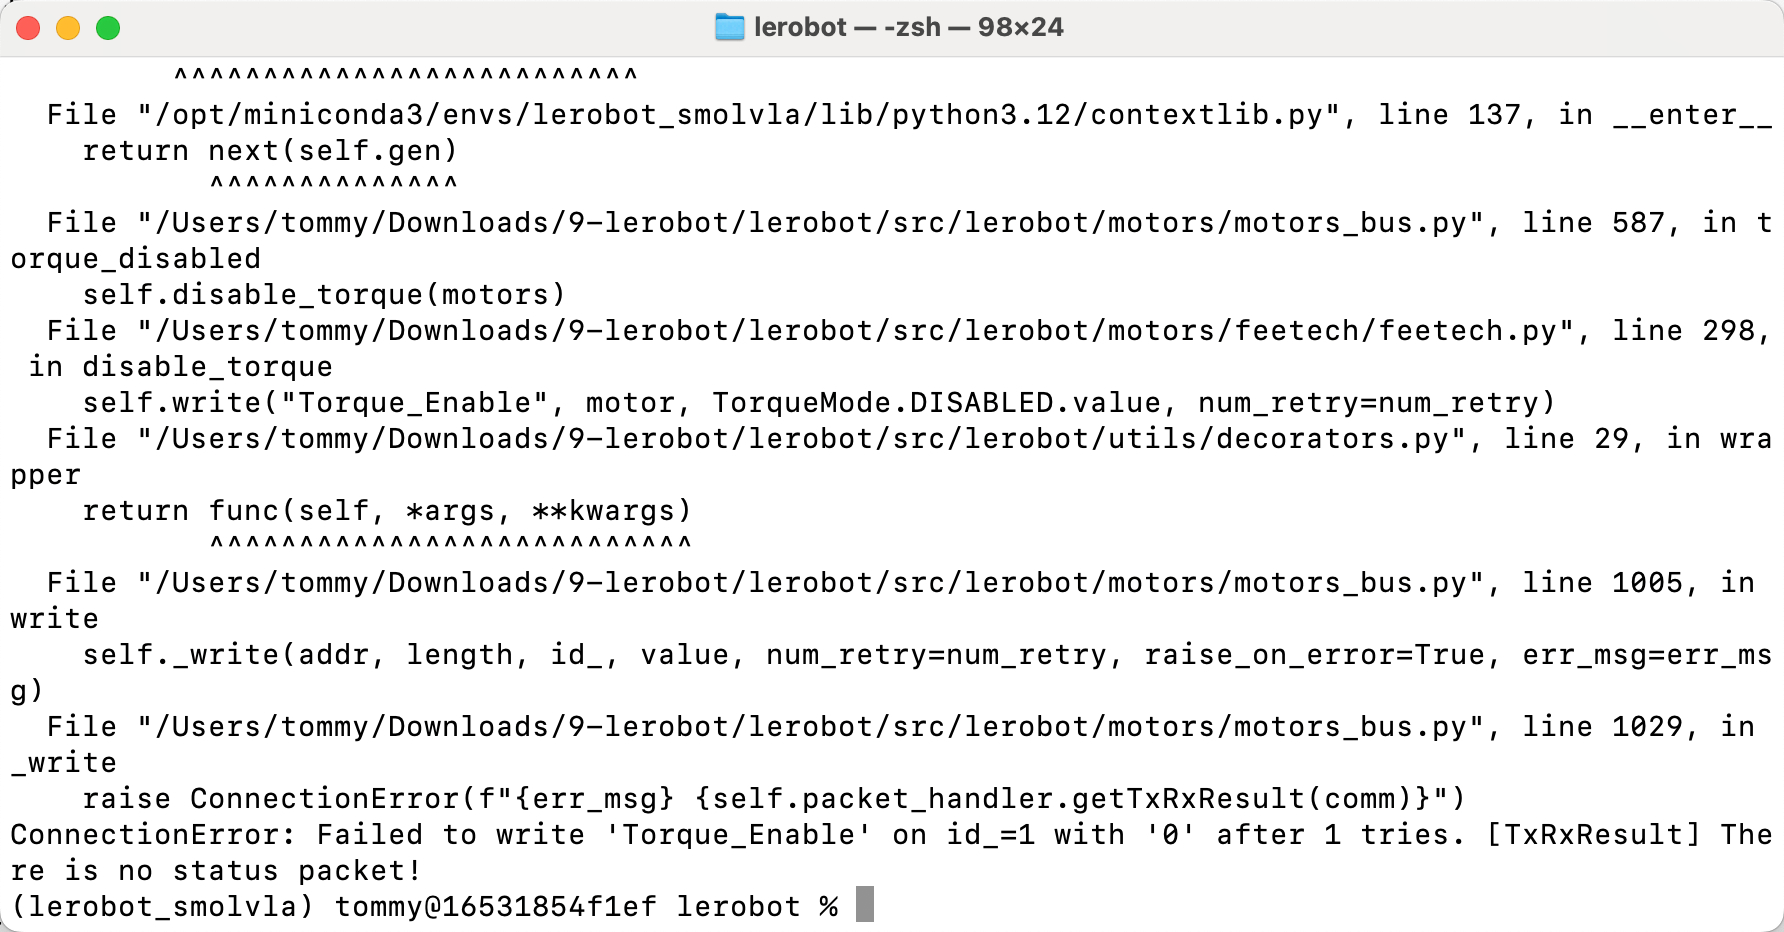
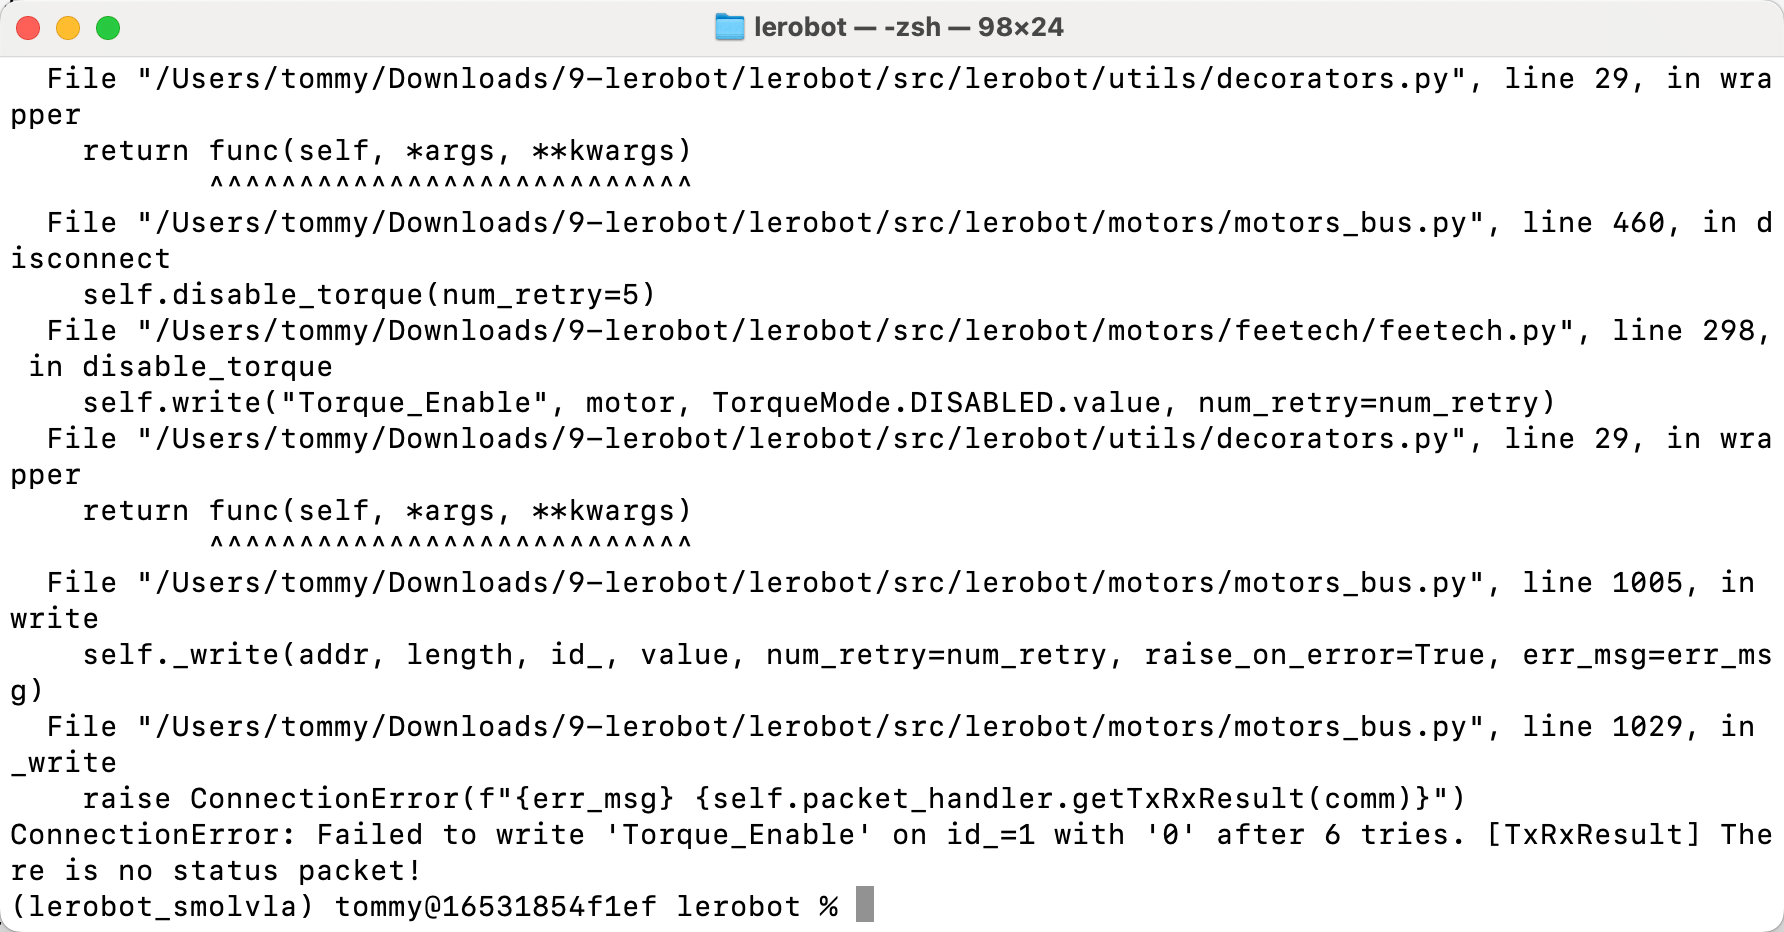
Solution: recalibrate the robotic arm