

Cloud GPU Training Environment Setup
Turn off the network proxy on your own computer
Otherwise the Jupyter command line may not open
Log in to the cloud GPU platform Featurize
https://featurize.cn?s=d7ce99f842414bfcaea5662a97581bd1
Join the user group and tell customer service that you are a fan of "Tongji Zihao" to claim a voucher
Launch a cloud GPU instance
Install and configure the environment
Shell
conda create -y -n lerobot python=3.12
conda activate lerobot
conda install ffmpeg=7.1.1 -c conda-forge -y
# git clone https://github.com/Seeed-Projects/lerobot.git ~/work/Lerobot
git clone https://github.com/huggingface/lerobot.git
cd lerobot
pip install -e ".[pi]"
pip install wandb --upgrade
# export HF_ENDPOINT=https://hf-mirror.com
hf auth login
Log in to wandb
Shell
wandb login
Copy and paste the API key, then press Enter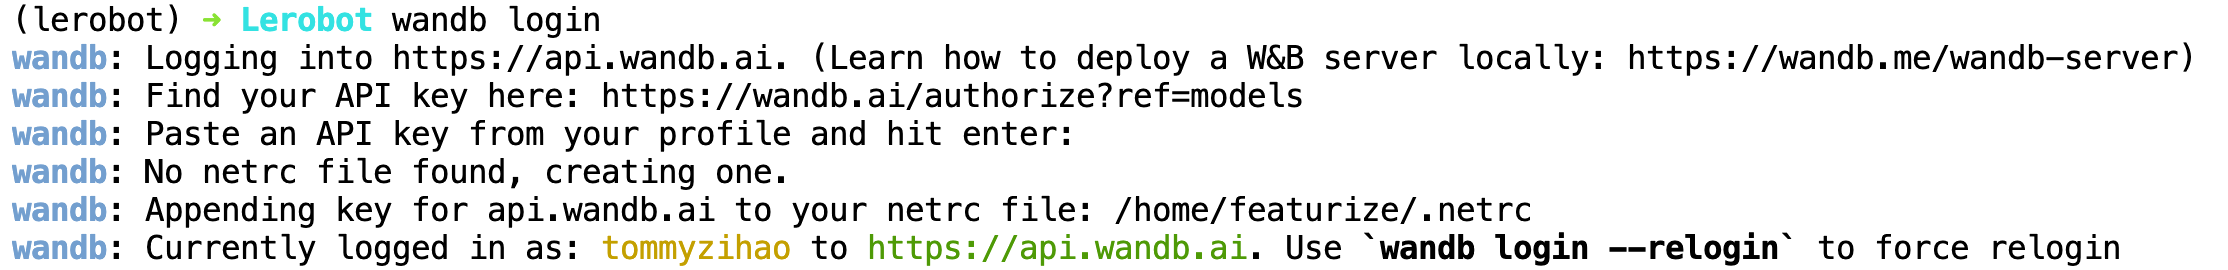
Mounting the dataset
Shell
Copy the instance download command, similar to:
featurize dataset download 7f40bdaa-b1a4-4c00-9652-ff26fd079109

unzip lerobot_zihao_dataset_shake_hands.zip
The dataset will appear under the ~ directory
Change the weight save frequency (optional)
Open lerobot/src/lerobot/configs/train.py
Change save_freq from 20_000 to 5_000
This way you can obtain a model weight file earlier in training