

Robotics on JetPack 7.2 — What Works on the Orin Nano
JetPack 7.2 moved this kit to a new platform generation: Ubuntu 24.04, CUDA 13, and the 8 GB memory ceiling that shapes every AI workload. The robotics ecosystem is still catching up to that move. Some pieces work today. Some do not. Some cannot be verified from any official page yet.
This page is a status page, not a tutorial. Everything here is document-verified only — Juxi has not tested these stacks on hardware. Check the date on any robotics page you read: several parts of this ecosystem changed in August and September 2026. In the diagram below, the large right-hand block runs on the kit; Isaac Sim and Isaac Lab sit in the Omniverse block on the left, which is a separate host.
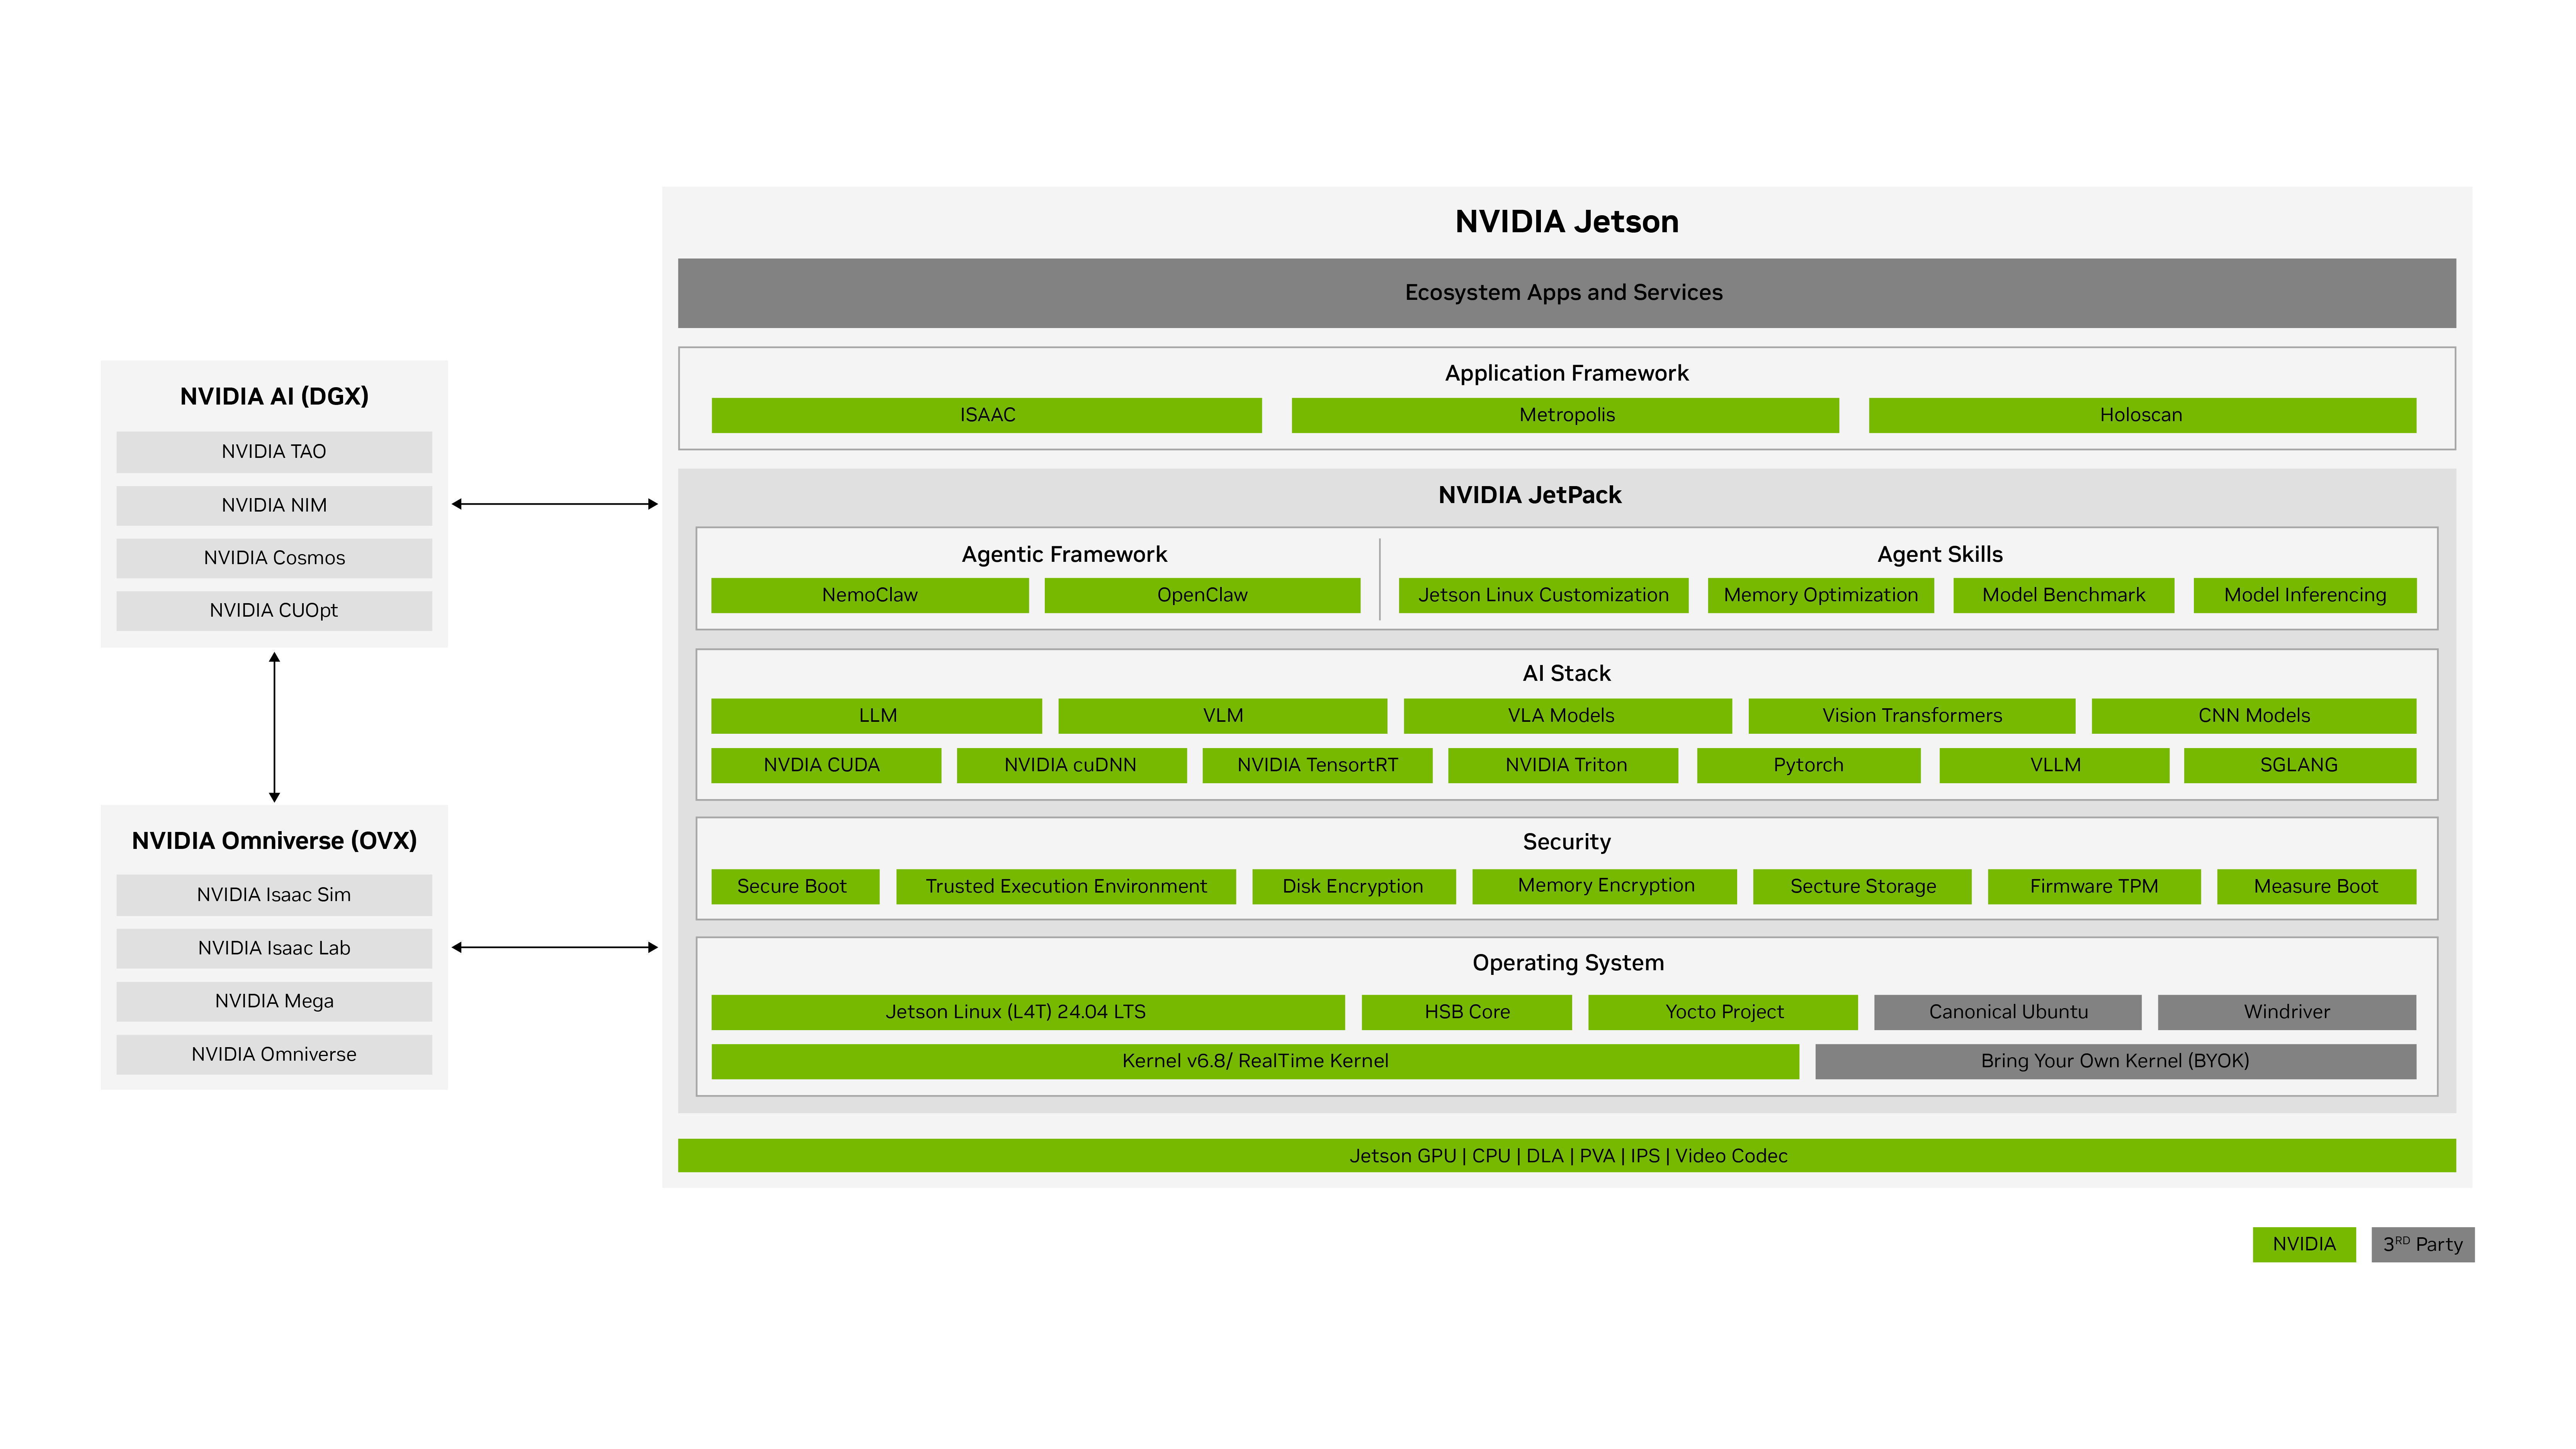
Status table (checked 2026-09-26)
| What you need | Status on JetPack 7.2.1 / Orin Nano (8GB) | Notes |
|---|---|---|
| ROS 2 (core) | ✅ Works | JetPack does not install or require any ROS distribution. ROS 2 Jazzy has official Ubuntu 24.04 arm64 packages. An NVIDIA employee forum answer (2026-09-07) calls Jazzy "the recommended ROS distribution for JetPack 7.2.1". Forum answers are not official documentation. Install steps below. |
| Isaac ROS (hardware-accelerated ROS 2) | ⚠️ Shipped August 2026 — with real gaps | Isaac ROS 4.6.0 release notes: "Added support for Jetson Orin" and "Added support for JetPack 7.2". Orin Nano Super 8GB appears in NVIDIA's official benchmark table. But the walkthroughs have no Orin Nano section, the support table expects an NVMe SSD, and NVIDIA's JetPack page still says "Coming soon". Details below. |
| Isaac Sim / Isaac Lab (simulation) | ⛔ Does not run on this kit | Needs an x86_64 host with an RTX GPU (minimum GeForce RTX 4080, 16 GB VRAM, 32 GB RAM). GPUs without RT cores are not supported. aarch64 builds exist only for DGX Spark. In simulation workflows the simulator runs on the x86_64 machine, not the Jetson. |
| GR00T (humanoid foundation models) | ⛔ Not on this kit | GR00T 1.7 post-training needs a GPU with at least 48 GB VRAM. NVIDIA's reference workflow uses a Jetson AGX Thor as the real-robot edge computer. The same workflow converts demonstration data to LeRobot format — the software direction matches, but the compute does not live here. |
| LeRobot-style Python stacks (SO-ARM101, LeKiwi, vision kit) | ⚠️ Needs verification | The Python version floor is met (Ubuntu 24.04 ships Python 3.12.3; LeRobot requires 3.12 or newer). But upstream has no official JetPack 7.2 path, and the documented Jetson route is community-maintained for JetPack 6.2. Test your exact stack before committing. |
| DeepStream | — Not verified in this review | Covered by its own page — see DeepStream Video Analytics. This robotics review did not re-check the DeepStream support matrix. |
| TensorRT Edge-LLM | — Not verified in this review | Covered by its own page — see Local LLM Inference. Relevant to robotics mainly through VLA-style models. |
| NemoClaw (agentic stack) | ⚠️ Works, de-facto support | The installer auto-detects Jetson (Orin and Thor), and NVIDIA's site markets "Install OpenClaw on Your NVIDIA Jetson Orin Nano™". But the official platform matrix has no Jetson row, and the project is alpha / "Early preview". 8 GB is the stated minimum RAM (16 GB recommended) with a documented out-of-memory risk. See Agentic AI. |
Isaac ROS on JetPack 7.2 — what the official pages say today
The NVIDIA pages disagree with each other. The JetPack 7.2.1 downloads page still lists "NVIDIA Isaac™ ROS — Coming soon". The Isaac ROS project pages say support has shipped. For Isaac ROS itself, the project pages are the more specific source, and they are newer:
- Isaac ROS 4.6.0 (2026-08-18) — release notes: "Added support for Jetson Orin" and "Added support for JetPack 7.2". First 4.x release with that combination.
- Supported platforms: "The platforms defined in this table are the only hardware and software combinations that Isaac ROS tests and officially supports." The Jetson row: "Jetson Thor (T5000 and T4000) and Jetson Orin", JetPack 7.2, storage "128+ GB NVMe SSD". The table says "Jetson Orin" (the family), not "Orin Nano".
- Benchmarks: the performance table has a dedicated "Orin Nano Super 8GB" column with real entries — for example AprilTag Node at 720p, 104 fps, and Mobile SAM graph at 720p, 4.80 fps. These are NVIDIA's published figures for this device, not Juxi measurements. Heavier workloads show a dash ("–"): FoundationPose, Grounding DINO, and full SAM are not listed as runnable.
- Isaac ROS 5.0.0 (2026-09-21) moved to ROS 2 Lyrical Luth. The public ROS 2 apt repository does not provide ROS 2 Lyrical packages for Ubuntu 24.04; NVIDIA publishes them on its own Isaac ROS Buildfarm CDN. Isaac ROS 4.6 stays on ROS 2 Jazzy. Pick 4.6 for the mainstream Jazzy stack.
Gaps to know before you commit:
- No Orin Nano setup section. The Jetson walkthroughs cover only Jetson AGX Thor and Jetson AGX Orin; the only Orin-Nano-relevant link is the power-settings guide.
- An NVMe SSD is expected. The storage column says "128+ GB NVMe SSD". This kit ships with no storage at all, so a microSD-only setup sits outside the stated expectation (see Quick Start).
- Version skew. The 4.6 setup pages ask you to confirm "R39 (release), REVISION: 2.0" (L4T r39.2.0) from
cat /etc/nv_tegra_release; this kit ships JetPack 7.2.1 = L4T r39.2.1. Validate in Docker before migrating a production robot. - Cameras and OpenCV. Intel RealSense cameras are "supported only in Docker mode. Virtual Environment and Bare Metal modes are not supported." JetPack 7.2 also installs OpenCV 4.8.0 while Isaac ROS is tested with 4.6.0 — the fix is in the install steps below.
- A 5.0 regression. In Isaac ROS 5.0, the DNN image encoder may have lower throughput than in 4.6. If that node matters, consider 4.6.
Important: If Isaac ROS is on your critical path, weigh the timing. Support on JetPack 7.2 is real but new (August 2026), and the Orin Nano documentation is thin. This kit was already a supported Isaac ROS target in the JetPack 6.2 era (Isaac ROS 3.2 Update 1, January 2025). A team that needs the longest-established combination, and cannot absorb first-release churn, has a defensible case for staying on a JetPack 6.2-era setup. Everyone else: move to 7.2.1, but validate your exact pipeline in Docker on this kit before you commit.
Simulation and training — a different machine
Isaac Sim 6.0 cannot run on this kit. Published minimums for the Linux x86_64 path: GeForce RTX 4080, 16 GB VRAM, 32 GB RAM, 50 GB SSD. "GPUs without RT Cores (A100, H100) are not supported." The aarch64 build "is currently only supported on DGX Spark system." In Isaac ROS simulation workflows, "Isaac Sim runs on a x86_64 machine providing sensor data and world information" — the Jetson is the deployment target.
At the heavy end of robot learning the split is the same: GR00T 1.7 post-training needs at least 48 GB of VRAM, and NVIDIA's reference workflow uses a Jetson AGX Thor as the real-robot edge computer. The rule: simulate and train on a PC, deploy and run inference on the kit. If Isaac Sim was your reason to consider an Orin Nano, it is the wrong machine for that job.
LeRobot and Python robot stacks — the compatibility question
- The Python version question has a clear answer: 3.12 is fine. Ubuntu 24.04's system Python is 3.12.3, and LeRobot (0.6.2) requires Python 3.12 or newer. The upgrade does not block LeRobot on Python-version grounds.
- But upstream has no JetPack 7.2 path. LeRobot's official installation page states that on Jetson there is no GPU-accelerated video decode by default (the library falls back to pyav), that aarch64 torchcodec wheels need PyTorch 2.11 or newer, and that its Jetson Docker build targets JetPack 6.2 and is community-maintained. No official statement says current LeRobot has ready aarch64 CUDA wheels for JetPack 7.2's CUDA 13.
- So: "needs verification" — not "supported", not "broken". Before designing around LeRobot on this kit, test your exact stack: install it, run a small policy, and confirm that inference uses the GPU.
Juxi note: Our robot kits (SO-ARM101, LeKiwi, vision kit) are built on LeRobot. On this kit under JetPack 7.2.1, no tested path exists yet from either upstream or Juxi. JetPack 6.2 is the reference platform for the community-maintained route. Check with Juxi support (see Downloads) before you commit a project schedule to LeRobot on this kit.
What runs today
ROS 2 Jazzy — the foundation
JetPack does not include ROS. The working path is the official ROS 2 Jazzy deb install for Ubuntu 24.04 (arm64), summarized from the ROS 2 documentation:
sudo apt install software-properties-common
sudo add-apt-repository universe
sudo apt update && sudo apt install curl -y
export ROS_APT_SOURCE_VERSION=$(curl -s https://api.github.com/repos/ros-infrastructure/ros-apt-source/releases/latest | grep -F "tag_name" | awk -F'"' '{print $4}')
curl -L -o /tmp/ros2-apt-source.deb "https://github.com/ros-infrastructure/ros-apt-source/releases/download/${ROS_APT_SOURCE_VERSION}/ros2-apt-source_${ROS_APT_SOURCE_VERSION}.$(. /etc/os-release && echo ${UBUNTU_CODENAME:-${VERSION_CODENAME}})_all.deb"
sudo dpkg -i /tmp/ros2-apt-source.deb
sudo apt update
sudo apt install ros-jazzy-ros-base    # or: ros-jazzy-desktop
source /opt/ros/jazzy/setup.bash
Isaac ROS 4.6 — when you need accelerated perception
Install from NVIDIA's apt repository (the official page lists the exact keyring commands): repository https://isaac.download.nvidia.com/isaac-ros/release-4.6, channel noble-jetpack; China mirror isaac.download.nvidia.cn. Then:
sudo apt-get install isaac-ros-cli
mkdir -p ~/workspaces/isaac_ros-dev/src
echo 'export ISAAC_ROS_WS="${ISAAC_ROS_WS:-${HOME}/workspaces/isaac_ros-dev/}"' >> ~/.bashrc
Remove the preinstalled OpenCV 4.8.0 once (see the gap list above); Isaac ROS then installs its pinned OpenCV 4.6.0 automatically:
sudo apt-get remove -y libopencv* opencv*NVIDIA recommends Docker: "Docker is the recommended option for most users. It provides the highest level of isolation from your host system." This also matches the RealSense camera requirement (Docker only).
NemoClaw and the agentic stack
The installer auto-detects NVIDIA Jetson devices (Orin and Thor) and applies the JetPack-specific host configuration. Two caveats: the project is alpha ("Early preview"), and its official platform matrix has no Jetson row, so support is de-facto, not an official claim. 8 GB is the stated minimum RAM (16 GB recommended), with a documented out-of-memory risk around the roughly 2.4 GB sandbox image. See Agentic AI.
Recommendation
- ROS 2 only: build on JetPack 7.2.1 with ROS 2 Jazzy today. This works.
- Critical on Isaac ROS: supported since August 2026, but new, with thin Orin Nano documentation. Validate in Docker; plan an NVMe. If you need the longest-established combination, a JetPack 6.2-era setup stays defensible — see the migration guide for the rebuild costs either way.
- Needs simulation or training: budget a separate RTX PC (Isaac Sim) and a Thor-class device for GR00T-class work. This kit cannot do either job.
- Built on LeRobot: needs verification. Test first; JetPack 6.2 is the reference for the documented route.
- Do not buy this kit for: Isaac Sim, GR00T post-training, or real-time full SAM / Grounding DINO / FoundationPose-class workloads — the last three are not listed as runnable in NVIDIA's benchmark table for this device.
Still unclear
- micro-ROS: no official Jetson-specific page found (two official micro.ros.org URLs return 404 today). Treat the pairing as unverified.
- ROS distribution after Isaac ROS 5.0: the forum answer recommending Jazzy predates 5.0 (2026-09-21); no post-5.0 statement found.
- LeRobot on JetPack 7.2: no official statement; check PyTorch aarch64 wheel availability for CUDA 13 before committing.
- microSD-only setups with Isaac ROS: the support table says NVMe, but this is not restated for Orin Nano specifically.
- "Jetson Orin" vs "Orin Nano": the platform table uses the family name; "Orin Nano Super 8GB" appears only in the benchmark table. Not resolved whether NVIDIA treats these as separate support claims.
- DeepStream and TensorRT Edge-LLM: not re-verified in this robotics review — see their own pages.
Sources
- Isaac ROS — Getting Started (supported platforms, Docker, ROS 2 Lyrical; checked 2026-09-26)
- Isaac ROS 4.6 — Getting Started (Jazzy pairing, apt install, OpenCV note; checked 2026-09-26)
- Isaac ROS 5.0 — Getting Started (Isaac Sim on x86_64; checked 2026-09-26)
- Isaac ROS — Releases (4.6.0 and 5.0.0 notes; RealSense and DNN-encoder limitations; checked 2026-09-26)
- Isaac ROS — Performance (Orin Nano Super 8GB benchmark column; checked 2026-09-26)
- Isaac ROS Buildfarm CDN (ROS 2 Lyrical packages for Ubuntu 24.04; checked 2026-09-26)
- Isaac Sim 6.0 installation requirements (checked 2026-09-26)
- GR00T end-to-end workflow — prerequisites (checked 2026-09-26)
- NVIDIA developer forum — "Is ROS2 Jazzy the correct version..." (employee answer; forum, not official docs) (checked 2026-09-26)
- ROS 2 Jazzy installation — deb packages (upstream) (checked 2026-09-26)
- ROS 2 Jazzy installation — apt repositories (upstream) (checked 2026-09-26)
- LeRobot installation guide (upstream) (checked 2026-09-26)
- LeRobot pyproject.toml (upstream) (Python and torchcodec pins; checked 2026-09-26)
- Ubuntu Noble — python3 package (Python 3.12.3; checked 2026-09-26)
- NemoClaw — prerequisites (checked 2026-09-26)
- NemoClaw — platform support matrix (alpha stage; no Jetson row; checked 2026-09-26)
- NemoClaw — installer troubleshooting (Jetson auto-detect) (checked 2026-09-26)
- NVIDIA — Build a Claw ("Install OpenClaw on Your NVIDIA Jetson Orin Nano™") (checked 2026-09-26)
- JetPack 7.2.1 downloads page (component matrix lists Isaac ROS as "Coming soon") (checked 2026-09-26)
Status: draft, pending review by cheny. Ecosystem availability changes quickly — re-check the linked NVIDIA and upstream pages before relying on this table. Not yet verified on physical hardware by Juxi Technology.
NVIDIA® and Jetson™ are trademarks of NVIDIA Corporation. This page is published by Juxi Technology and is not an NVIDIA publication.