Product Info
Introduction to IMU Module
Built-in high-precision IMU attitude sensor 72MHz high-performance 32-bit processor, capable of real-time attitude calculation and dynamic compensation, with a data update frequency of up to 100Hz, combining the advantages of rapid response and stable output. It supports both IIC and serial communication modes, is compatible with single-chip microcomputers and Linux main controllers, and can be seamlessly integrated with the ROS system, widely applicable to high-performance application scenarios such as robot motion control, UAV attitude stabilization, and intelligent navigation and positioning.
1. Version Overview
| Performance Comparison | |||
|---|---|---|---|
| 6-Axis | 9-Axis | 10-Axis | |
| High-performance 32-bit processor | √ | √ | √ |
| 3-axis gyroscope | √ | √ | √ |
| 3-axis accelerometer | √ | √ | √ |
| 3-axis magnetometer | - | √ | √ |
| Barometer | - | - | √ |
| AHRS attitude data fusion algorithm | - | √ | √ |
| Mahony filter algorithm | √ | √ | √ |
| Communication interface | Type-C (requires base board) / IIC pin header | ||
| Communication method | IIC / serial | ||
| Positioning / Application scenarios | Designed for cost-sensitive applications, meeting the standard for high-dynamic-response applications | Built on the 6-axis hardware architecture with an integrated 3-axis magnetometer module, tuned with the AHRS attitude data fusion algorithm, greatly enhancing the stability and measurement accuracy of data output | Adds a barometer on top of the 9-axis sensing architecture, capable of outputting precise altitude information, suitable for application scenarios with higher requirements for 3D spatial attitude and position perception |
Pin Function Description
| SDA | I2C serial data line |
|---|---|
| SCL | I2C serial clock line |
| GND | Ground |
| 3V3 | 3V3 |
| RX | Serial data receive pin |
| TX | Serial data transmit pin |
| GND | Ground |
| 5V | 5V |
2. Product Parameters
| Product Parameters | |
|---|---|
| Notes | |
| Serial baud rate | 115200bps |
| Serial output frequency | Default 25Hz, adjustable from 10Hz to 100Hz |
| IIC clock rate | 100KHz |
| Output data | 3-axis acceleration, 3-axis angular velocity, 3-axis gyroscope, 3-axis Euler angles, 3-axis magnetometer, barometric pressure, altitude, temperature, quaternion (*red text: 9-axis/10-axis versions only; blue text: 10-axis version only) |
| Startup time | 5000ms |
| Operating temperature | -40°C~+85°C |
| Storage temperature | -40°C~+100°C |
| Shock resistance | 20kg (bare board) |
| Supported devices | Linux hosts: PC, Raspberry Pi, Jetson series, RDK series; MCU hosts: STM32, MSPM0, ESP32, Pico, Arduino |
| Operating voltage | 5V or 3.3V |
| Operating current | 11mA |
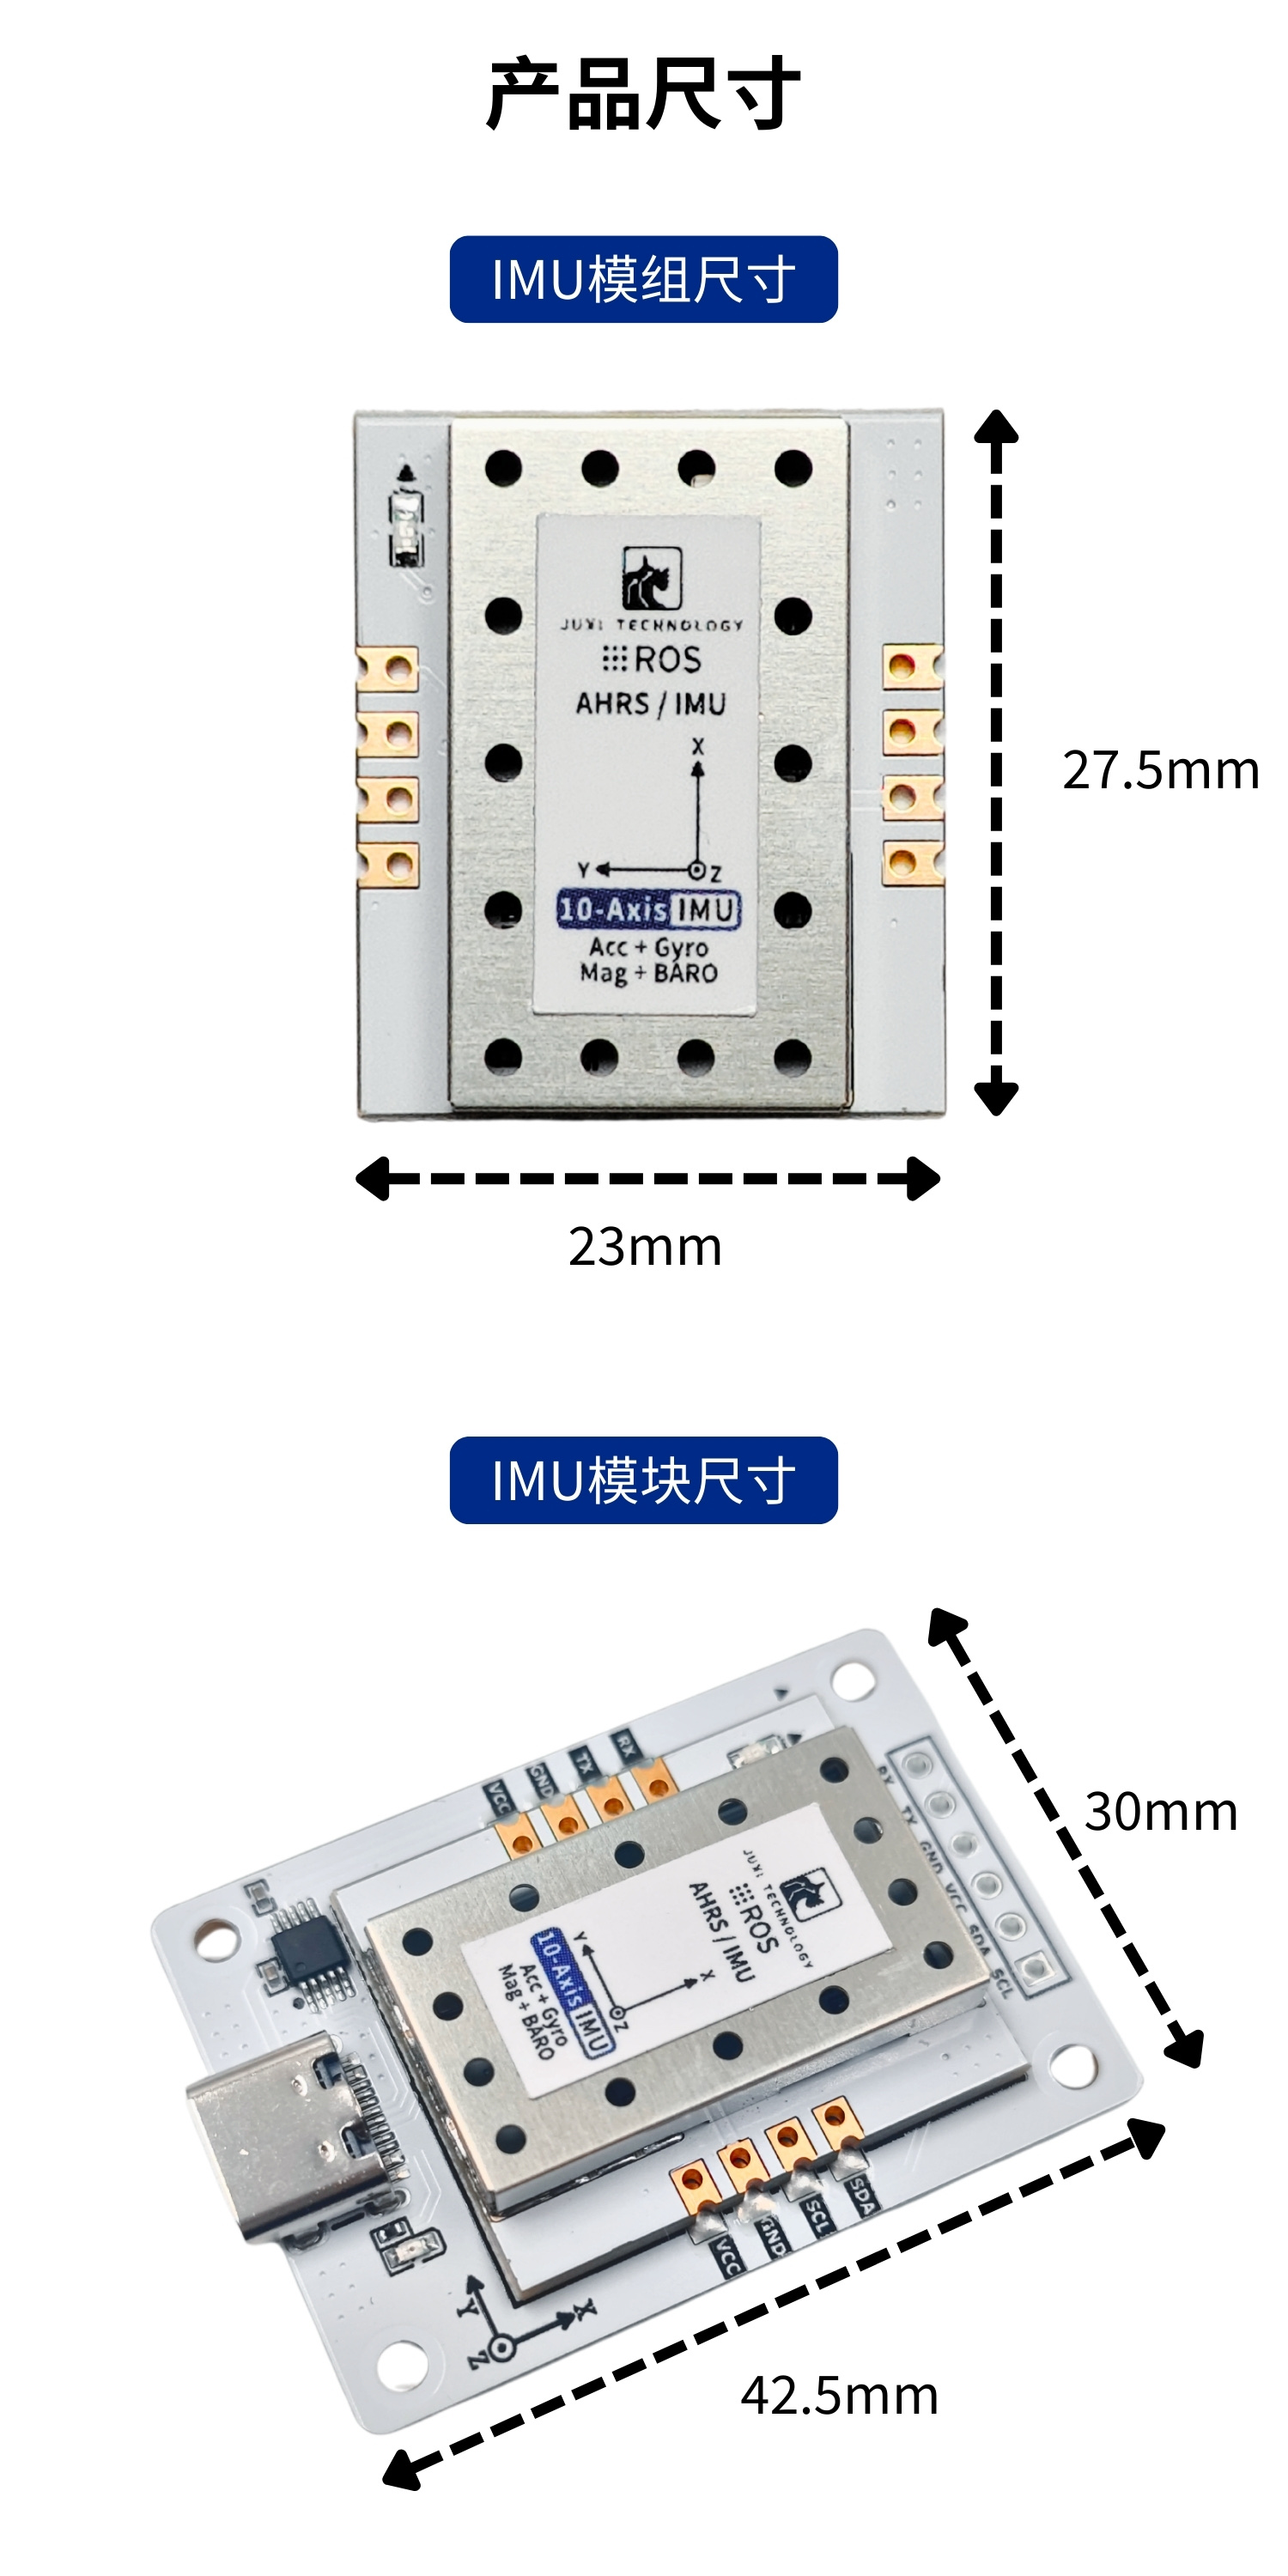
| Product dimensions | 27.4mm22.6mm12mm |
| Product weight | 3.8g |
| ROS support | ROS1/ROS2 |
3. Sensor Performance Parameters
IMU Data Performance Parameters
| IMU | Accelerometer | Gyroscope | Magnetometer |
|---|---|---|---|
| Range | ±16g | ±2000°/s | ±8Gauss |
| Resolution | 0.0005(g/LSB) | 0.061(°/s)/(LSB) | 0.244mGauss/LSB |
| RMS noise (100Hz bandwidth) | 1.0mg-RMS | 0.07°/S-RMS | / |
| Temperature drift | ±0.15mg/C | 0.015°/s/°C | / |
| Bandwidth | 12.5~1600Hz | 12.5~1600Hz | / |
Navigation Data Performance Parameters
| Parameter | Typical Value | |
|---|---|---|
| Pitch/Roll angle (horizontal placement) | Range | X:±180°, Y:±90° |
| Accuracy | 0.0055° | |
| Heading angle (horizontal placement) | Range | Z:±180° |
| Accuracy | 0.0055° |
Barometer Performance Parameters
| Parameter | Condition | Typical Value |
|---|---|---|
| Range | 300~2000hPa | |
| RMS noise | Standard mode | 1Pa-RMS |
| Relative accuracy | ±0.12hPa |
4. Dimension Parameters