

Move XLeRobot Files
Download and extract the archive at https://github.com/Vector-Wangel/XLeRobot
or
Bash
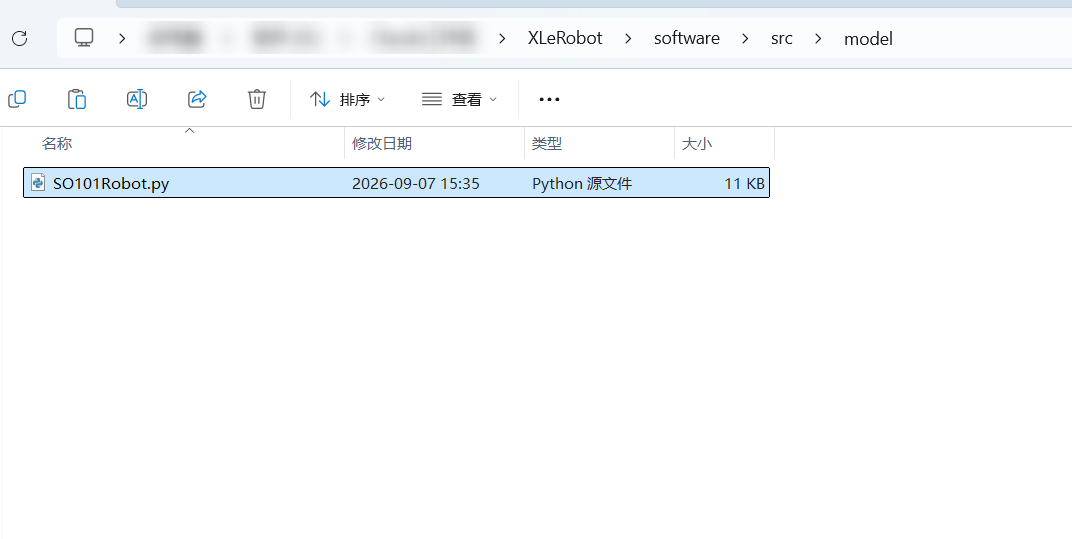
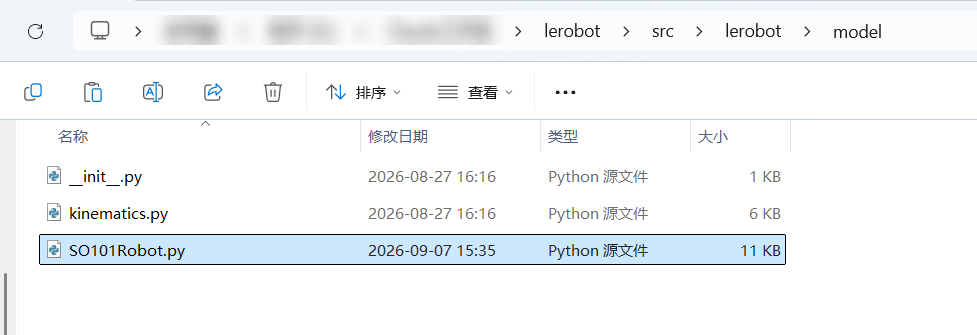
Git clone https://github.com/Vector-Wangel/XLeRobotCopy the SO101 robot analytical inverse kinematics solver under ~\XLeRobot\software\src\model文件夹 to ~\lerobot\src\lerobot\model文件夹
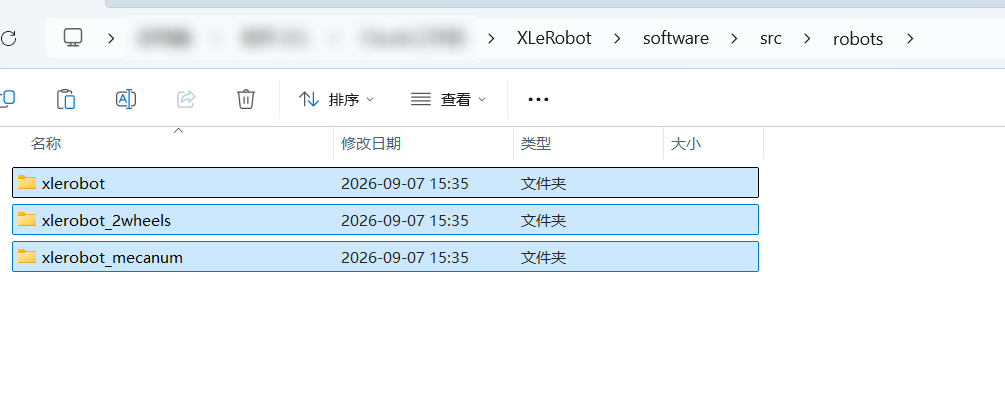
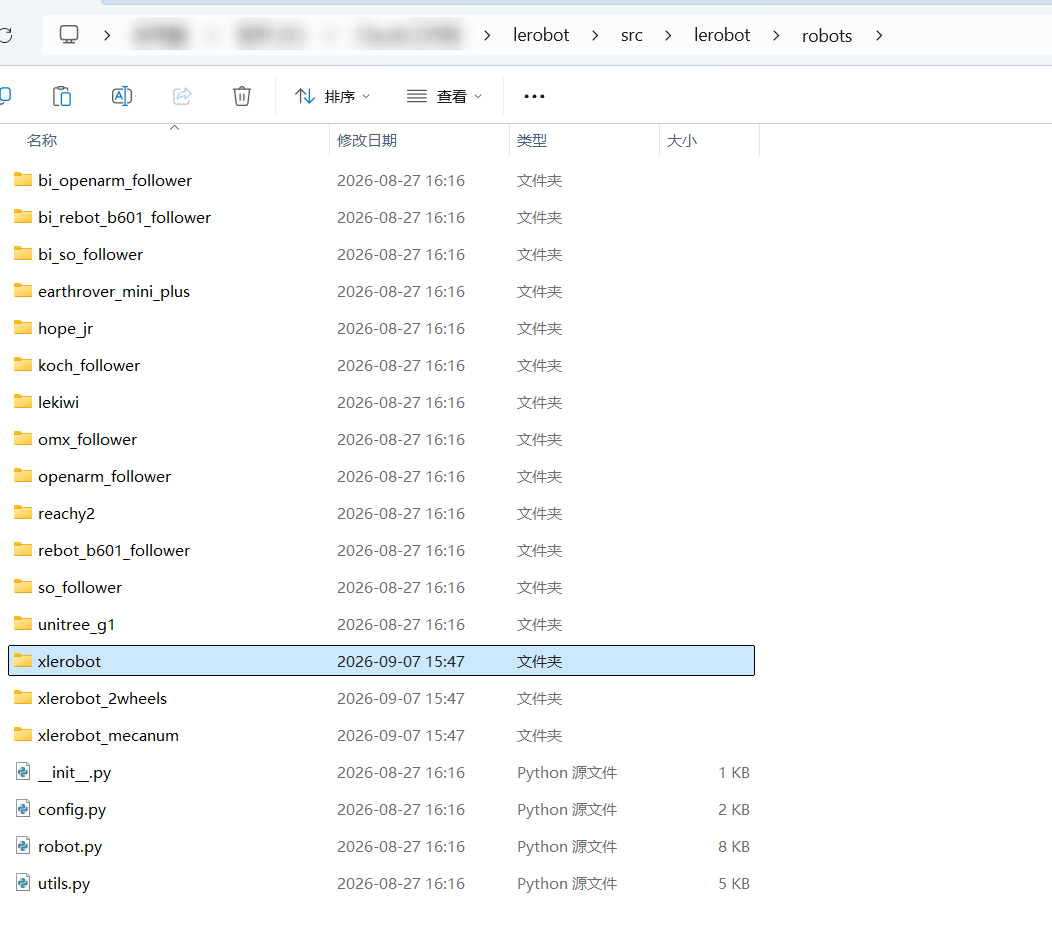
Copy the folders under ~\XLeRobot\software\src\robots文件夹 to ~\lerobot\src\lerobot\robot文件夹
Note
If you want to build based on the Raspberry Pi, uncomment xlerobot_host and xlerobot_client in ~\lerobot\src\lerobot\robots\xlerobot__init__.py.
Copy the folders under ~\XLeRobot\software\src\teleporators文件夹 to ~\lerobot\src\lerobot\teleporators文件夹
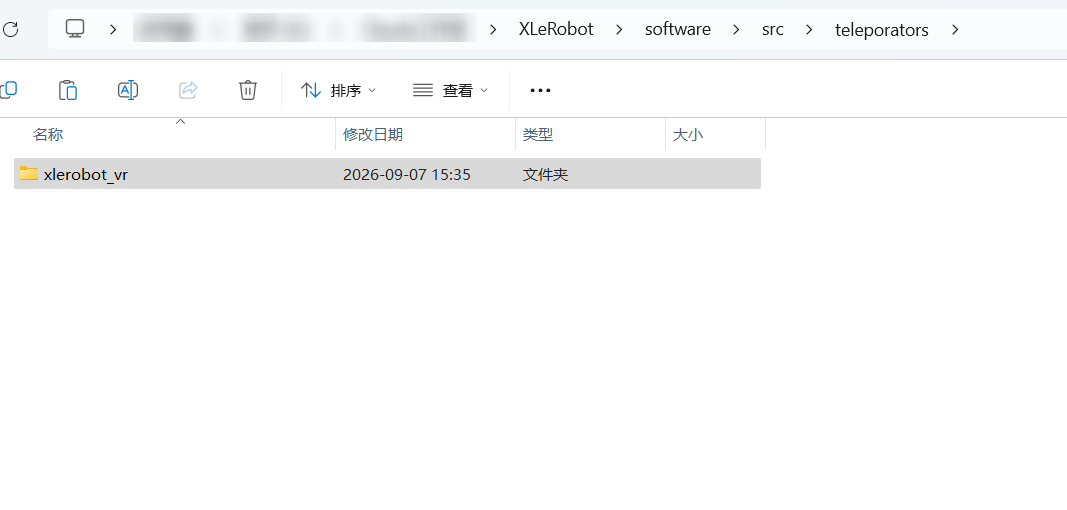
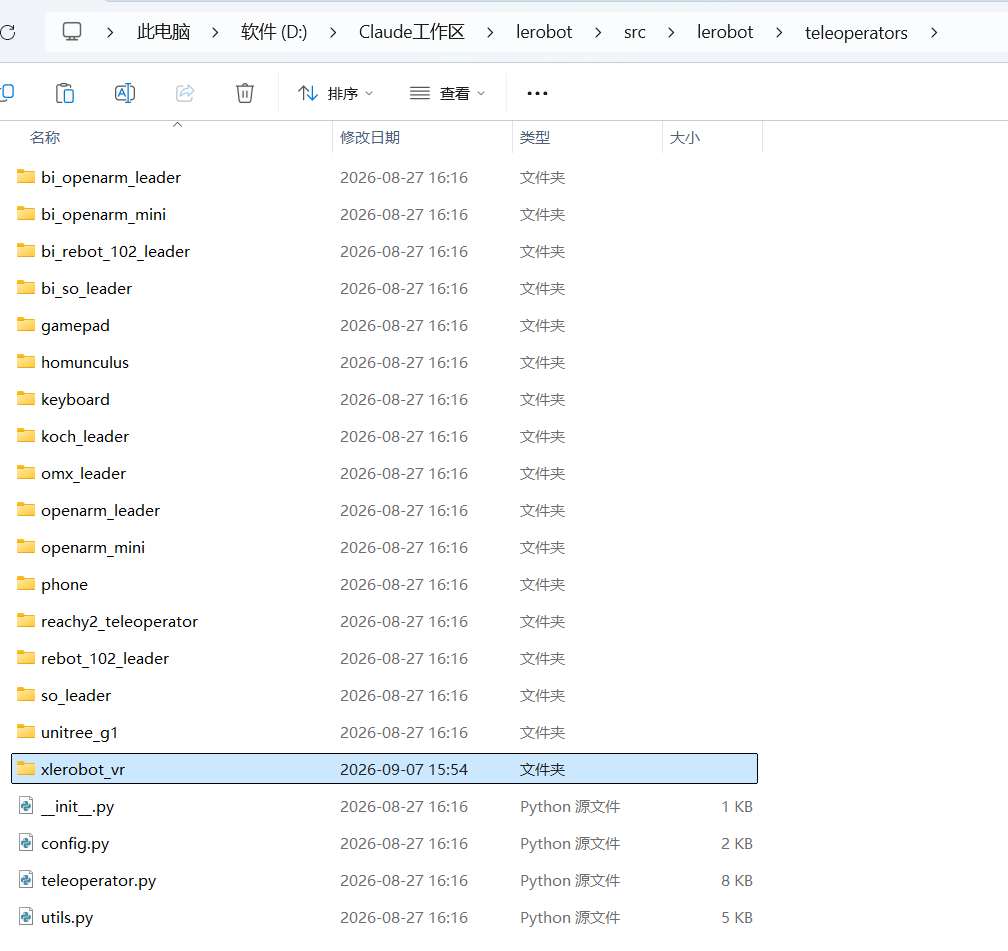
Copy all the files under ~\XLeRobot\software\examples文件夹 into ~\lerobot\examples文件夹
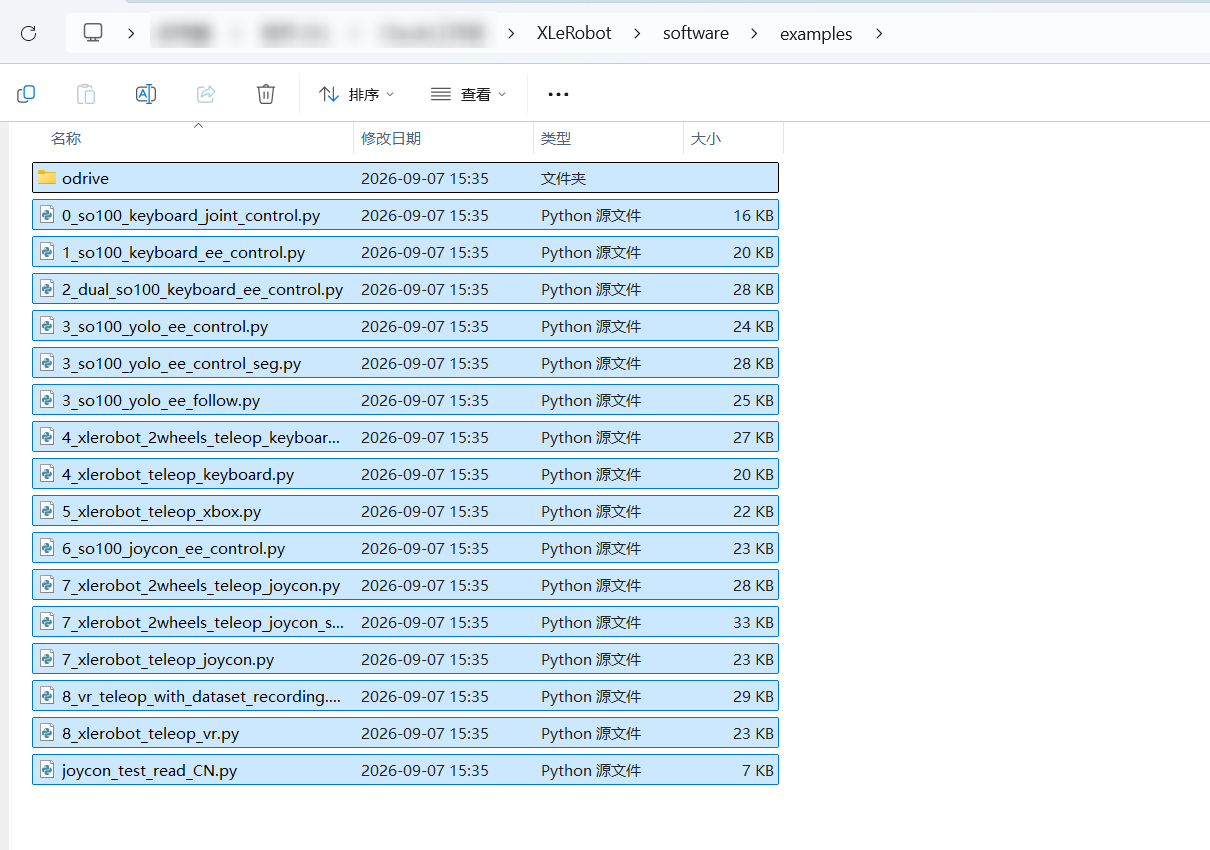
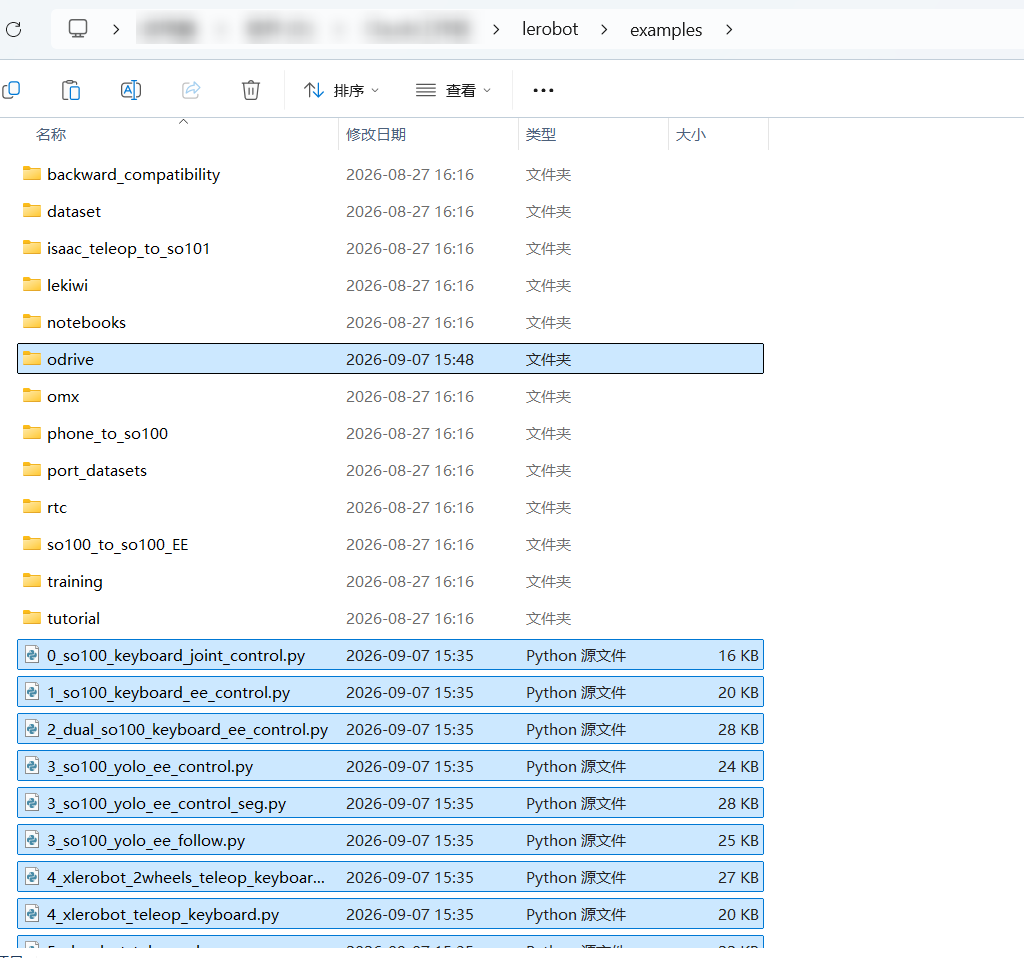
Tutorial https://xlerobot.readthedocs.io/zh-cn/latest/software/index.html