

XLeRobot ファイルの移動
https://github.com/Vector-Wangel/XLeRobot で圧縮ファイルをダウンロードして解凍します
または
Bash
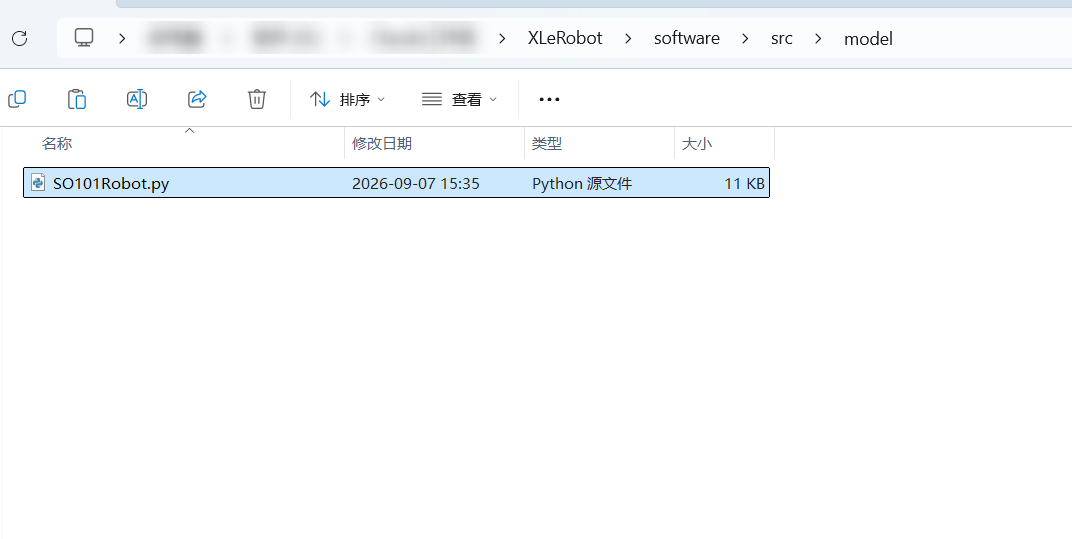
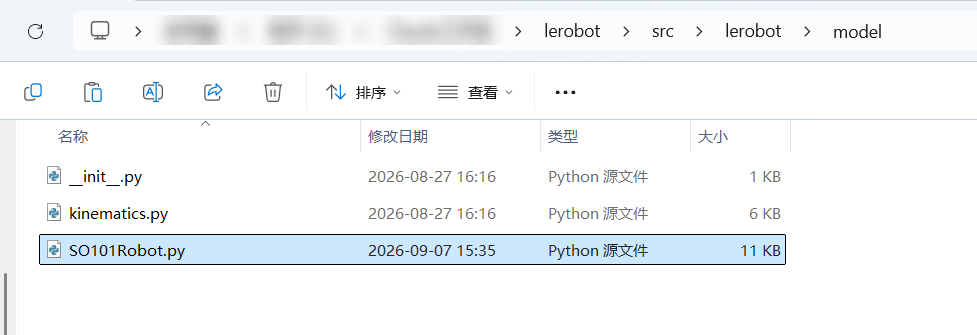
Git clone https://github.com/Vector-Wangel/XLeRobot~\XLeRobot\software\src\model文件夹 にある SO101 ロボットの逆運動学解析ソルバーを、以下にコピーします ~\lerobot\src\lerobot\model文件夹
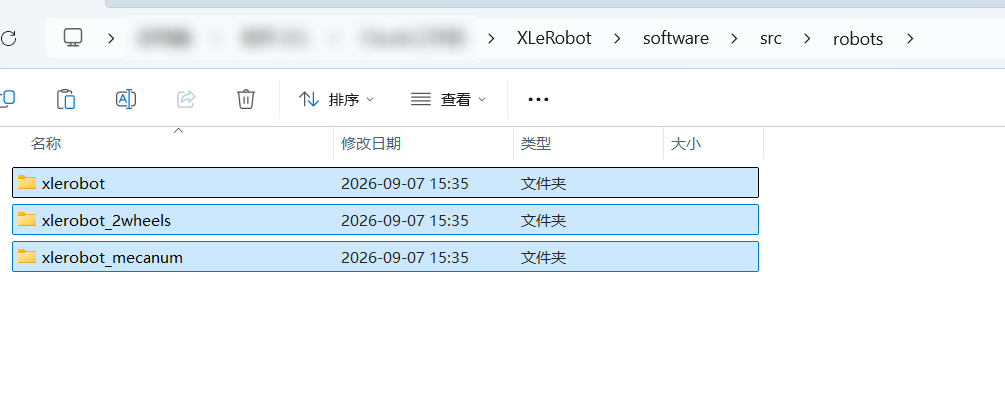
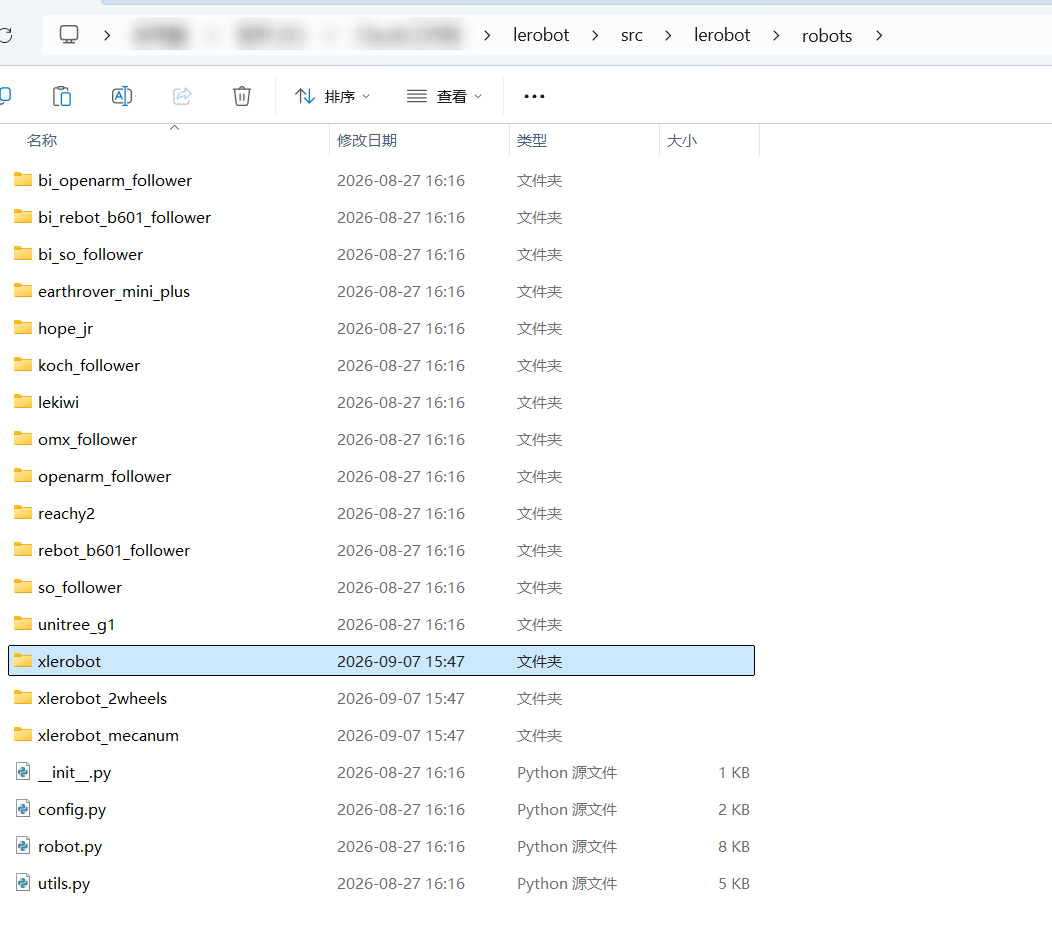
~\XLeRobot\software\src\robots文件夹 にあるフォルダを、以下にコピーします ~\lerobot\src\lerobot\robot文件夹
備考
Raspberry Pi をベースに構築したい場合は、~\lerobot\src\lerobot\robots\xlerobot__init__.py 内で xlerobot_host と xlerobot_client のコメントを解除してください。
~\XLeRobot\software\src\teleporators文件夹 にあるフォルダを、以下にコピーします ~\lerobot\src\lerobot\teleporators文件夹
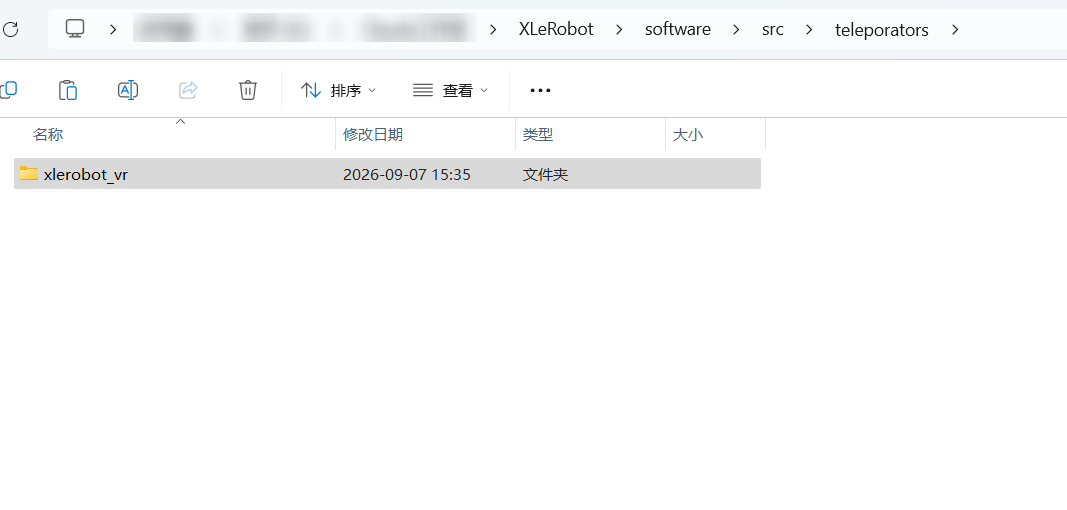
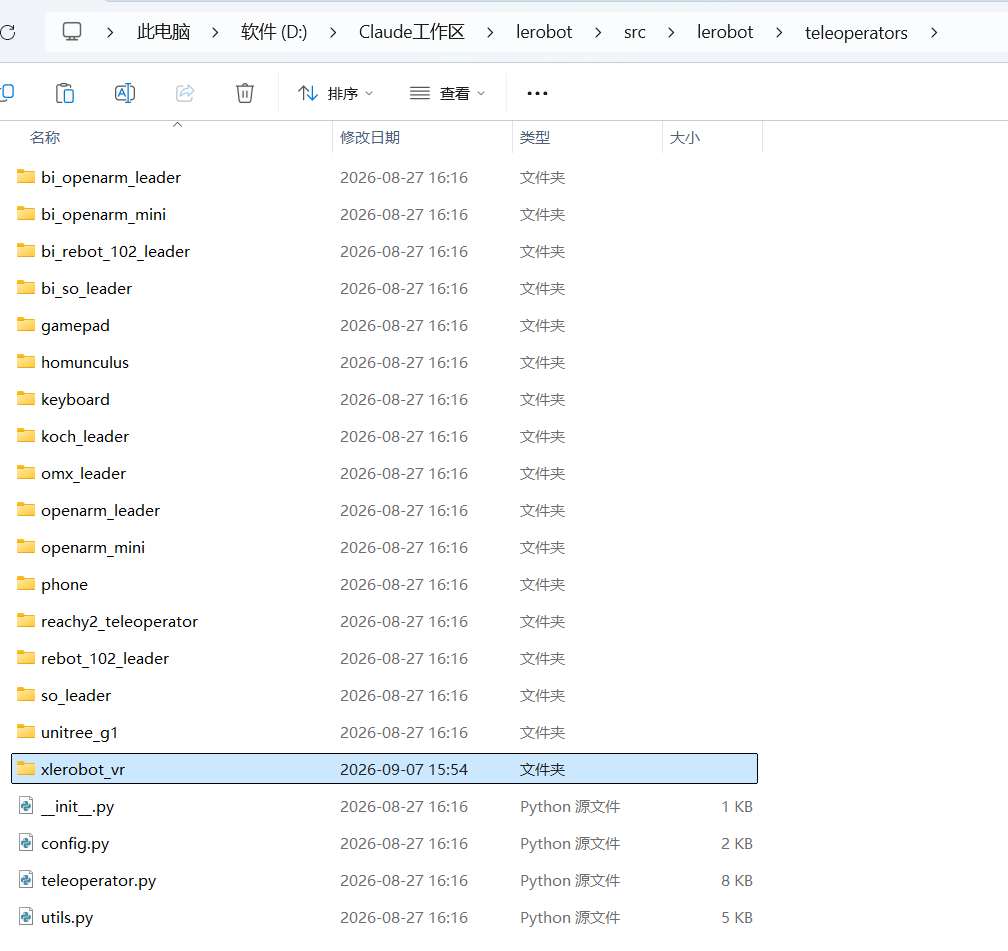
~\XLeRobot\software\examples文件夹 にあるファイルをすべて、以下の場所にコピーします ~\lerobot\examples文件夹 下
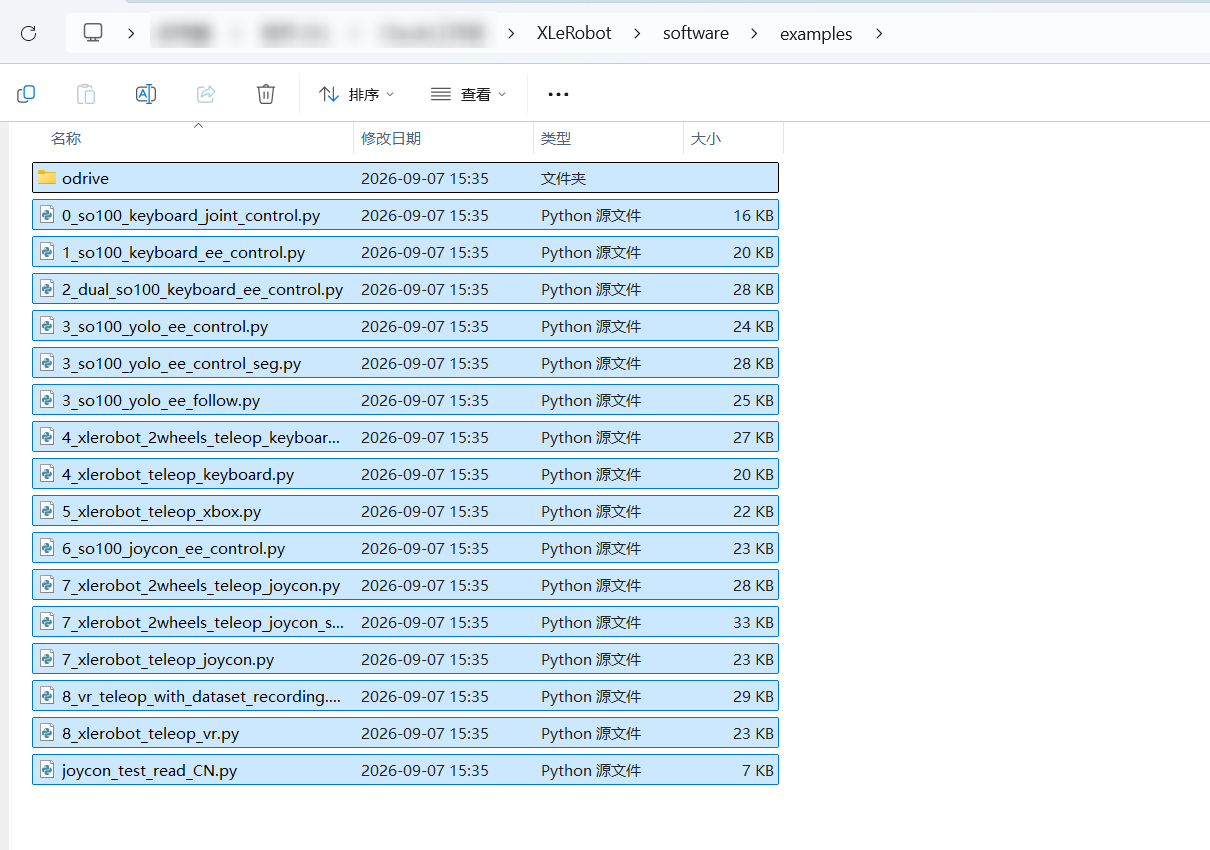
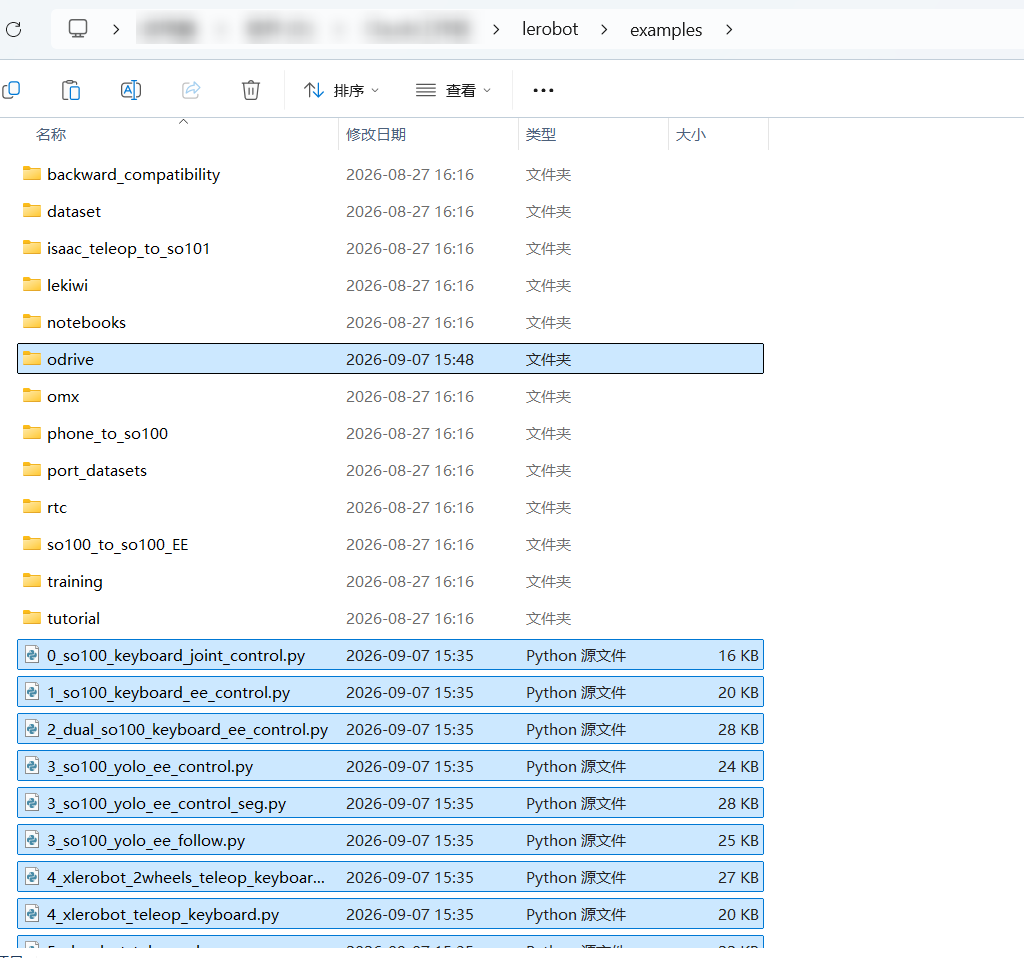
使用チュートリアルhttps://xlerobot.readthedocs.io/zh-cn/latest/software/index.html