Local Ubuntu Training
https://github.com/huggingface/lerobot/blob/main/src/lerobot/scripts/lerobot_train.py
https://github.com/huggingface/lerobot/blob/main/src/lerobot/configs/train.py
- Note
The \ can only have one space before it and no space after it
--dataset.split defaults to train, i.e. use all the data as the training set
When the dataset is local, --dataset.streaming must be false, because the dataset is already local and does not need streaming reads
Shell
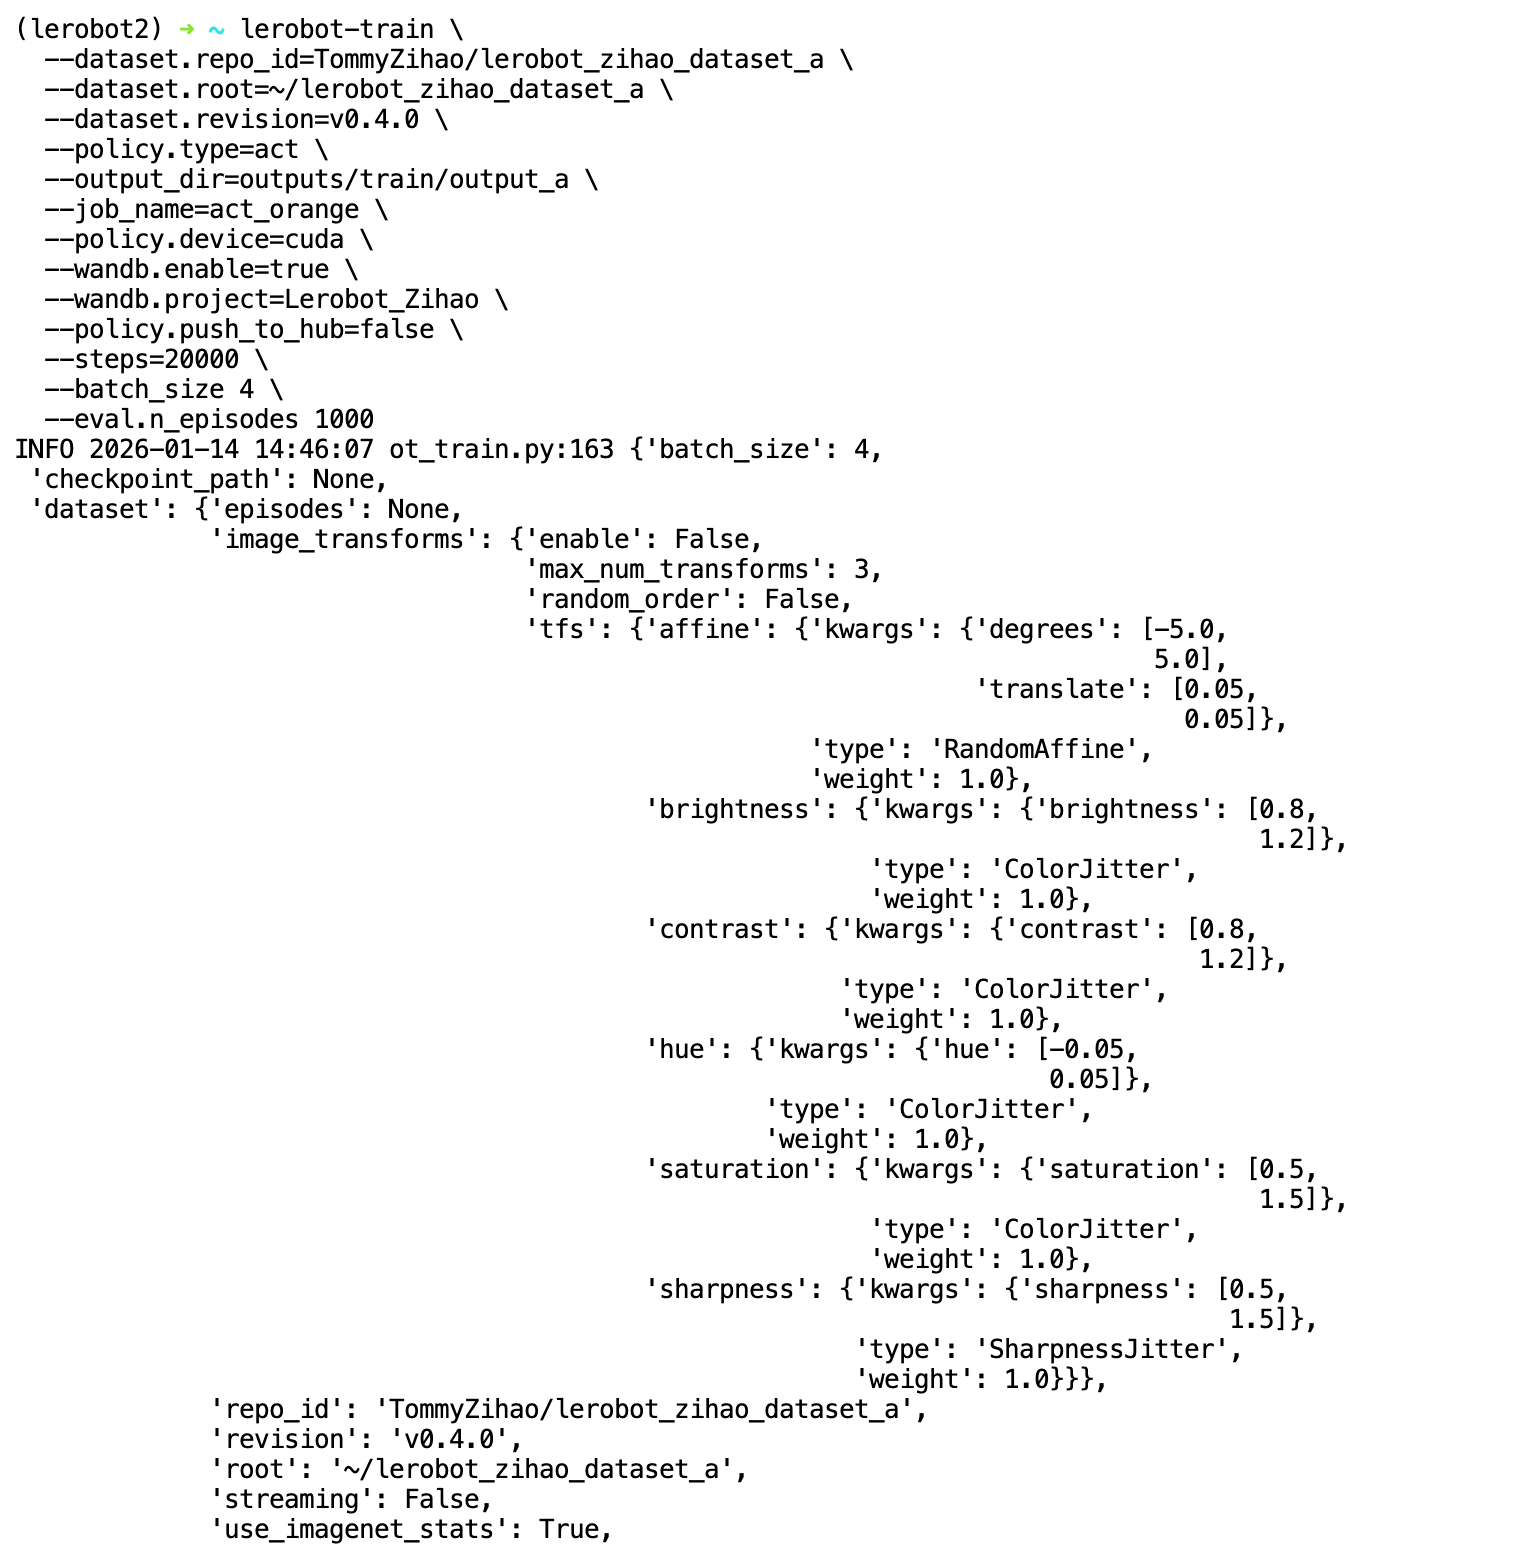
lerobot-train \
  --dataset.repo_id=Tommymy/lerobot_my_dataset_a \
  --dataset.root=/Users/tommy/.cache/huggingface/lerobot/Tommymy/lerobot_my_dataset_a \
  --dataset.revision=v0.4.0 \
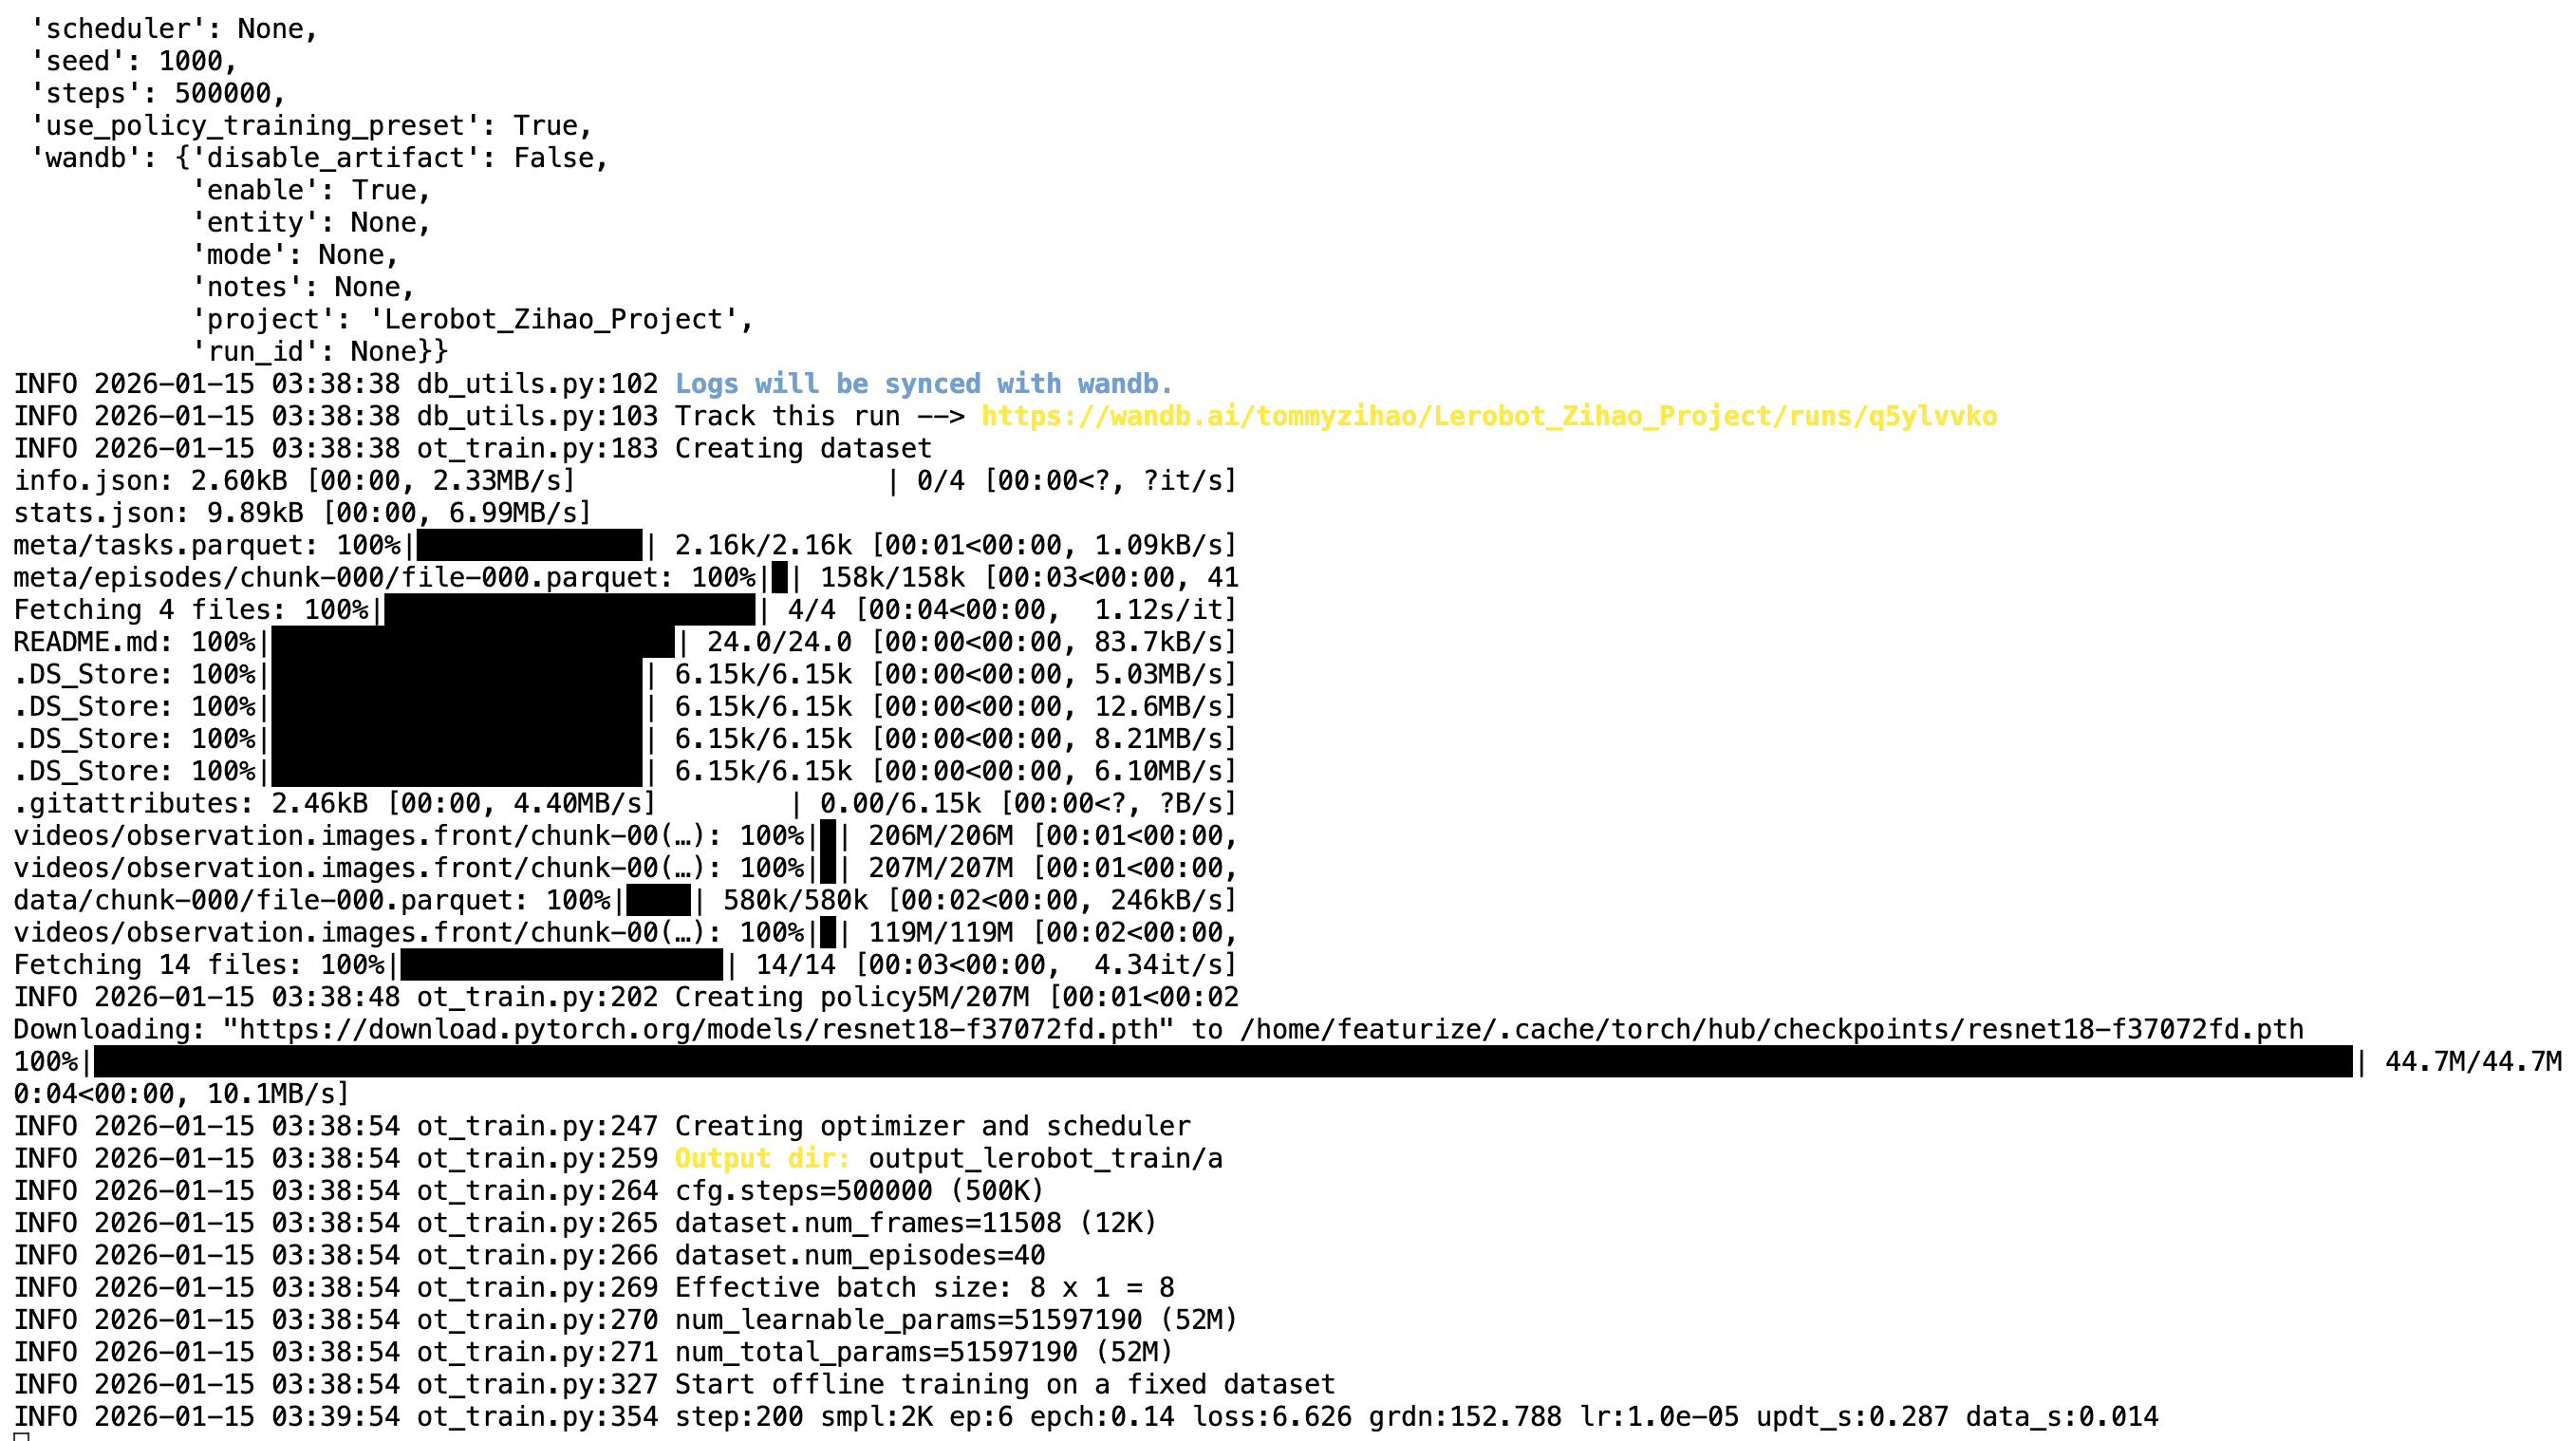
  --dataset.streaming=false \
  --policy.type=act \
  --output_dir=output_lerobot_train/a \
  --job_name=orange_job \
  --policy.device=cuda \
  --wandb.enable=true \
  --wandb.project=Lerobot_my_Project \
  --policy.push_to_hub=false \
  --steps=300000 \
  --batch_size=8