

Ubuntu
Grant permissions to the port
Grant all users read/write permission for these serial devices
Shell
sudo chmod 666 /dev/ttyACM*Calibrate the follower arm (Follower) (newly added "wrist_yaw" joint)
Shell
lerobot-calibrate \
    --robot.type=so101_follower \
    --robot.port=/dev/ttyACM0 \
    --robot.id=my_follower_arm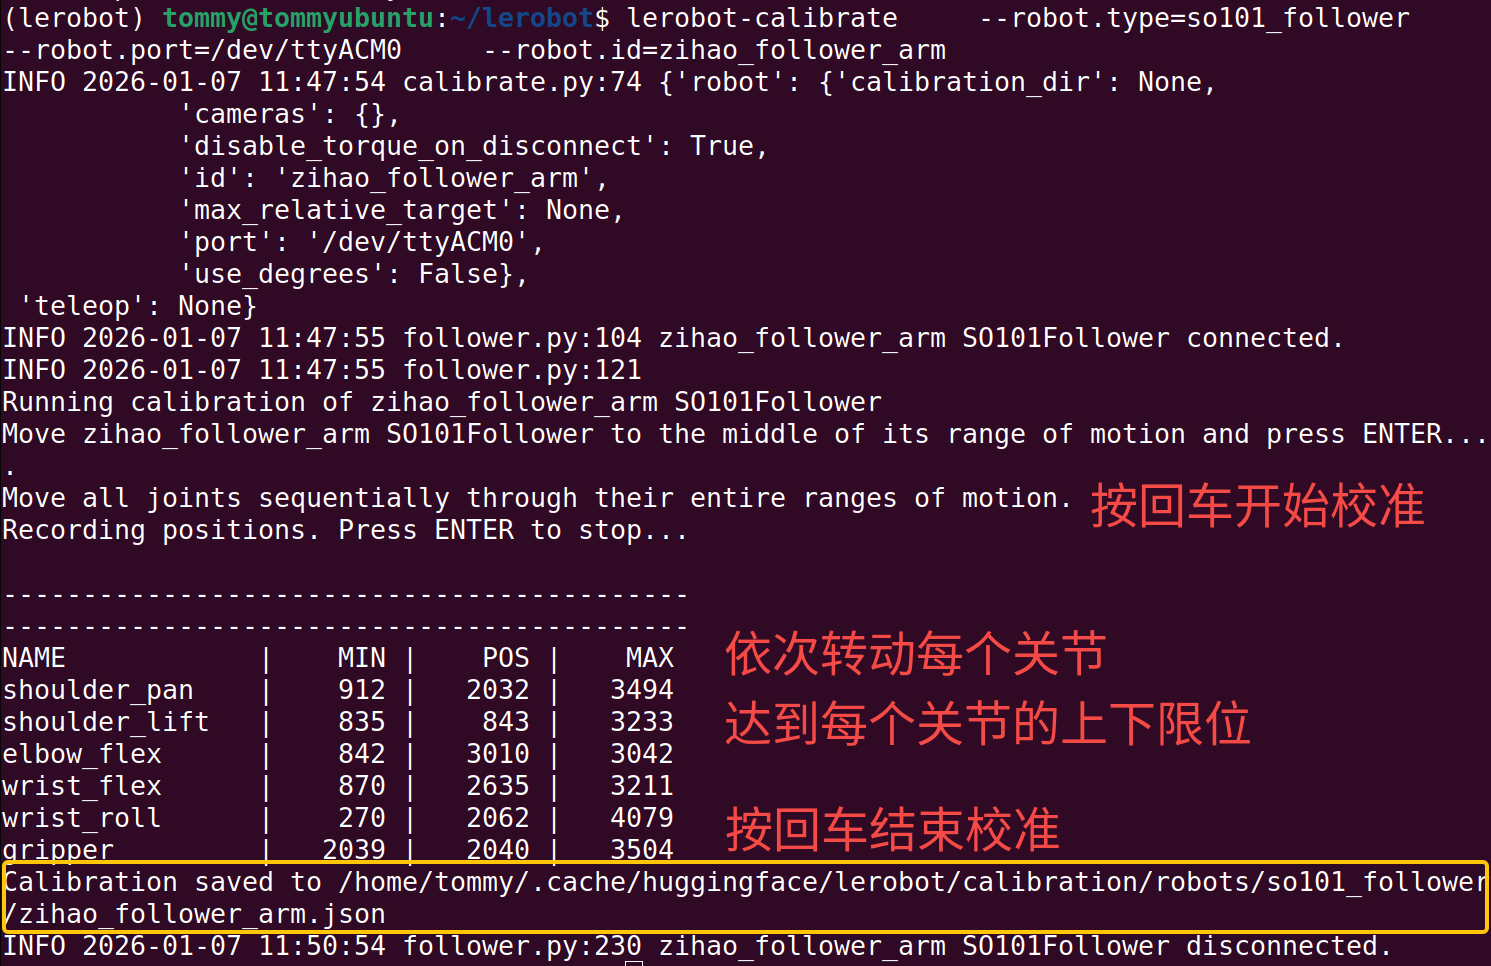
Calibrate the leader arm (Leader) (newly added "wrist_yaw" joint)
Shell
lerobot-calibrate \
    --teleop.type=so101_leader \
    --teleop.port=/dev/ttyACM1 \
    --teleop.id=my_leader_arm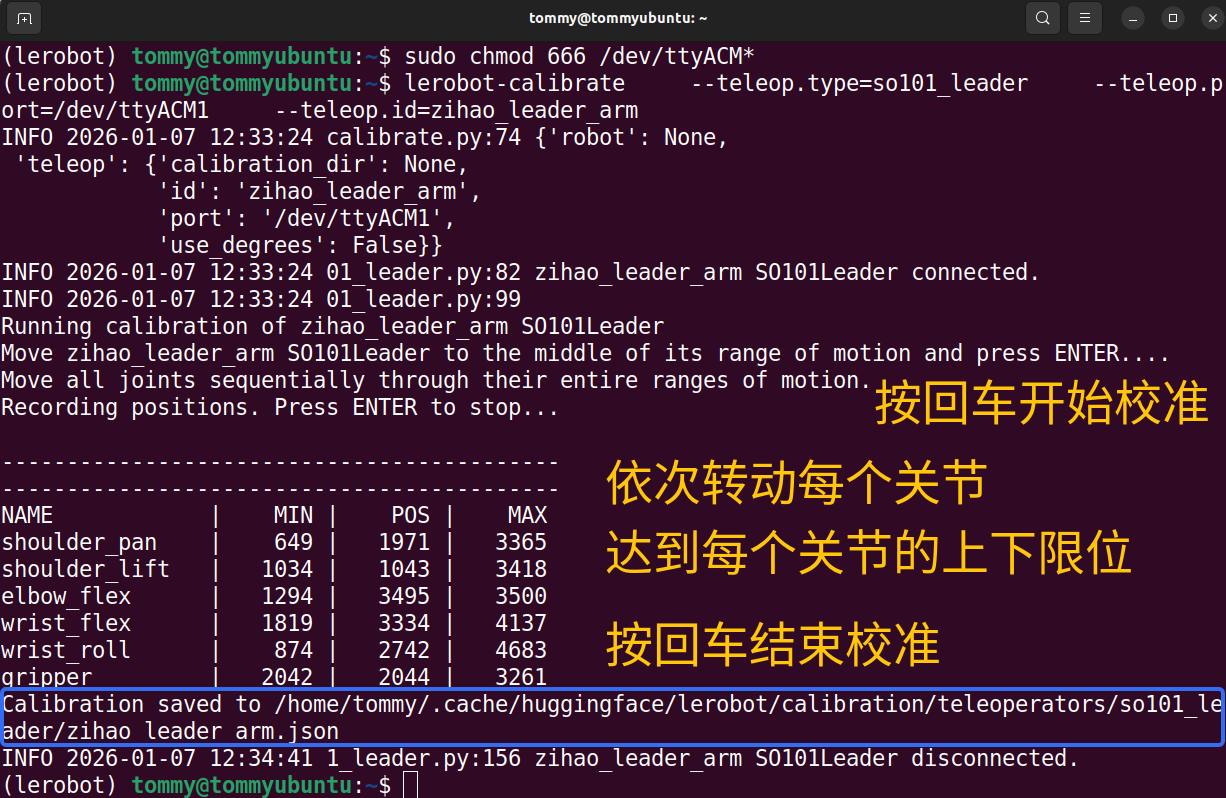
View the calibration configuration file
Shell
sudo nano /home/tommy/.cache/huggingface/lerobot/calibration/robots/so101_follower/my_follower_arm.json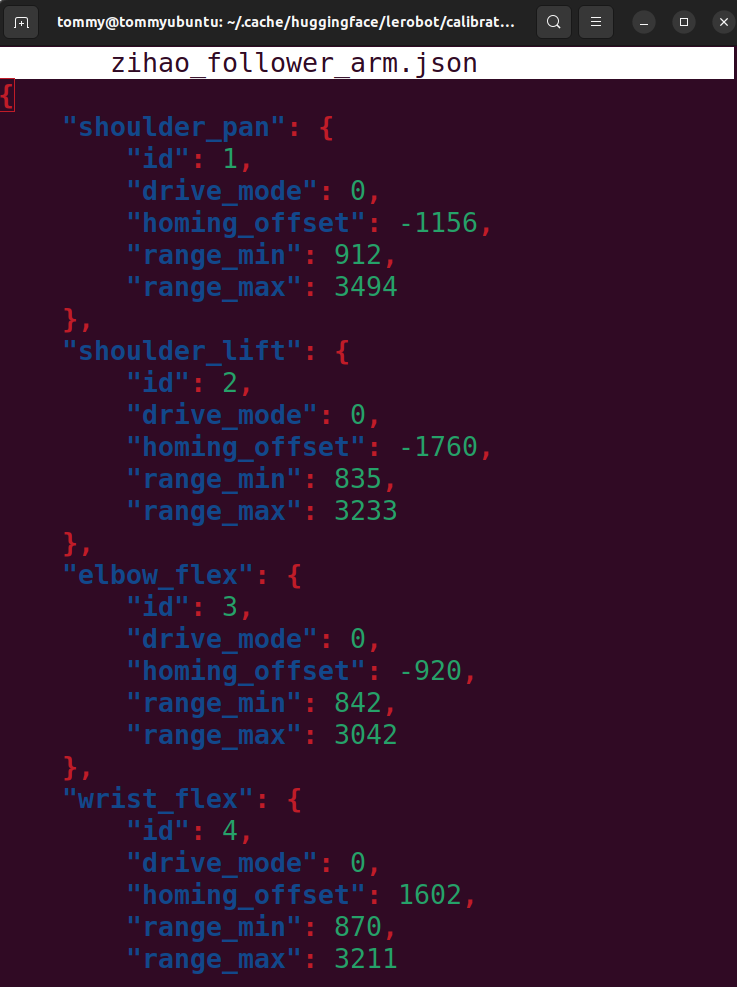
Notes
① Once one arm reaches its limit, it stops moving
Recalibration is required
② Servos cannot be found
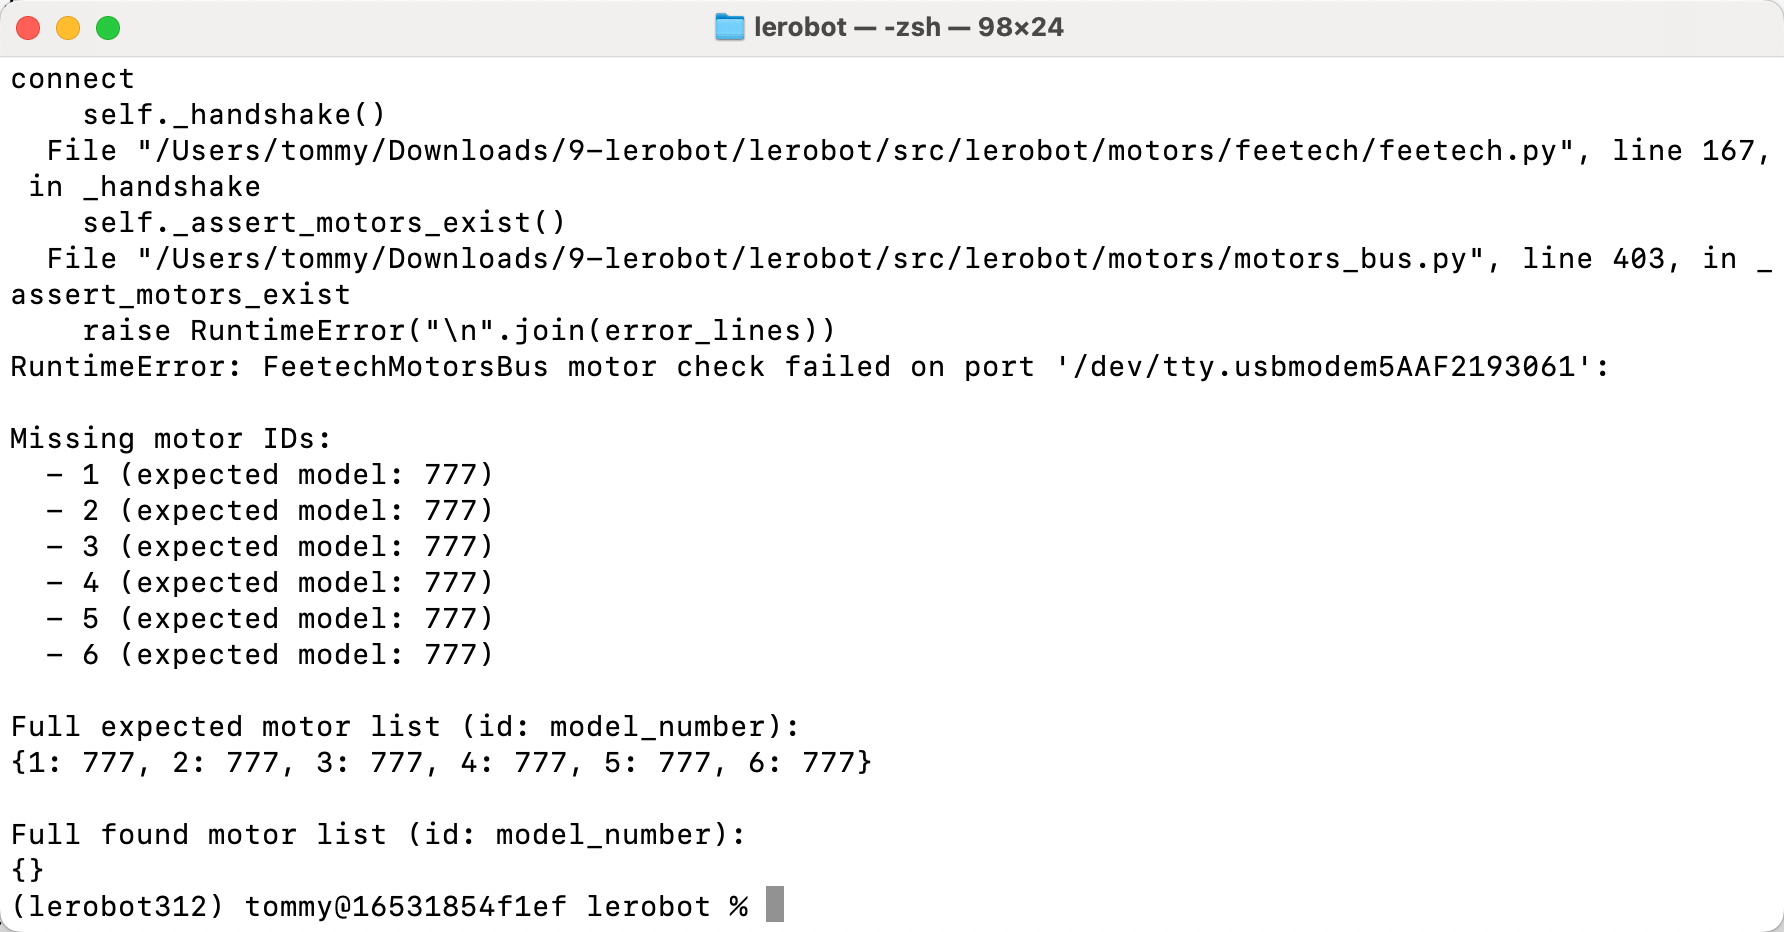
The servo power is not plugged in