

云GPU训练环境配置
关闭自己电脑的网络代理
不然可能打不开Jupyter的命令行
登录云GPU平台Featurize
https://featurize.cn?s=d7ce99f842414bfcaea5662a97581bd1
加用户群,跟客服说是同济子豪兄粉丝,领取代金券
开启一个云GPU实例
安装配置环境
Shell
conda create -y -n lerobot python=3.12
conda activate lerobot
conda install ffmpeg=7.1.1 -c conda-forge -y
# git clone https://github.com/Seeed-Projects/lerobot.git ~/work/Lerobot
git clone https://github.com/huggingface/lerobot.git
cd lerobot
pip install -e ".[pi]"
pip install wandb --upgrade
# export HF_ENDPOINT=https://hf-mirror.com
hf auth login
登录wandb
Shell
wandb login
复制粘贴API Key,回车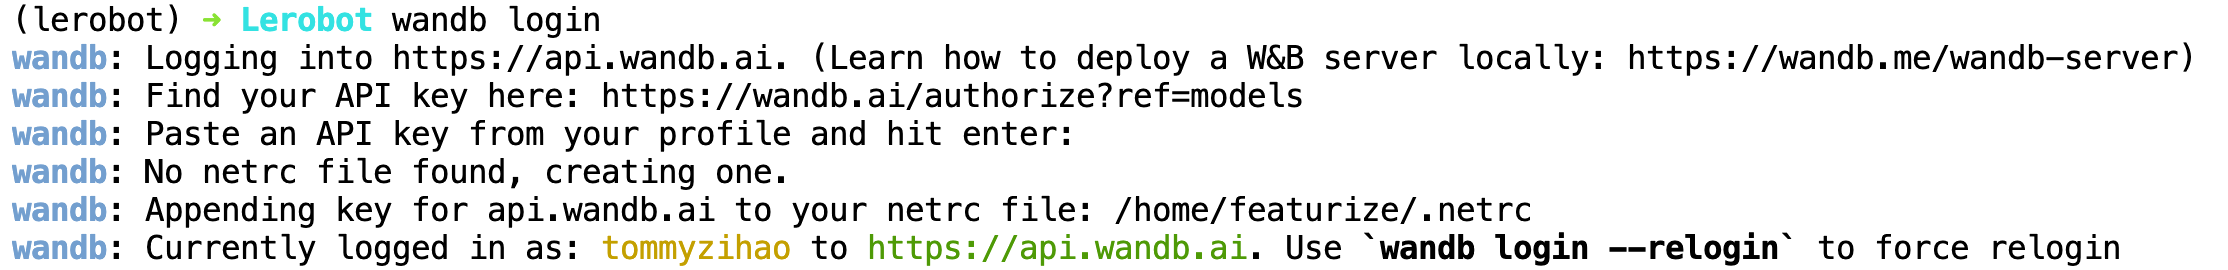
挂载数据集
Shell
复制实例下载命令,类似:
featurize dataset download 7f40bdaa-b1a4-4c00-9652-ff26fd079109

unzip lerobot_zihao_dataset_shake_hands.zip数据集出现在~目录下
修改权重保存频率(选做)
打开lerobot/src/lerobot/configs/train.py
将save_freq,从20_000修改为5_000
这样能在训练更早期获得模型权重文件