

SO-ARM101 Developer Kit
Overview
The SO-ARM101 is Juxi Technology's open-source 6-DOF dual-arm robot development kit, deeply integrated with the LeRobot ecosystem. Black leader arm + white follower arm, ready out of the box for teleoperation, imitation learning data collection, and policy training.
Key features:
- Dual arms, 6 DOF each, bus-servo driven
- Deep LeRobot (HuggingFace) integration — ACT/Diffusion/Pi0 policies
- Jetson / PC (Linux) support
- Fully open-source hardware (schematics/CAD/firmware)
1. Hardware Design: High-Performance, Modular, Easy to Assemble and Customize
Structural Materials: The core structure combines 3D-printed parts with reinforced load-bearing components, optimizing cable routing and joint design to avoid motion interference while balancing lightweight construction and durability. Users can print replacement or extension parts themselves.
Drive Configuration: The follower arm carries 6 × 12V 30KG high-torque magnetic-encoder servos, combined with 360° magnetic encoder feedback and a PID control algorithm, delivering smooth, jitter-free motion, high repeat positioning accuracy, strong torque, and precise action; the leader arm uses 6 × 7.4V servos, with different gear ratios allocated according to joint load, making manual drag teaching easy.
Vision System: Supports a dual-camera intelligent vision system, with the end camera capturing close-range grasping details and the global camera covering the working environment; fusing the dual-camera data builds a 3D model, providing rich data support for imitation learning.
Control Connection: Equipped with a servo driver board, connected directly to a computer or Raspberry Pi via a USB-C interface, plug and play, simplifying the hardware connection process and enabling rapid setup of the control environment.
2. Software Ecosystem: Deep LeRobot Integration, Zero-Barrier AI Development
Core Framework Compatibility: Deeply adapted to the Hugging Face LeRobot open-source robot ML framework, built on PyTorch, with built-in pretrained models, multi-scenario datasets, and a simulation environment, and compatible with well-known open-source datasets such as Stanford ALOHA.
Low-Latency Communication: Uses the DORA distributed dataflow engine to achieve low-latency interaction between hardware and algorithms; Python runs 17 times faster than ROS2, supports code hot-reloading, and allows real-time policy adjustment without restarting.
Full-Stack Open Source: The hardware 3D print files, software control code, AI training scripts, and the complete tutorial set are fully open source; users can freely modify and further develop them to quickly implement personalized feature extensions.
3. Core Application Scenarios: From Entry-Level to Deployment, Full-Scenario Coverage
Robotics Education for Beginners: Provides an end-to-end tutorial covering robotic arm assembly, basic programming, and AI policy deployment, along with a visual operation interface and example code, so users with zero background can quickly master robot control and AI application skills.
Research Algorithm Validation: Focused on imitation learning and reinforcement learning research, supporting the recording of human operation data via VR to train robots; a typical case: based on 50 fifteen-second operation videos, 2 hours of training is enough to master tasks such as clothes folding, key insertion, and material sorting.
Lightweight Industrial Prototyping: Low-cost validation of automation solutions, adapted to scenarios such as material handling, precision assembly, and part sorting, delivering the core functions of an industrial-grade robotic arm at a cost of around a thousand yuan, enabling rapid prototype validation.
Specifications
| Category | Spec |
|---|---|
| Type | Dual-arm teleoperation robot |
| DOF | 6 DOF per arm |
| Drive | Feetech bus servos |
| Host | PC (Linux) / Jetson |
| Ecosystem | LeRobot, ROS 2, ROS 1 |
| Power | Leader 5V6A / Follower 12V5A |
| Payload | 500g |
| Repeatability | ±0.1mm |
| Working radius | 520mm |
| Communication | USB-C |
| Material | Bambu Lab PLA+ |
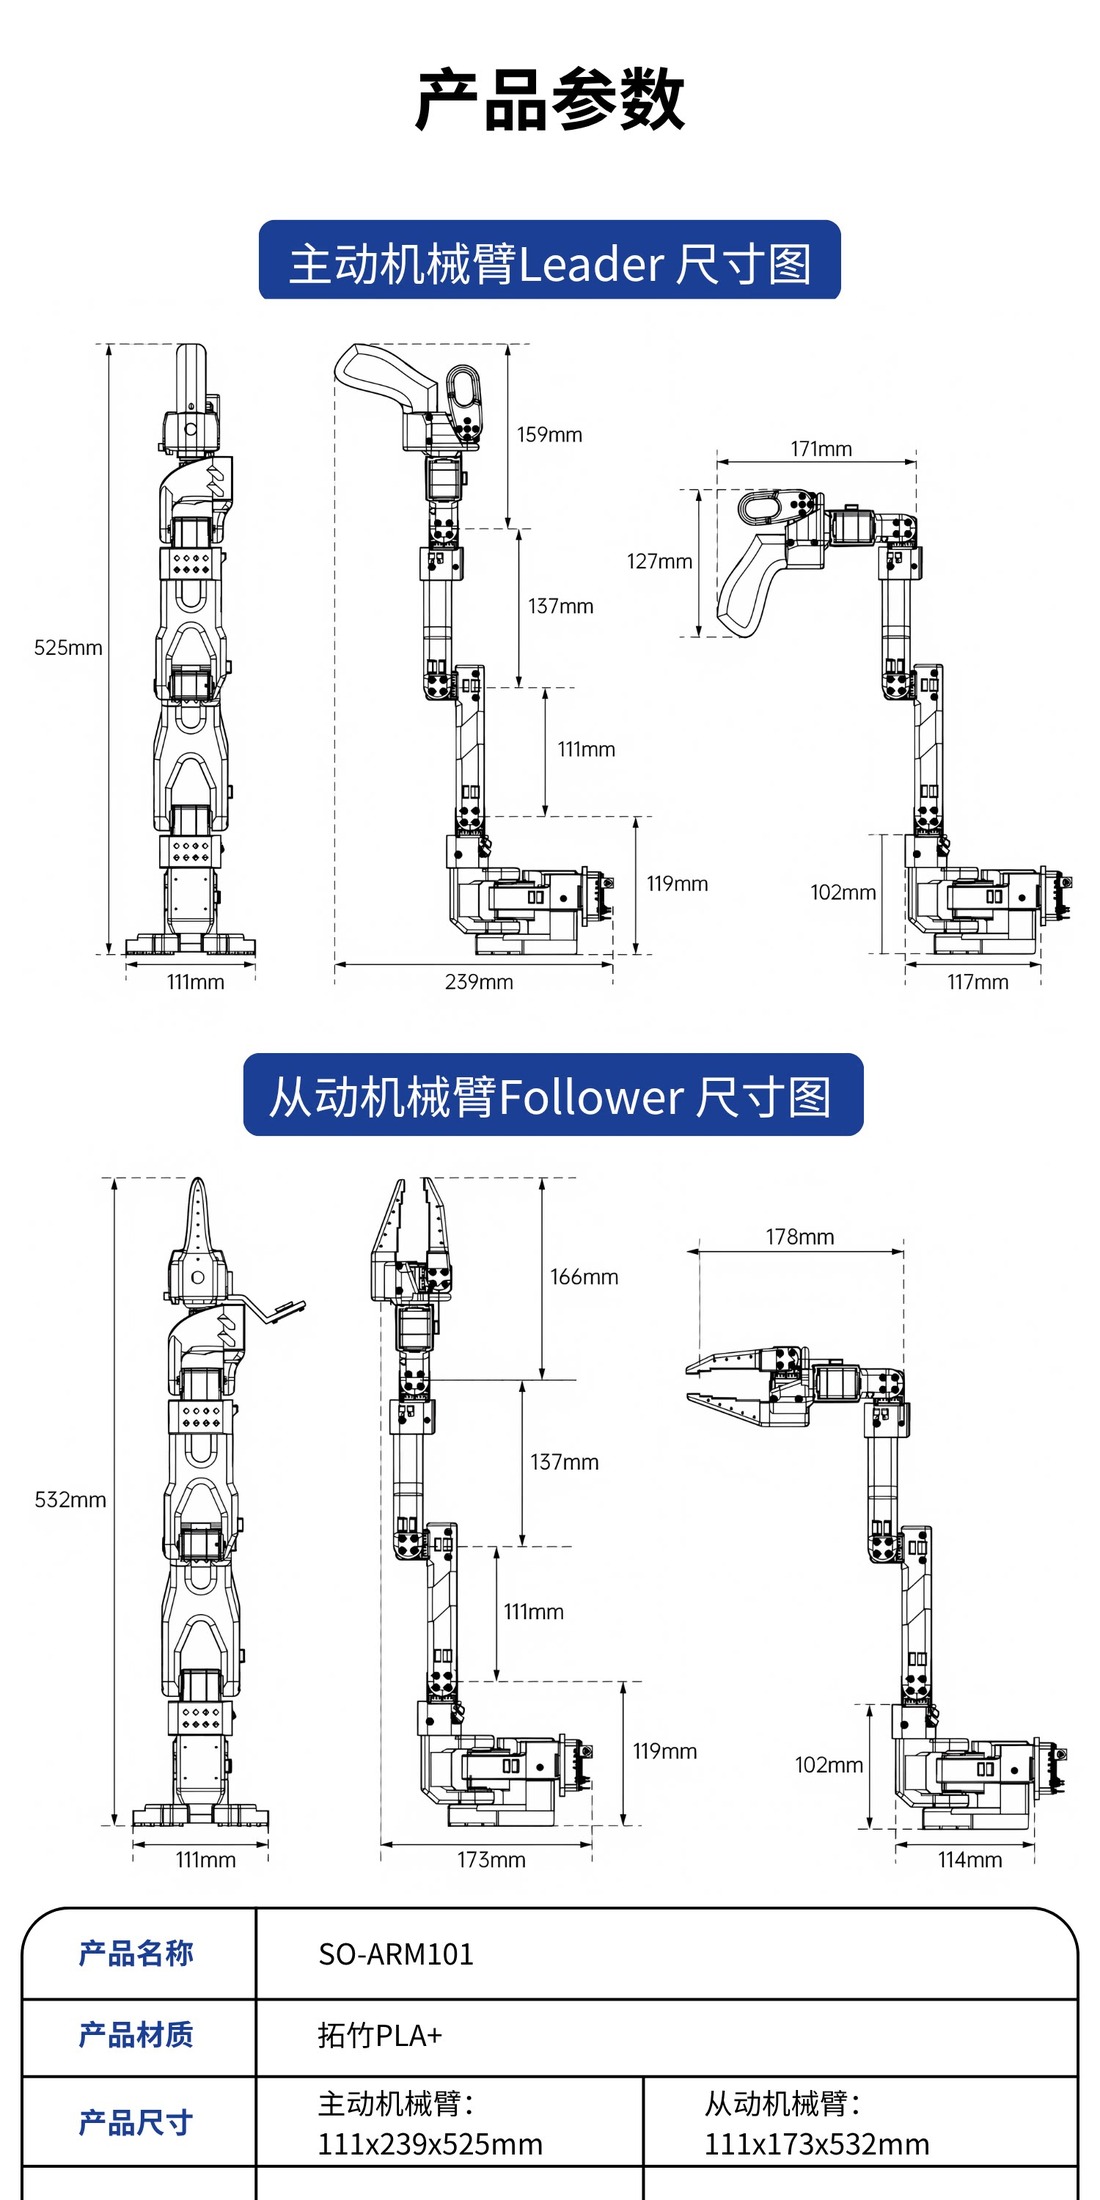
| Dimensions (leader / follower) | 111×239×525 mm / 111×173×532 mm |
Quick Start
git clone https://github.com/Juxi-Technology/lerobot.git
cd lerobot && pip install -e ".[feetech]"

lerobot-calibrate --robot.type=so101_follower --robot.port=/dev/ttyACM0

lerobot-teleoperate --robot.type=so101_follower --robot.port=/dev/ttyACM0 \
  --teleop.type=so101_leader --teleop.port=/dev/ttyACM1
Tutorials
Support
- 📧 Email: support@juxitech.com
- 🌐 Website: www.juxitech.com